8 stories matching “Manipulation”.
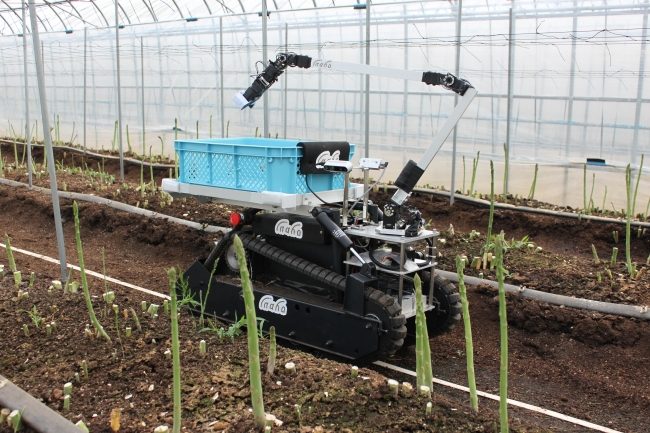
Japanese startup Inaho reported an updated harvesting robot in April 2019, emphasizing a narrower body and handling of dense spring asparagus ahead of its planned commercial service launch.
Source Inaho via PR Times
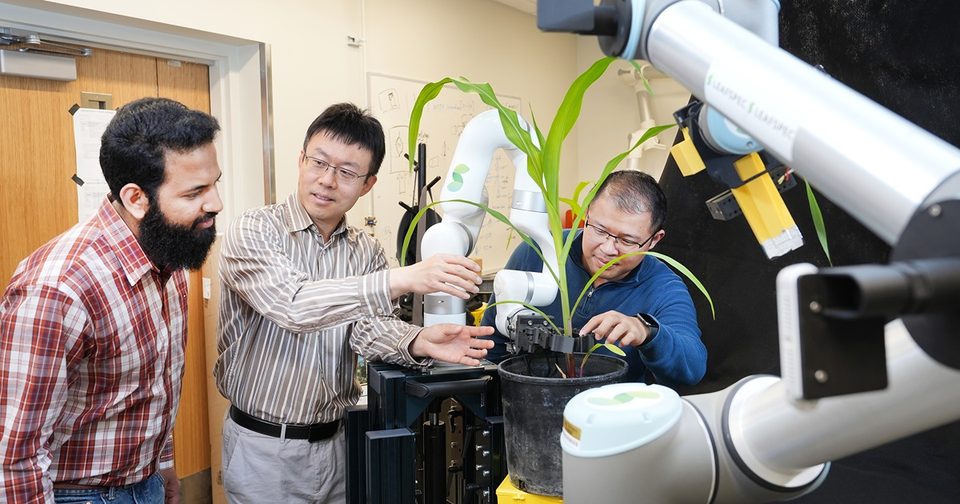
Purdue researchers linked LeafSpec imaging with a two-arm laboratory system in June 2024, using tactile feedback to steady corn plants and guide a scanner along their leaves.
Source Purdue College of Agriculture
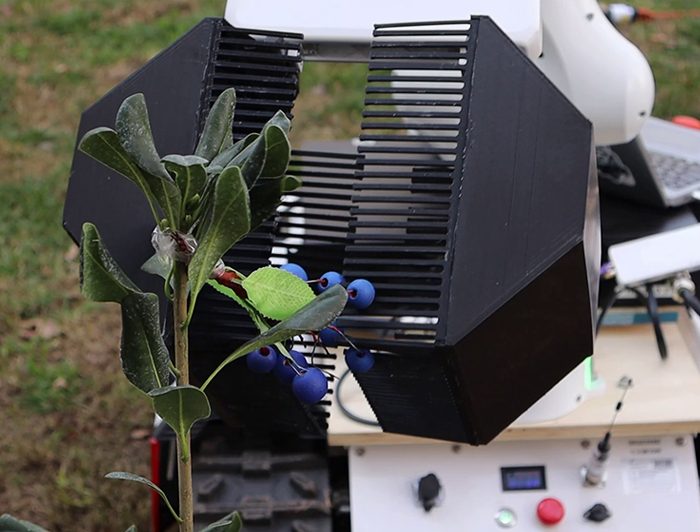
A March 2025 university report describes Miguel Torres’s team developing an adaptable mobile manipulator for tasks including delicate-fruit handling, with sensing and perception still being refined.
Source Pontificia Universidad Católica de Chile
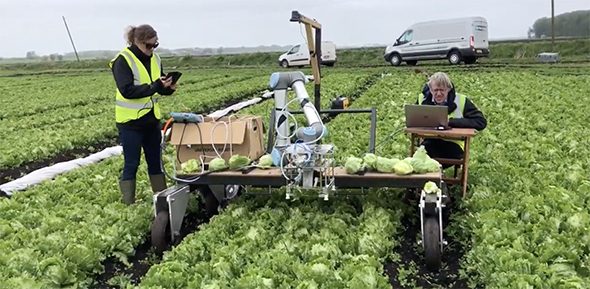
In July 2019, Cambridge reported field tests of a lettuce-harvesting prototype that identified suitable heads and controlled cutting and gripping, while openly acknowledging that human workers remained faster.
Source University of Cambridge Department of Engineering
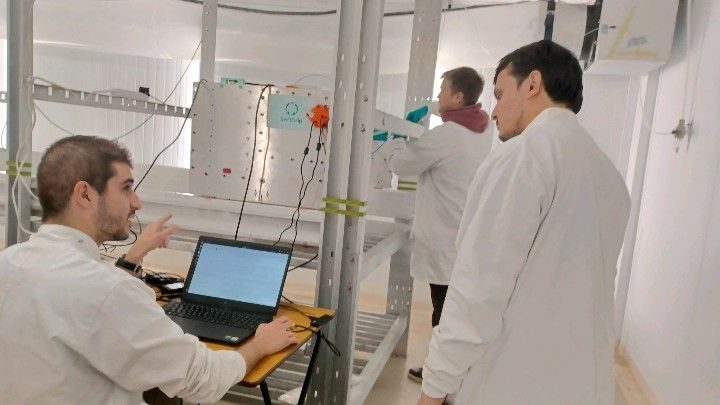
The European project combined soft gripping and machine vision in a harvesting prototype, with trials in Greece and Ireland revealing both successful picks and the impact of real facility constraints.
Source European Commission — CORDIS
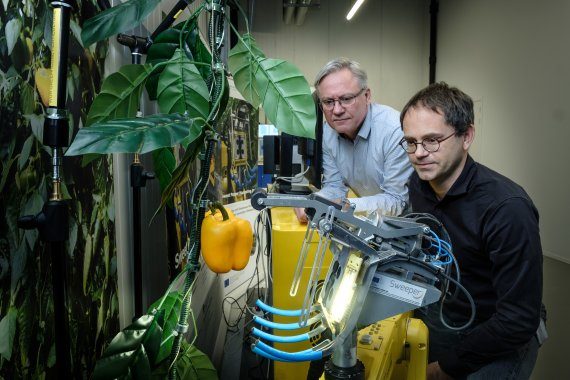
A Wageningen report on the European harvesting robot documented faster pepper picking while highlighting the continuing limits imposed by cycle time, foliage, clustered fruit and access within greenhouse rows.
Source Resource — Wageningen University & Research
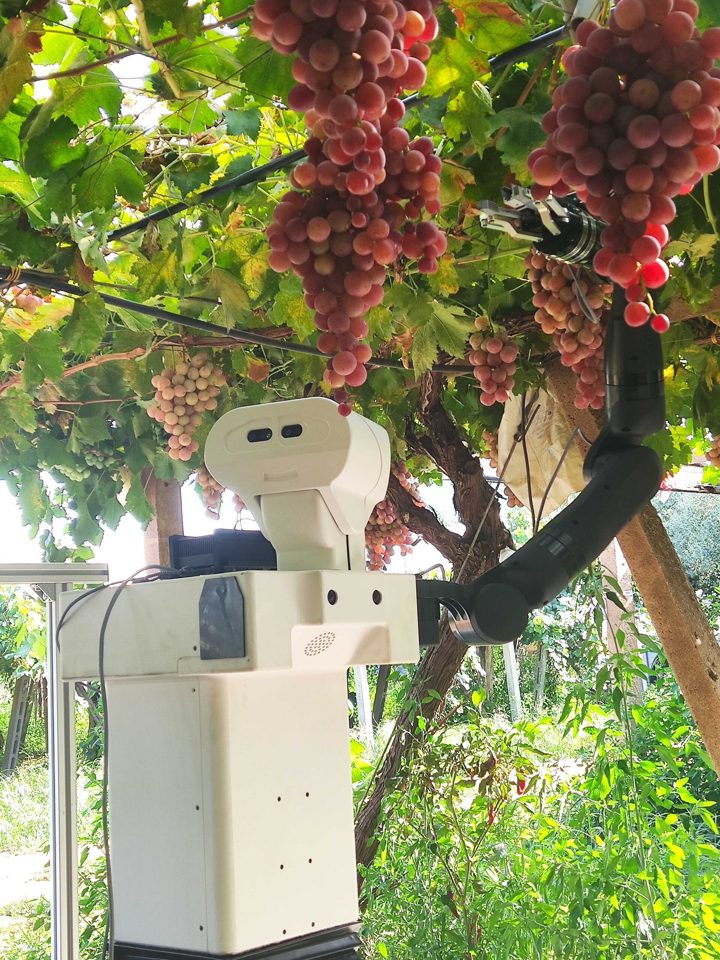
PAL Robotics reported Italian vineyard trials of an adapted TIAGo++ upper body, exploring the perception, manipulation and human interaction required for collaborative grape harvesting and pruning research.
Source PAL Robotics
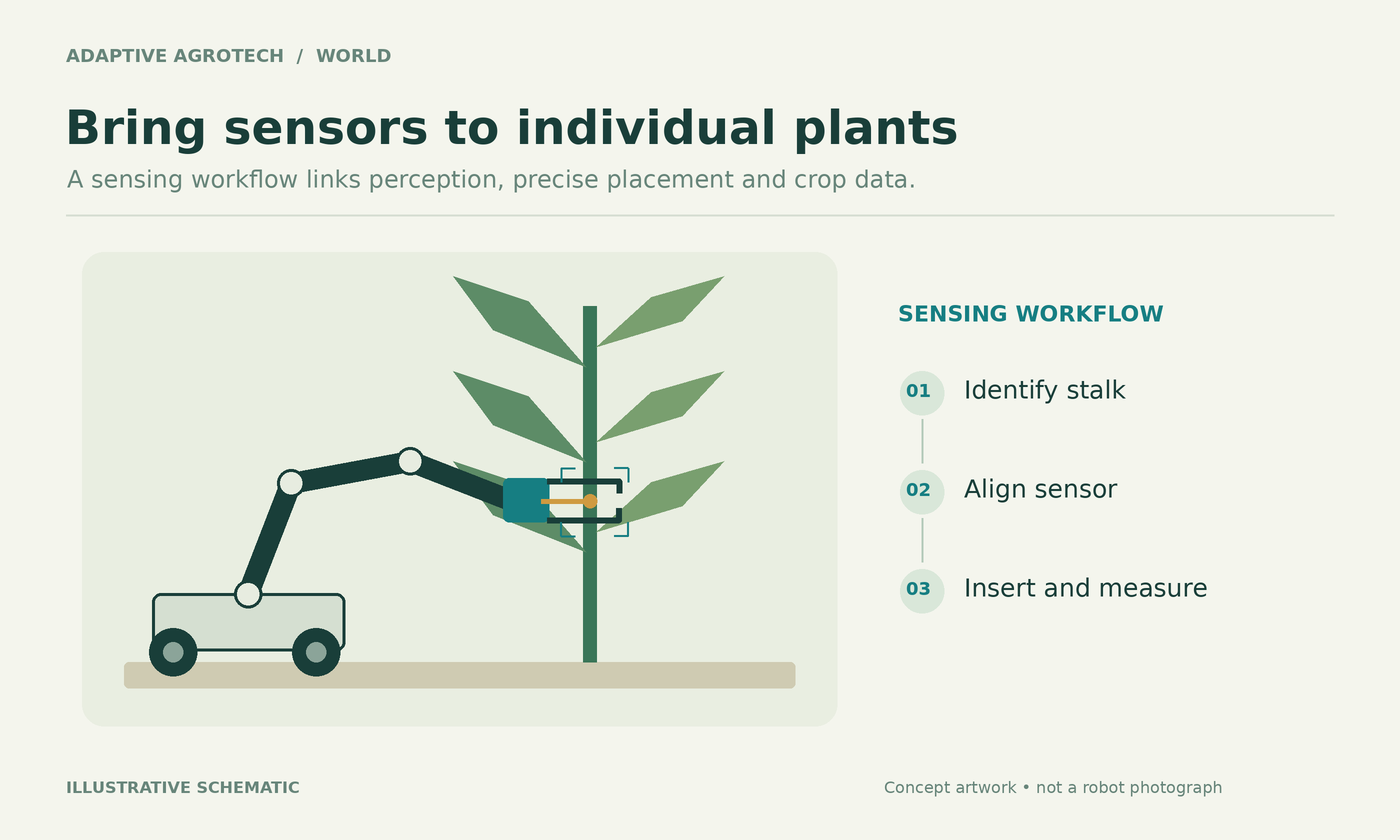
Historical example: Carnegie Mellon and Iowa State researchers combined stalk detection, a custom gripper and plant nutrient sensors.
Source Carnegie Mellon University — Robotics Institute