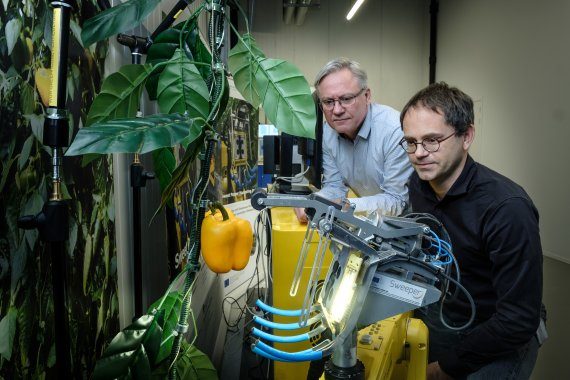
Wageningen’s Resource reported in November 2018 on SWEEPER, a sweet-pepper harvesting robot developed with Dutch, Swedish, Israeli and Belgian partners. The machine combined mobile positioning, colour and depth imaging, controlled lighting and an end-effector that cut and caught the fruit.
The report described an average cycle of about 24 seconds per pepper, compared with roughly six seconds for manual picking in its comparison. It also stressed the importance of accessibility: the robot could not reach or identify every ripe fruit in existing greenhouse arrangements. Around 55 percent was reported under conditions involving declustering and removal of obstructing foliage. These historical trial figures are useful precisely because they expose the conditions behind a demonstration rather than implying complete autonomous harvesting.