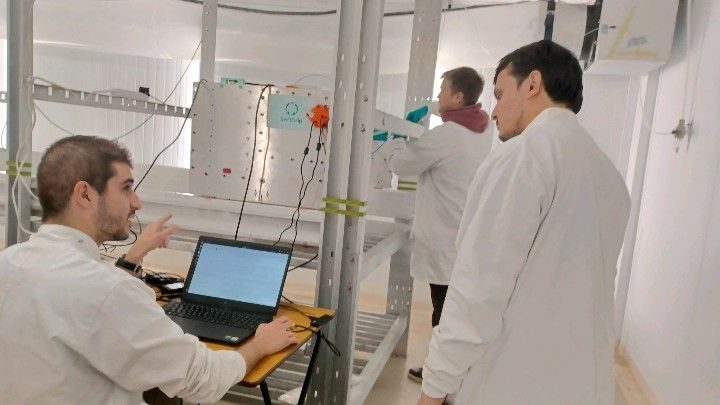
In a results brief last updated on 22 November 2024, CORDIS reviewed SoftGrip, coordinated by Italy’s Sant’Anna School of Advanced Studies. The team developed a mushroom-harvesting prototype with a soft gripper and vision algorithms that identified mushrooms and reconstructed their three-dimensional geometry.
Initial evaluation in Athens was followed by testing in an Irish growing environment. The latter faced equipment damage during transport and a mushroom-bed height that required mechanical adaptation, reducing the time available for trials. The account reported picking times ranging from 50 to 140 seconds, with speed deliberately limited during development. Those details make the story a research-stage assessment rather than evidence of commercial harvesting throughput. They also show why successful laboratory manipulation is only one component of deployment in a working food-production facility.