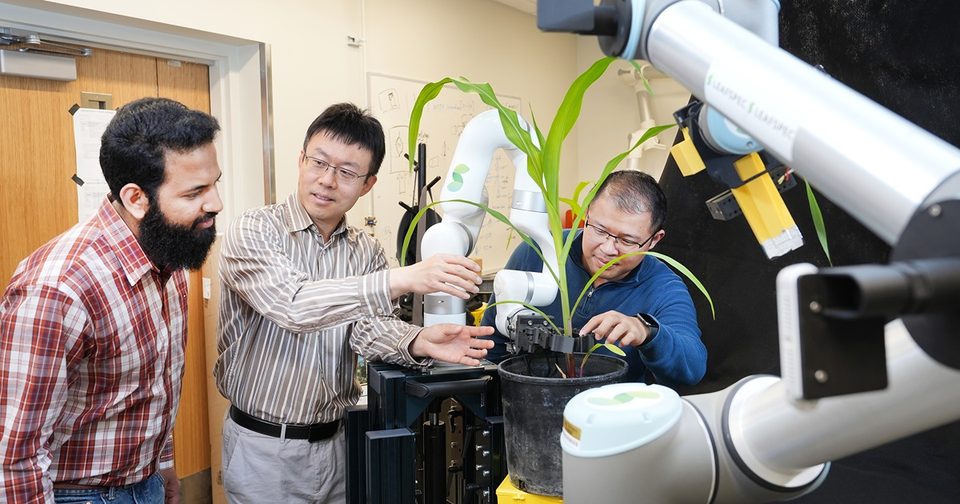
Purdue University reported a collaboration between Yu She’s robotics laboratory and Jian Jin’s agricultural engineering team to automate plant measurements. The system uses two robotic arms: one stabilises a corn plant while the other moves an imaging device along a leaf.
A camera-based tactile sensor observes deformation in a compliant contact surface, helping the robot respond to plant geometry and contact forces. The work builds on LeafSpec, a handheld plant-imaging tool, and addresses the time required to scan leaves manually. The June 2024 report described the arms as stationary and presented mobile or aerial deployment as a future possibility. It therefore demonstrated a laboratory manipulation workflow, not an autonomous machine already scanning entire commercial fields.