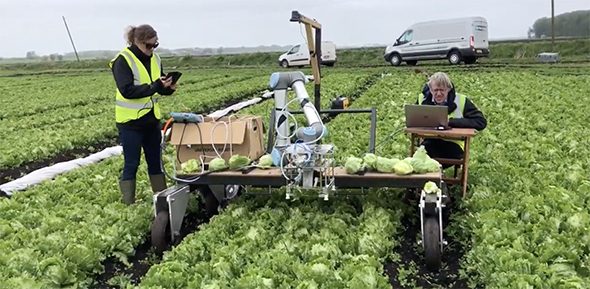
Cambridge engineers tested Vegebot in cooperation with G’s Growers, extending a laboratory lettuce-harvesting system into different field conditions. The team, led by Fumiya Iida and including Simon Birrell, Josie Hughes and Julia Cai, combined machine learning with a purpose-built cutting and handling mechanism.
An overhead camera assessed whether lettuce heads were suitable for harvesting, while a second camera near the blade helped position the cut. Adjustable gripping pressure sought to secure each head without crushing it. The July 2019 report explicitly described the prototype as slower and less efficient than a human worker. Its importance was a field-tested demonstration of the linked perception and manipulation challenges, rather than an announcement of commercially competitive automated harvesting.