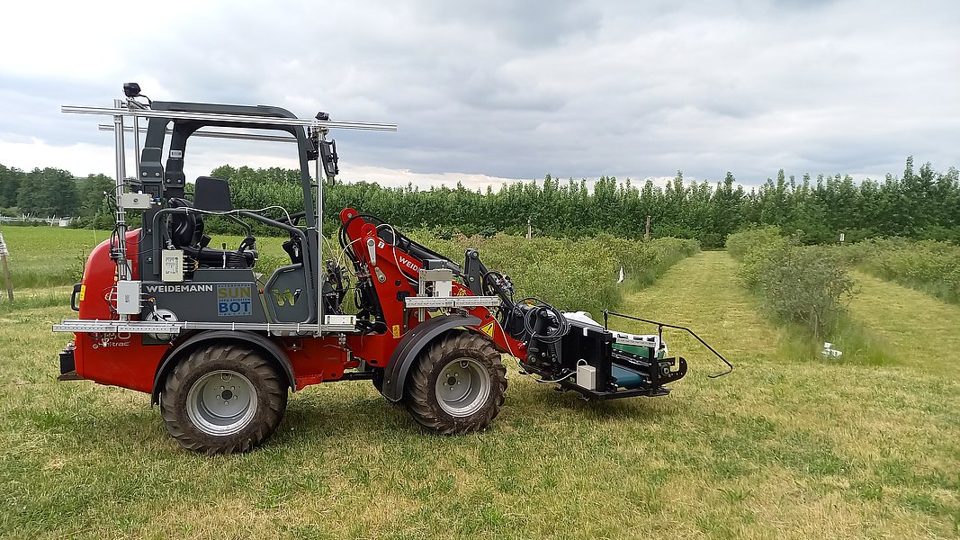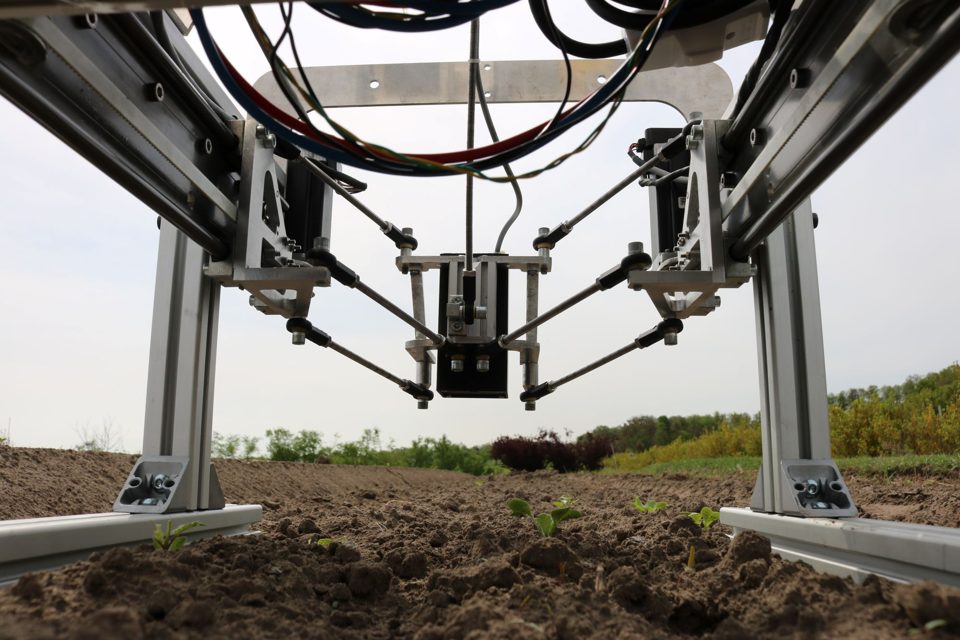
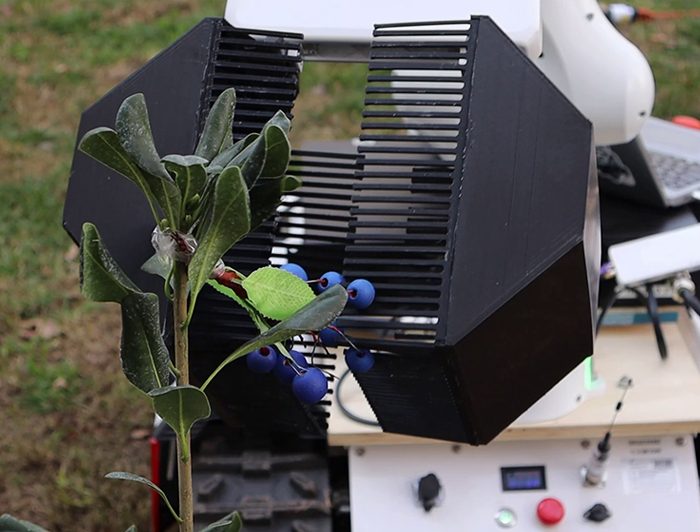
Researchers in engineering at Pontificia Universidad Católica de Chile, led by Professor Miguel Torres, reported development of a mobile robot with two manipulating arms. The March 2025 announcement describes a platform designed for uneven ground and collaborative, coordinated interaction with its surroundings.
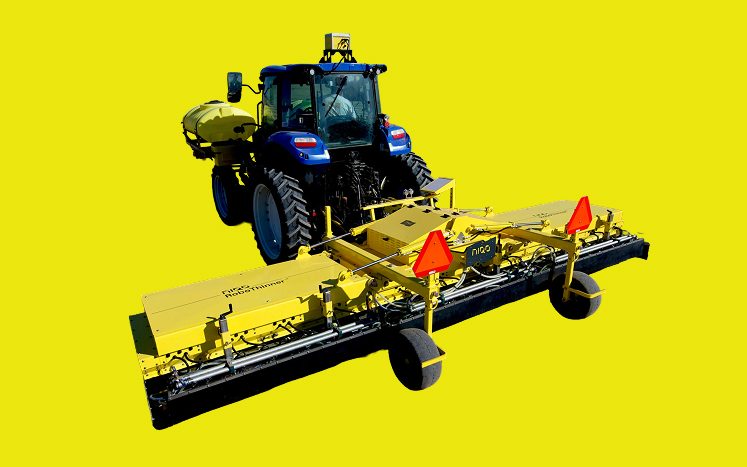
The intended agricultural applications include pruning, weeding, thinning, fertiliser application and harvesting delicate fruits such as cherries, blueberries and nectarines. AI methods are being used to make the robot adapt to different conditions rather than execute only fixed routines. The researchers were still refining perception and sensing. These activities establish a research direction for versatile field manipulation; the source does not provide task-by-task commercial performance, validated harvest rates or evidence that all listed applications were already operational.