59 stories in Field robotics.
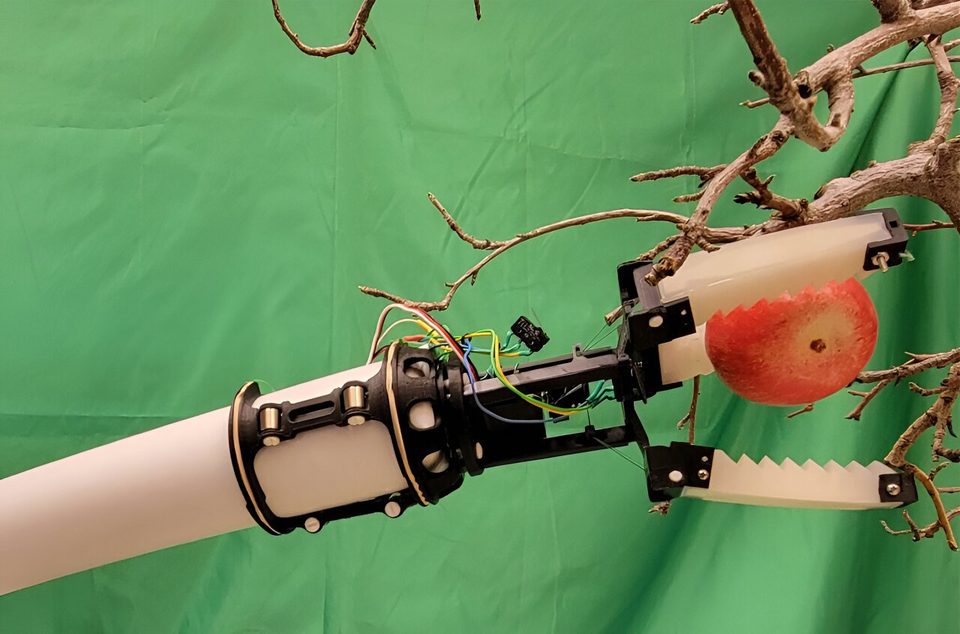
Washington State University reported a gentle apple-gripping design in June 2024, taking inspiration from human picking and planning its integration with a lower-cost robotic arm and vision system.
Source WSU Insider
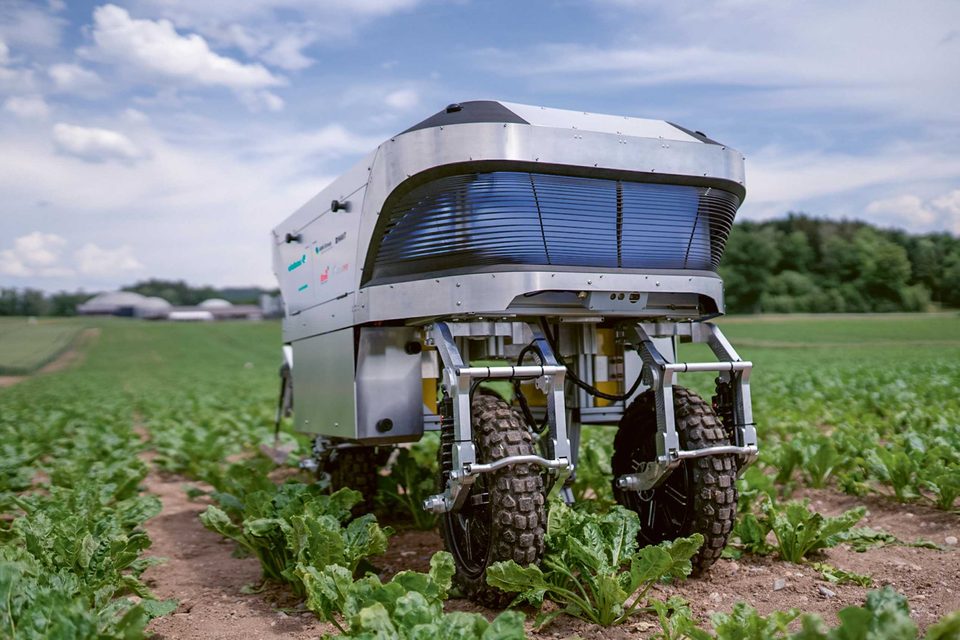
ETH Zurich highlighted a July 2024 award for research on planning autonomous routes through orchards and vineyards, developed within the Lonomy programme and building on earlier agricultural robotics work.
Source ETH Zurich
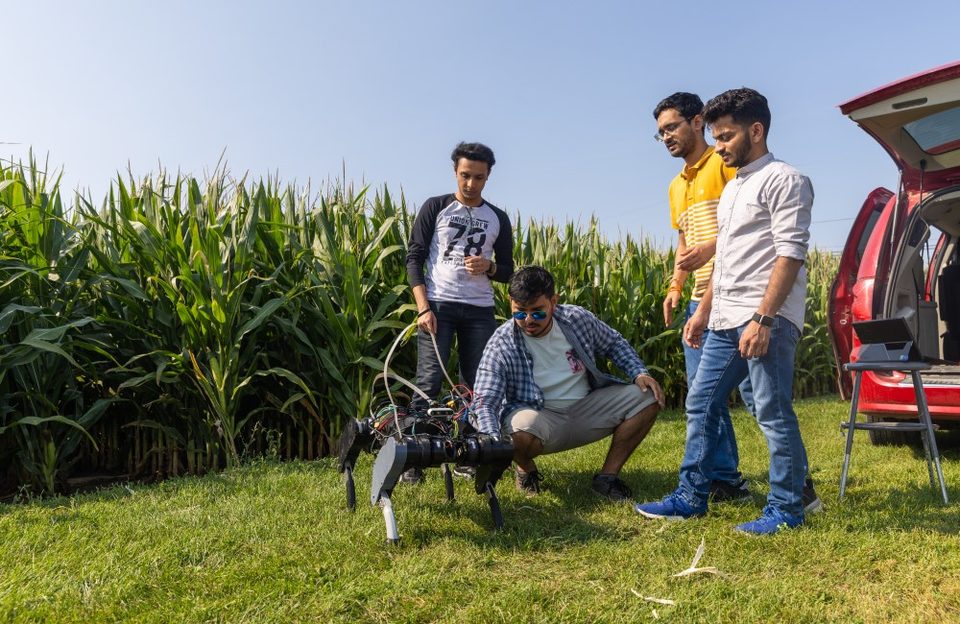
Ce Yang’s University of Minnesota laboratory presented a small quadruped prototype in October 2024, exploring how legged mobility could support wheat disease phenotyping where other observation platforms struggle.
Source University of Minnesota CFANS
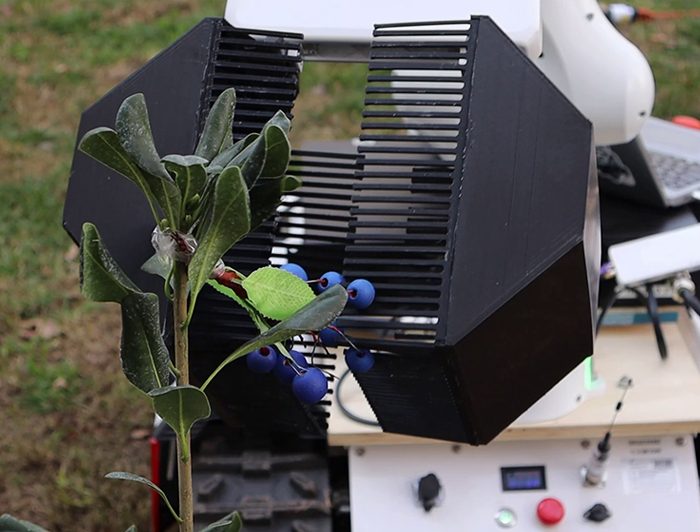
A March 2025 university report describes Miguel Torres’s team developing an adaptable mobile manipulator for tasks including delicate-fruit handling, with sensing and perception still being refined.
Source Pontificia Universidad Católica de Chile
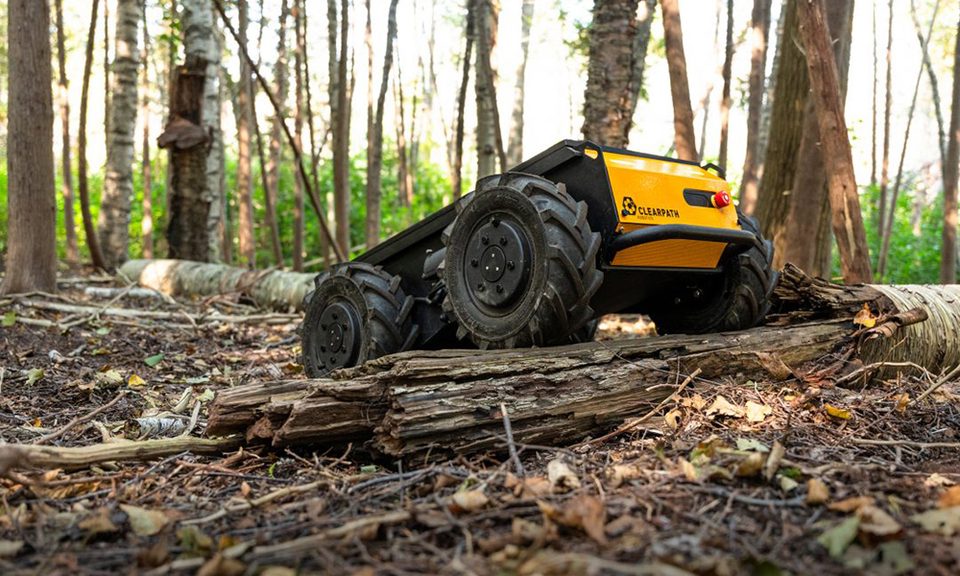
UBC Okanagan researchers received a Husky A300 platform for real-world autonomy experiments, with agricultural work involving field mapping and targeted interventions alongside a separate wildfire-research programme.
Source UBC Okanagan News
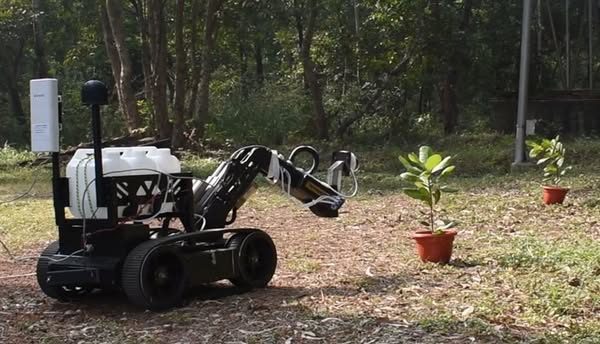
India’s Press Information Bureau reported FarmBot in May 2025, describing a semi-automatic tracked platform that combines a robotic arm, leaf-image analysis and pesticide application under agricultural research.
Source Press Information Bureau, Government of India
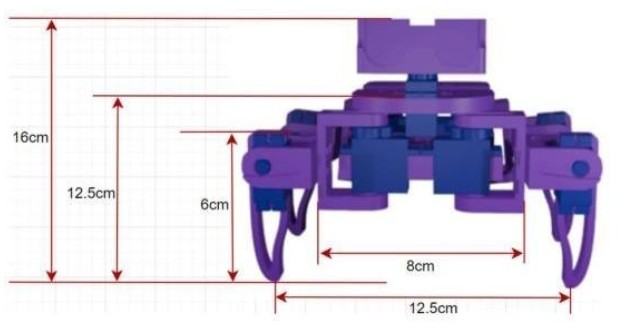
Universidad Distrital researchers reported a remotely controlled, 3D-printed legged prototype using eight servomotors and a Raspberry Pi Pico W, testing a low-cost route into agricultural terrain research.
Source Visión electrónica
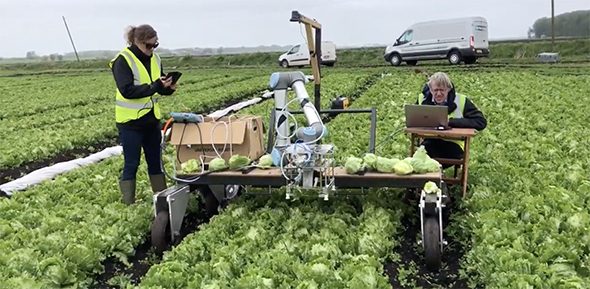
In July 2019, Cambridge reported field tests of a lettuce-harvesting prototype that identified suitable heads and controlled cutting and gripping, while openly acknowledging that human workers remained faster.
Source University of Cambridge Department of Engineering
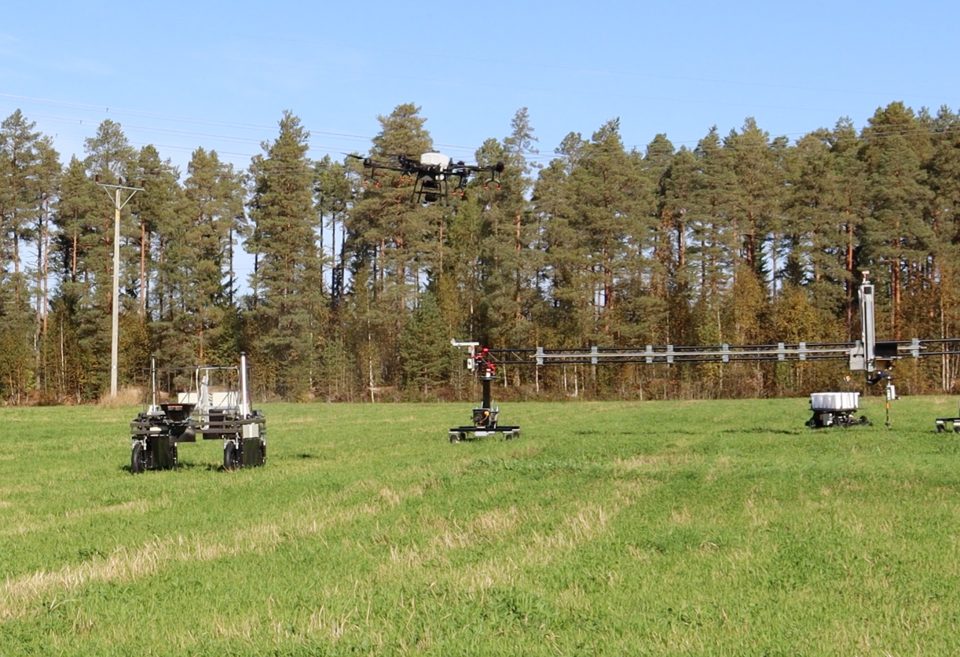
A Finnish project pilot connected machines from different suppliers through shared mission software, testing how farms, robot operators and AI providers could cooperate in the same agricultural workflow.
Source FlexiGroBots / VTT / Luke
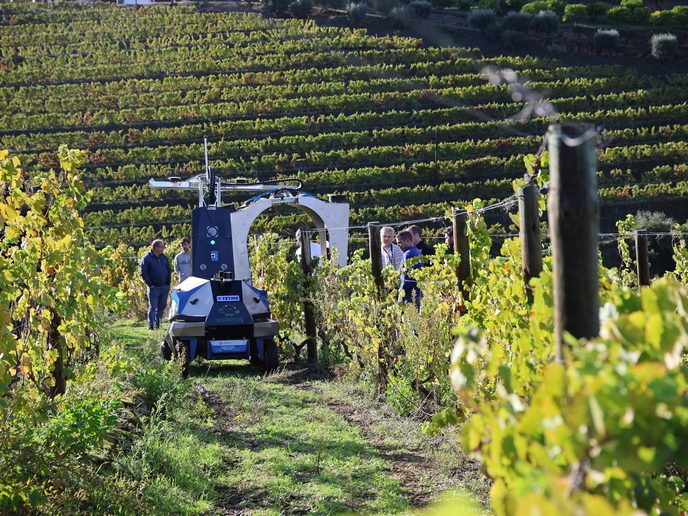
A European research project integrated positioning, perception and variable-rate spraying into the WETA robot, addressing the difficulties of moving and applying treatments in narrow, sloping vineyard environments.
Source European Commission — CORDIS
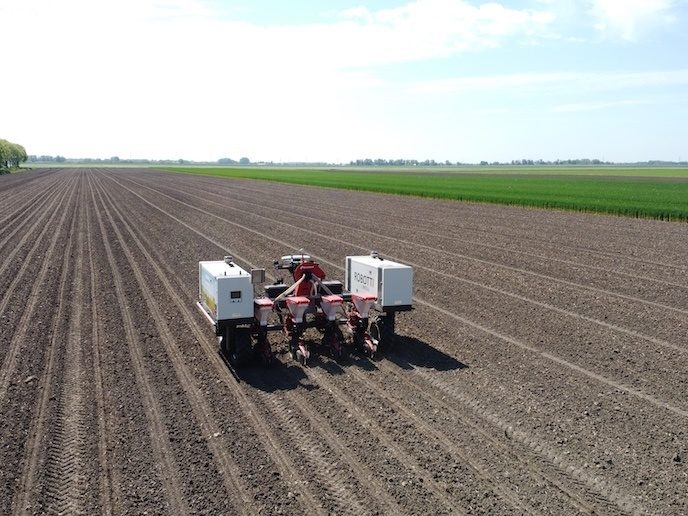
The completed European project reported a robotic crop-care system that combines vehicles, implements and supervisory software, with field pilots examining both operational performance and barriers to adoption.
Source European Commission — CORDIS
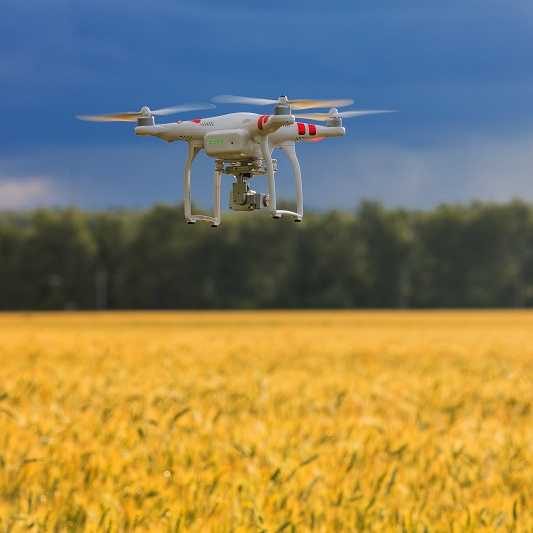
The European research project paired aerial crop observations with the Bonirob ground platform, exploring how information collected over a field could guide local mechanical or chemical interventions.
Source European Commission — CORDIS