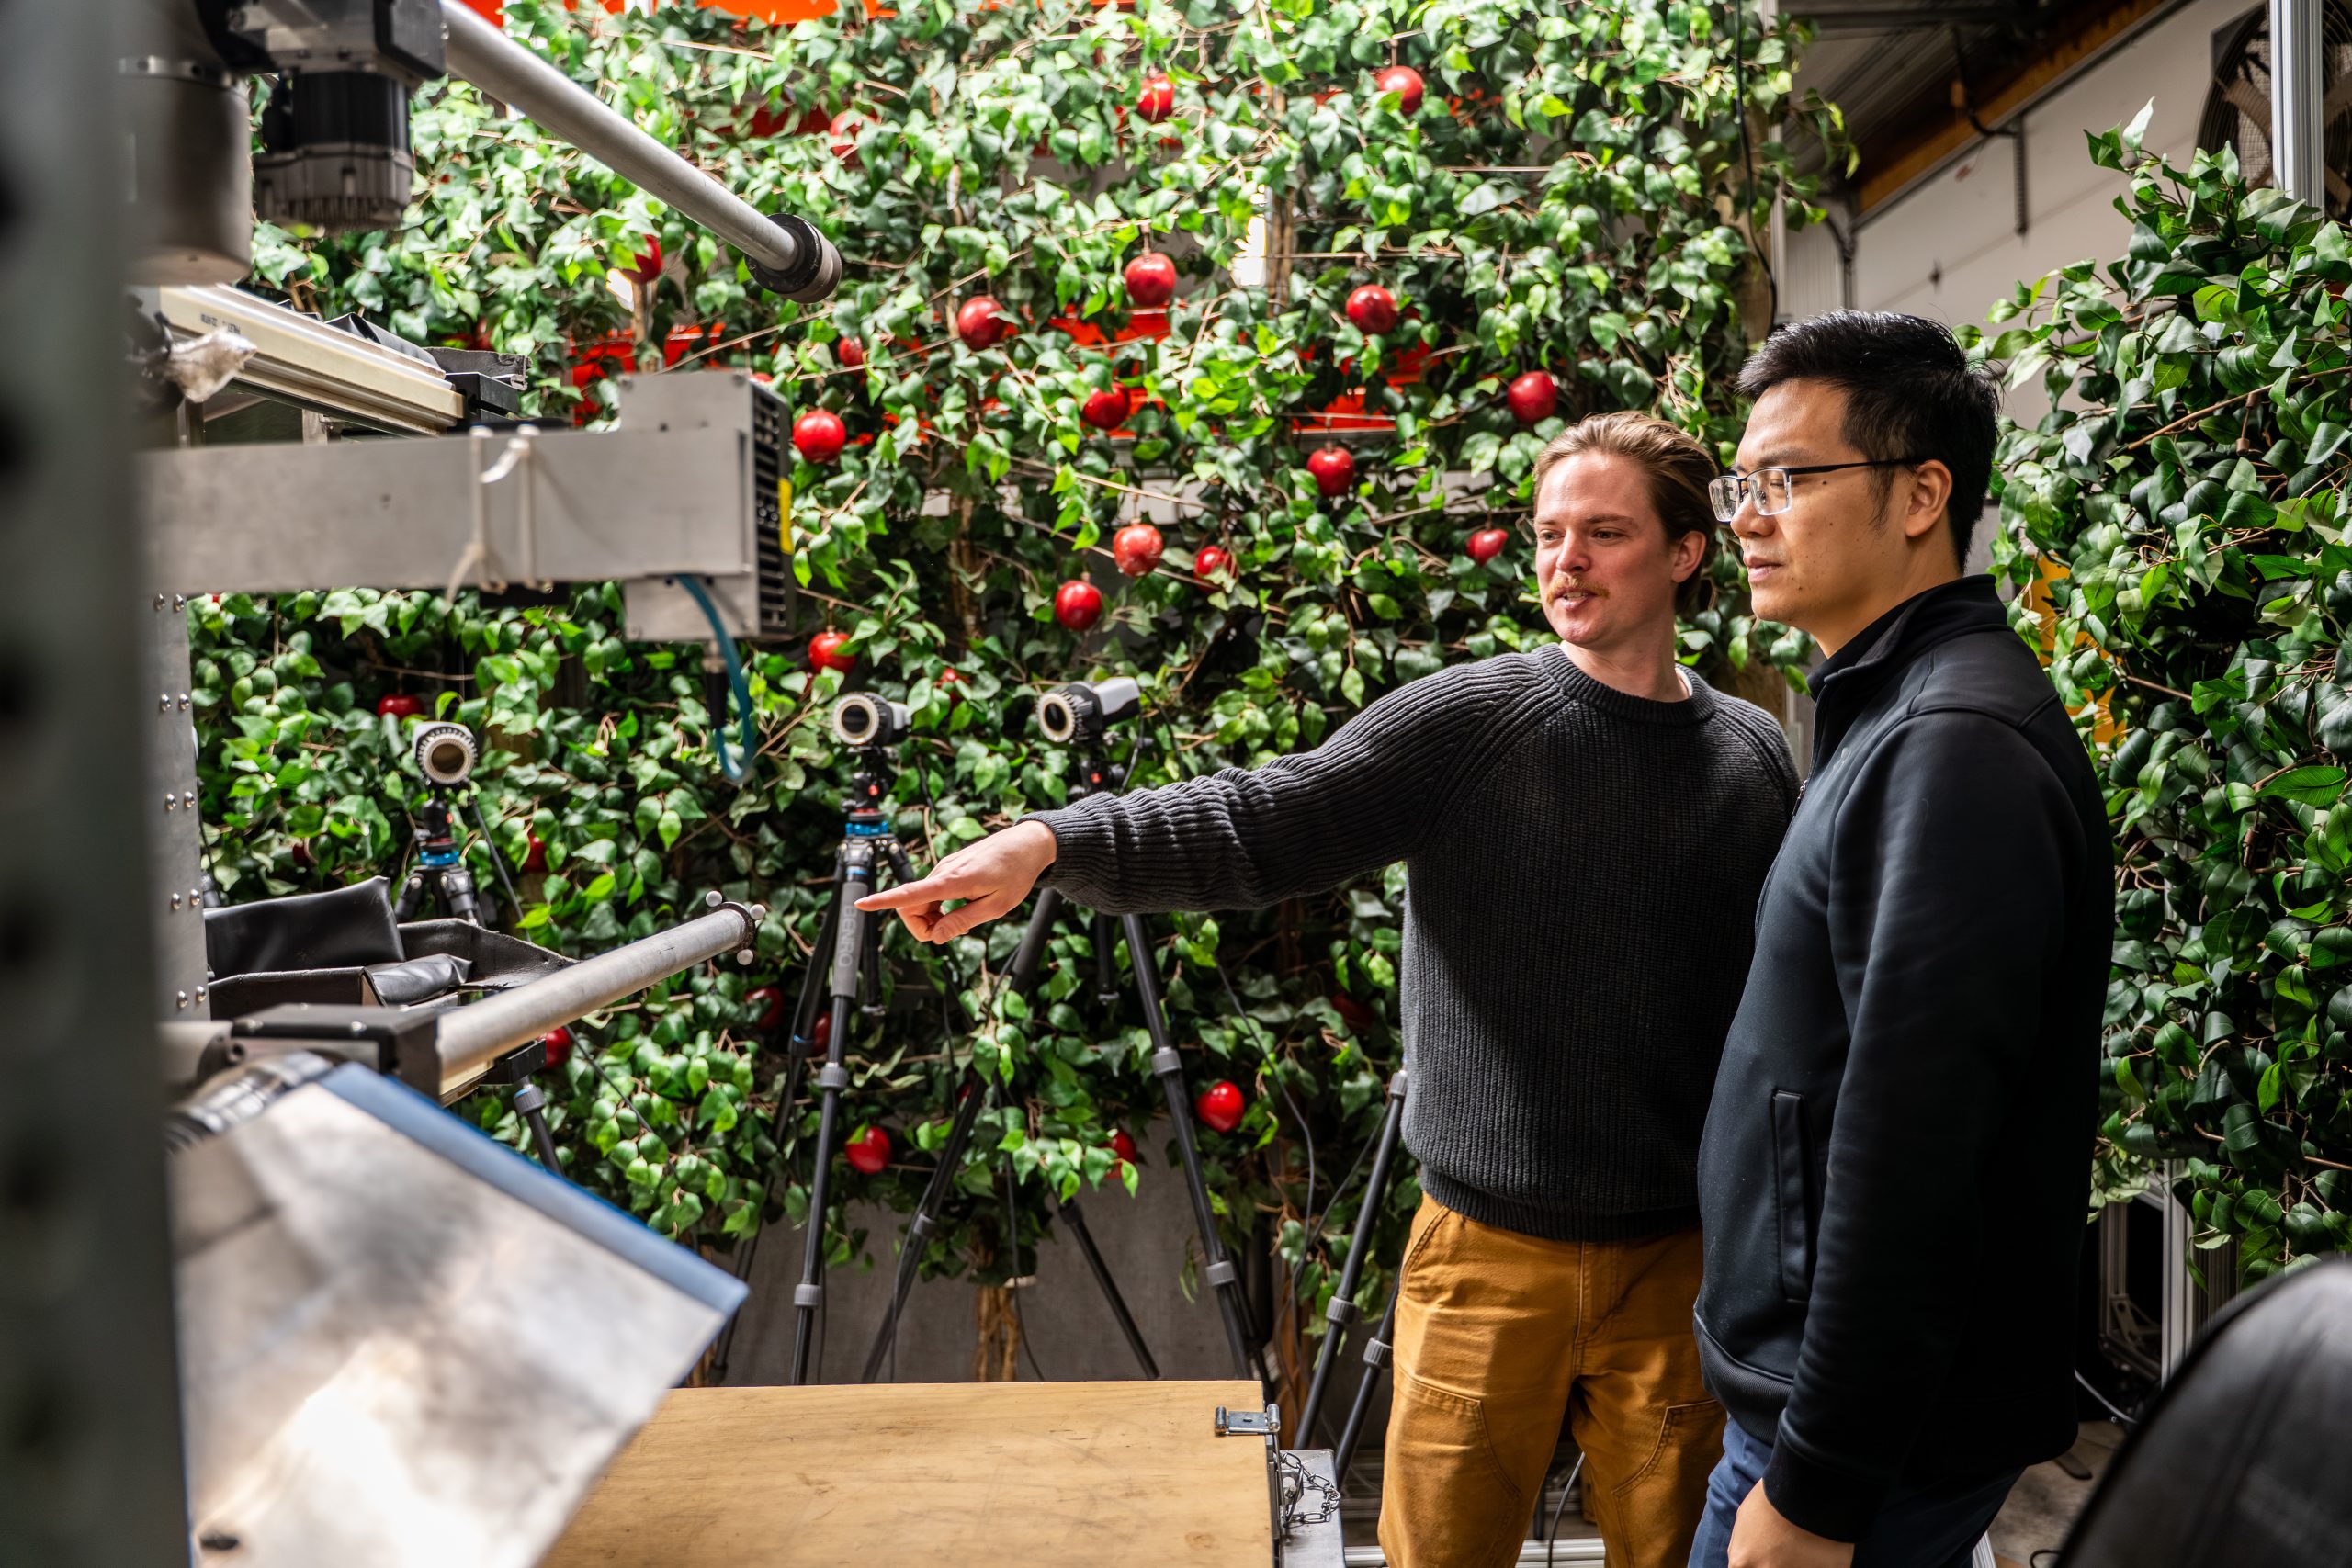
Michigan State University highlighted research on the AgriDynamic Robotics Apple Harvester, a system using three-dimensional vision and two robotic arms with soft vacuum grippers. The university reported an 85% picking success rate and a three-to-four-second cycle per fruit for the research system. Those results were presented in a technology-development context, not as independent evidence of a commercially deployed fleet.
The university also presented a potential 20% reduction in farm labor cost, which should be read as a developer claim rather than a verified industry-wide outcome. The researchers plan to combine several dual-arm modules on a larger platform and investigate other high-value crops. Reliable operation, fruit bruising and complete field throughput remain important deployment questions.