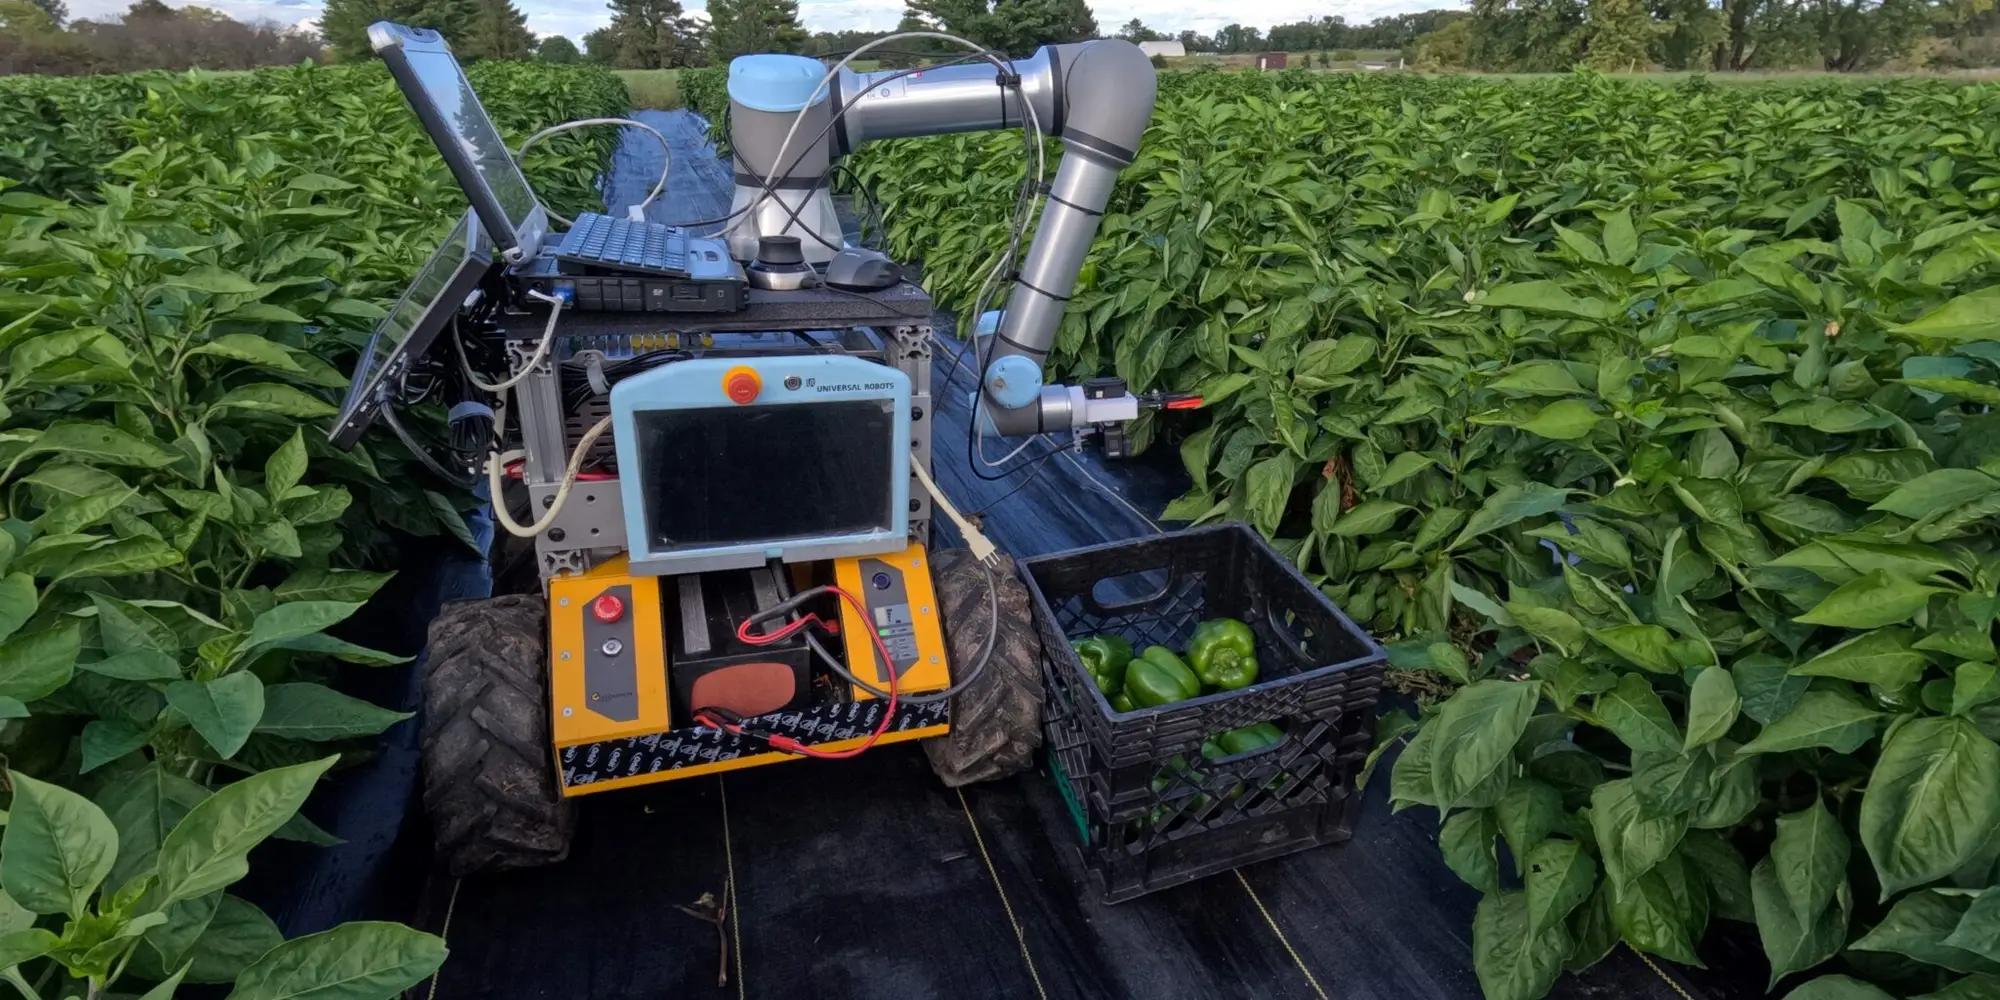
Carnegie Mellon University described plans to expand off-road robot testing through its Robotics Innovation Center, including outdoor environments where agricultural machines can work around real crops. Research professor George Kantor’s group has developed platforms for inserting nitrate sensors into corn stalks and explored robot-assisted pepper harvesting. The February update emphasized more direct access to practical testing rather than announcing a new commercially available farm machine.
The university said researchers previously relied partly on artificial plants and distant field partners. Local outdoor trials should let teams investigate crop interaction, mobility and perception earlier in development. The broader facility will also support work on legged mobility and autonomous soil sampling for difficult sites, though those activities have different applications and evidence requirements.