16 stories matching “Navigation”.
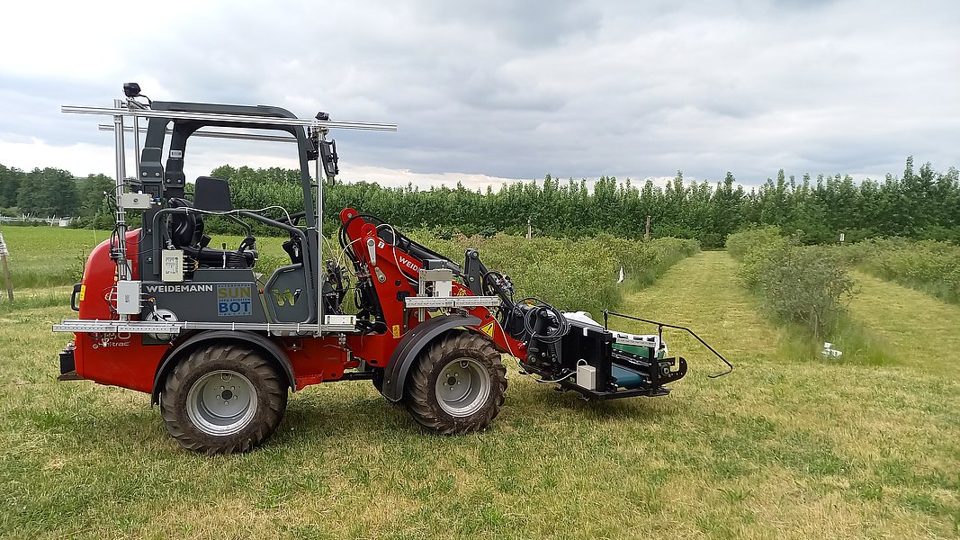
ATB presented a working SunBot prototype for autonomous mowing in berry plantations, combining electric implements, satellite navigation and obstacle sensing while identifying robustness as a remaining development challenge.
Source Leibniz Institute for Agricultural Engineering and Bioeconomy (ATB)
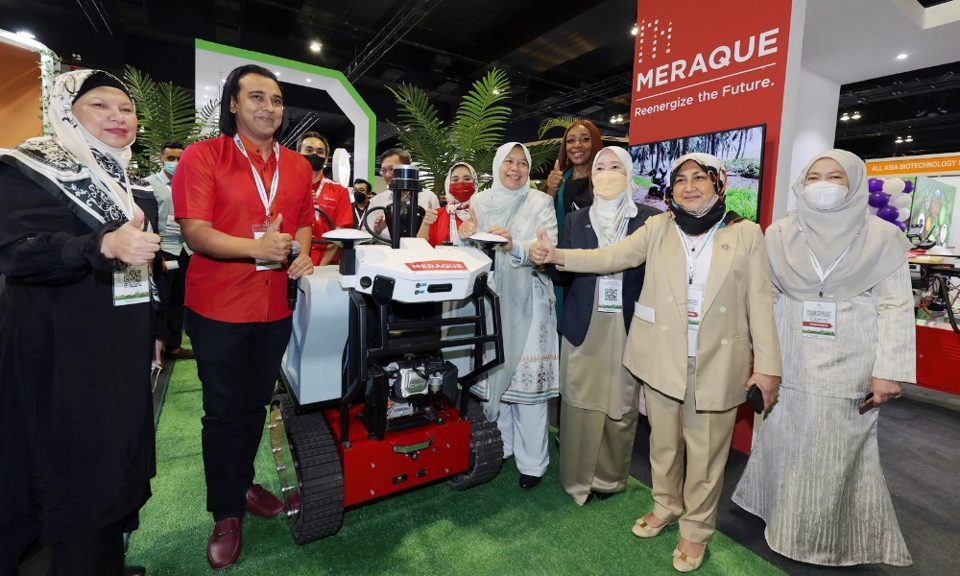
Meraque’s 2022 RACE announcement extended its plantation automation work from drones to ground vehicles, with spraying prototypes and a staged plan for larger payloads and coordinated fleets.
Source Meraque Group
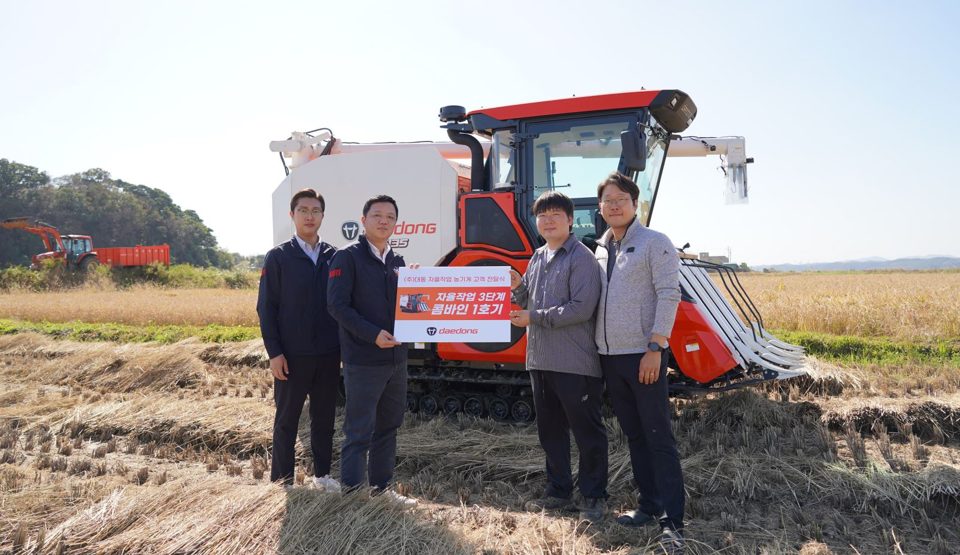
Daedong’s October 2023 DH6135-A launch linked automated combine operation with yield measurements that could be reviewed through its connected-farming application, bringing navigation and agronomic records onto one machine.
Source Daedong
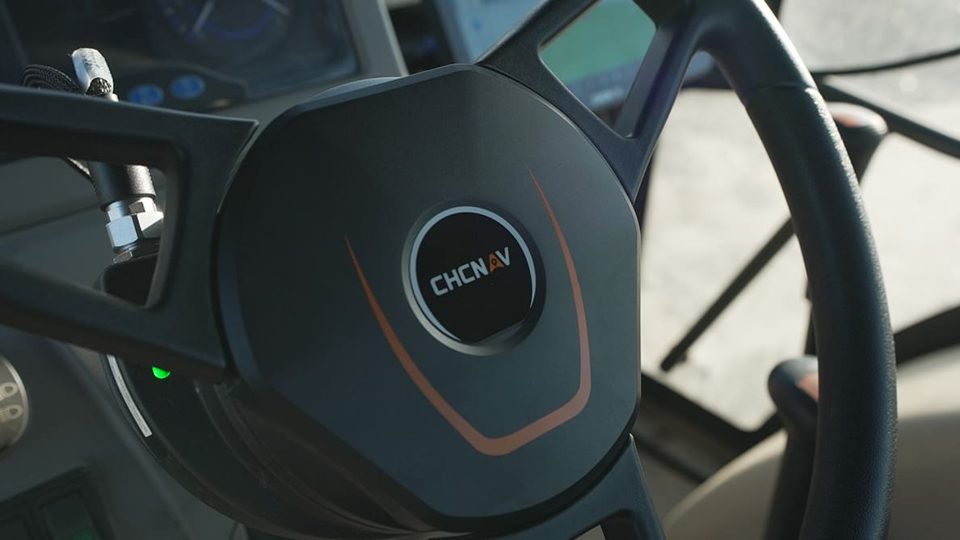
CHCNAV’s February 2025 product announcement described an automated steering package combining satellite positioning, multiple guidance patterns and implement connectivity for tractors, sprayers and other farm machinery.
Source CHC Navigation
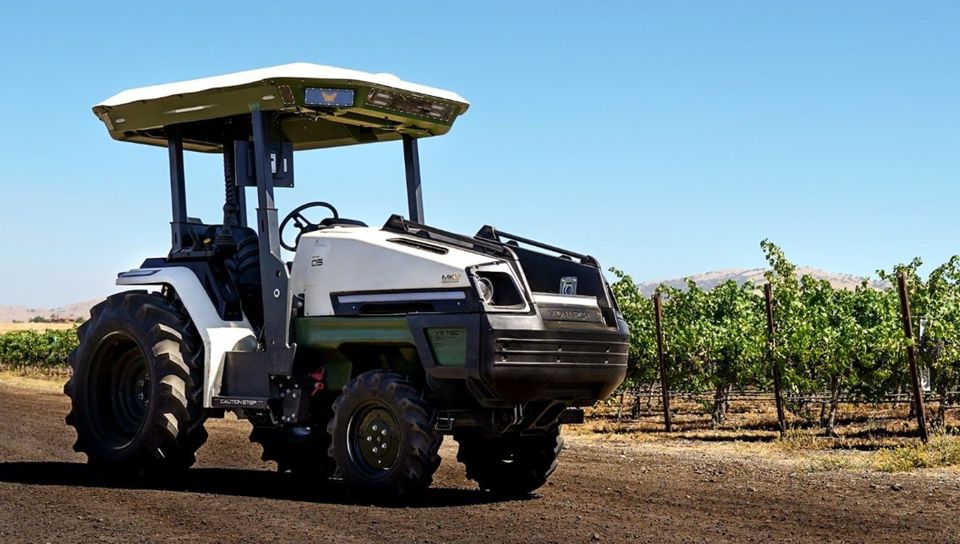
Monarch’s December 2022 production launch put electric, driver-optional MK-V tractors into a customer fleet, with NVIDIA describing how onboard cameras and Jetson modules supported navigation, monitoring and implement-related applications.
Source NVIDIA
Burro announced a $24 million Series B in January 2024 and introduced Grande, extending its outdoor carrier concept from worker-scale loads toward pallets, trailer towing and navigation between indoor and outdoor areas.
Source Burro via PR Newswire
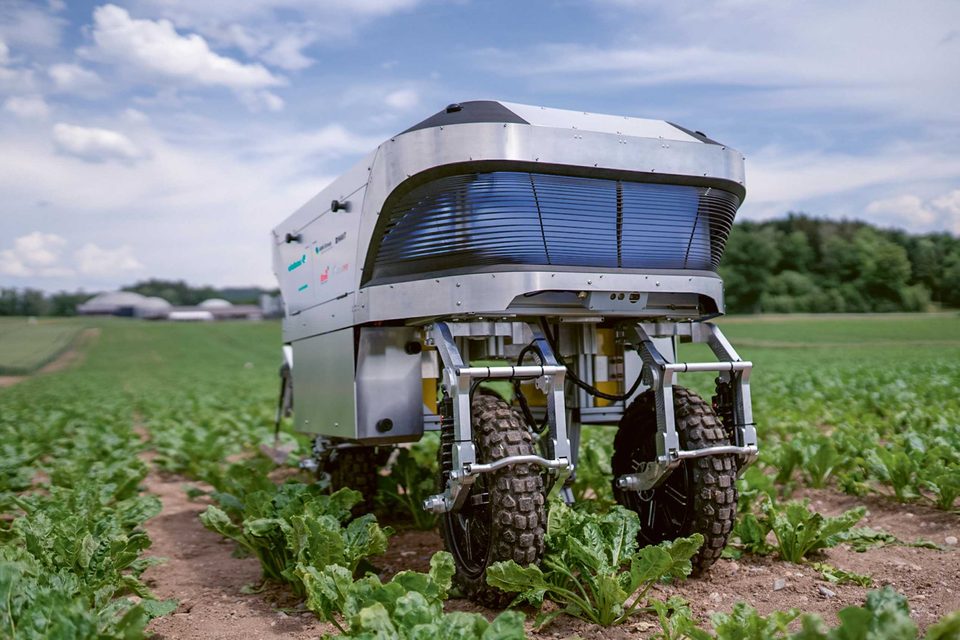
ETH Zurich highlighted a July 2024 award for research on planning autonomous routes through orchards and vineyards, developed within the Lonomy programme and building on earlier agricultural robotics work.
Source ETH Zurich
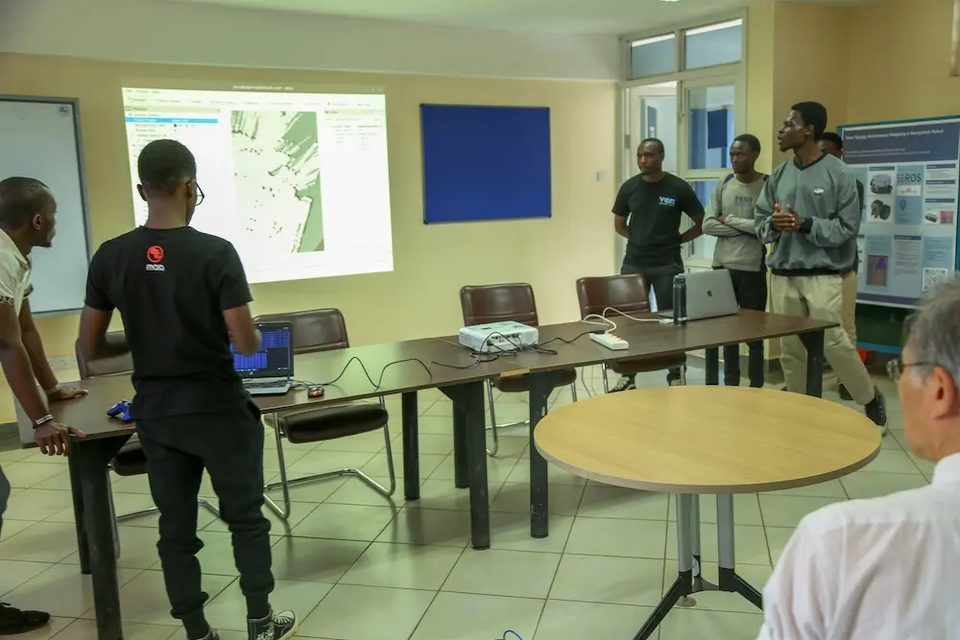
JKUAT’s October 2024 Robotics Dojo showcase focused on laser-sensor navigation, building local engineering skills relevant to future agricultural machines while remaining an educational prototype competition.
Source JKUAT Corporate Communications
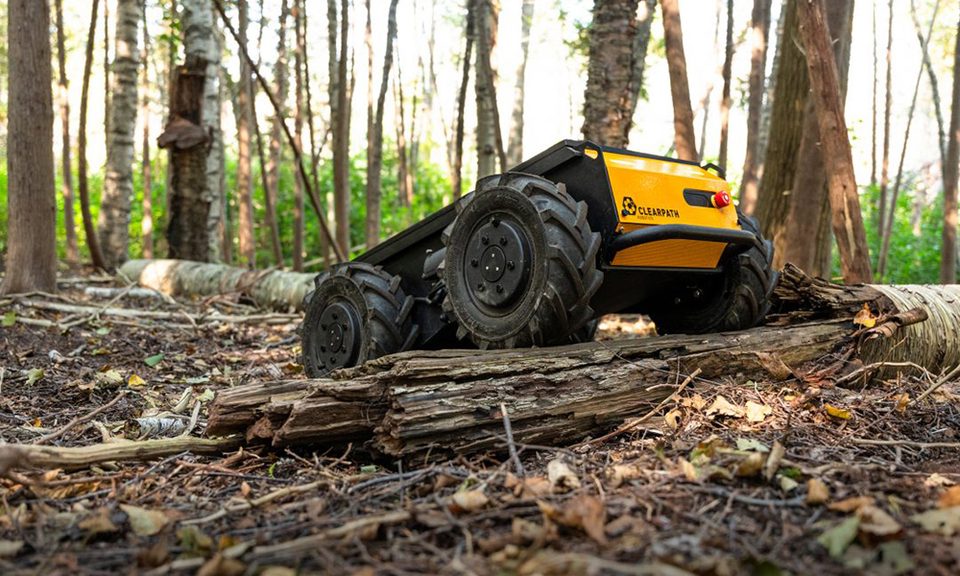
UBC Okanagan researchers received a Husky A300 platform for real-world autonomy experiments, with agricultural work involving field mapping and targeted interventions alongside a separate wildfire-research programme.
Source UBC Okanagan News
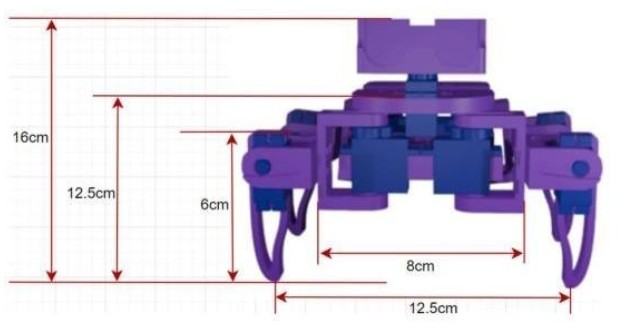
Universidad Distrital researchers reported a remotely controlled, 3D-printed legged prototype using eight servomotors and a Raspberry Pi Pico W, testing a low-cost route into agricultural terrain research.
Source Visión electrónica
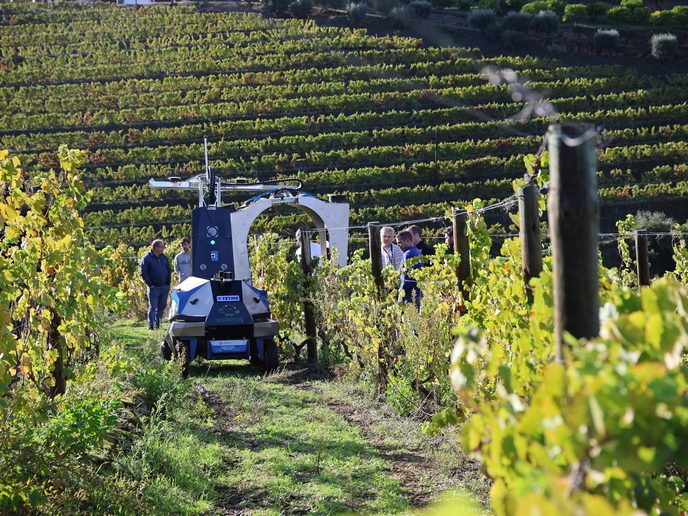
A European research project integrated positioning, perception and variable-rate spraying into the WETA robot, addressing the difficulties of moving and applying treatments in narrow, sloping vineyard environments.
Source European Commission — CORDIS
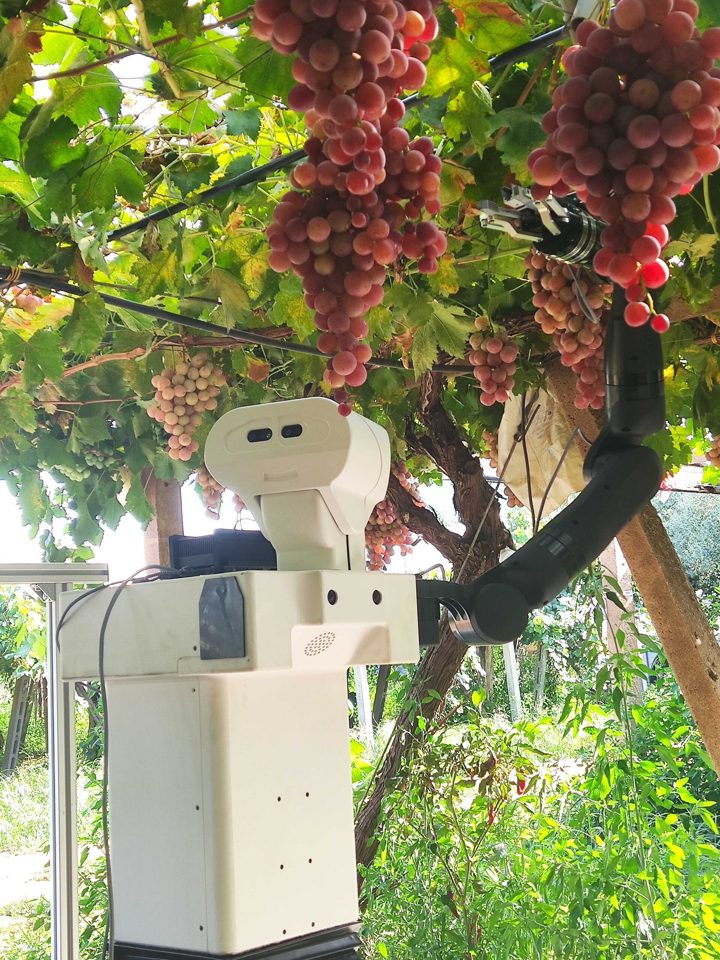
PAL Robotics reported Italian vineyard trials of an adapted TIAGo++ upper body, exploring the perception, manipulation and human interaction required for collaborative grape harvesting and pruning research.
Source PAL Robotics