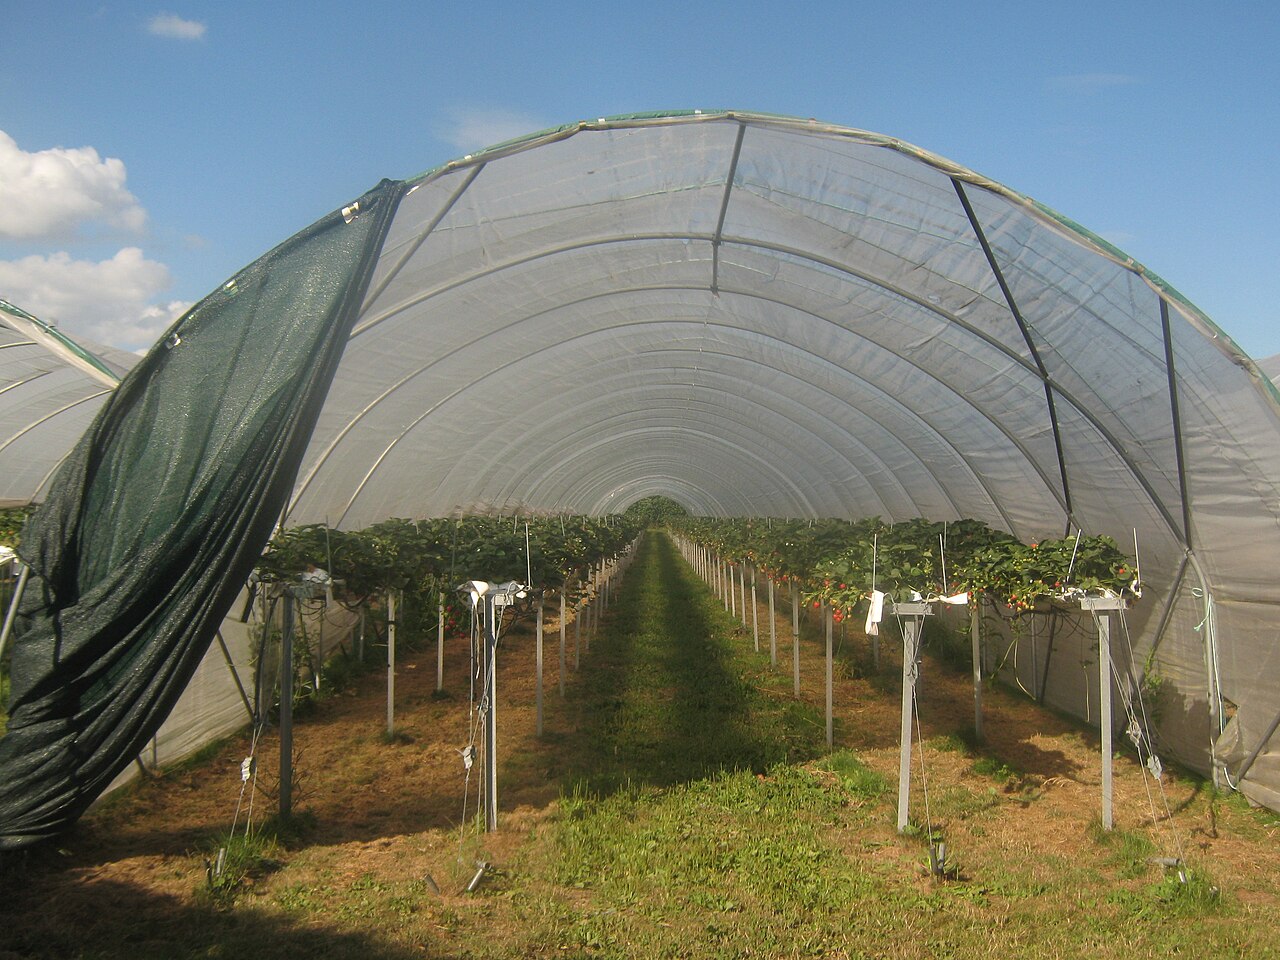
The GREENBOT paper, first posted in February 2024, describes a mobile-robot dataset collected in a Mediterranean tomato greenhouse in Almería, Spain. The instrumented platform recorded lidar, stereo-camera and inertial data while moving through crop corridors.
Nine recording sequences captured conditions during autumn 2022, including crop growth and variations in light and the ground surface. The authors used mapping methods to demonstrate the dataset’s suitability for robotics research and provided access through a University of Almería repository. Applications discussed include greenhouse localisation, three-dimensional plant modelling and future robotic spraying. The dataset is a development resource rather than a commercial navigation product.