139 stories matching “EY”.
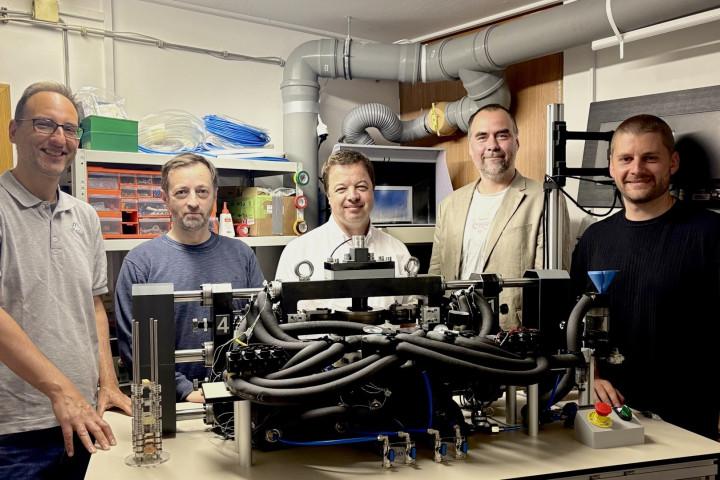
University researchers report that a LiDAR-based retrofit adapts individual sprayer nozzles to vegetation density and has been used by three vineyard growers.
Source University of Ljubljana
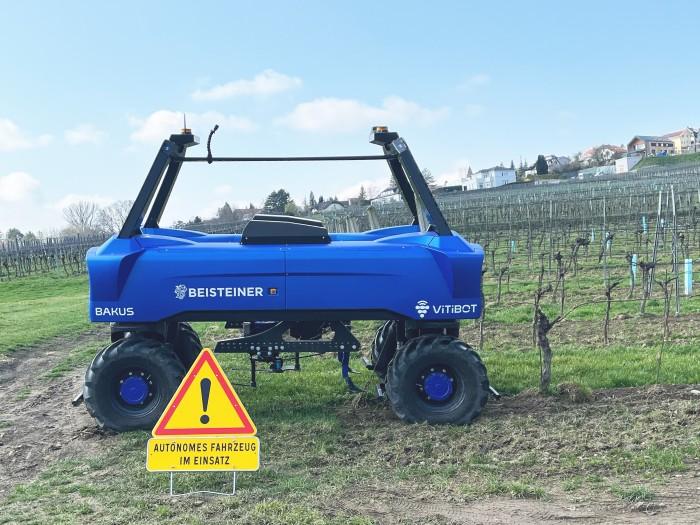
Researchers are using repeated LiDAR and panoramic mapping to build a vineyard digital twin that reflects seasonal changes affecting autonomous navigation.
Source JOANNEUM RESEARCH
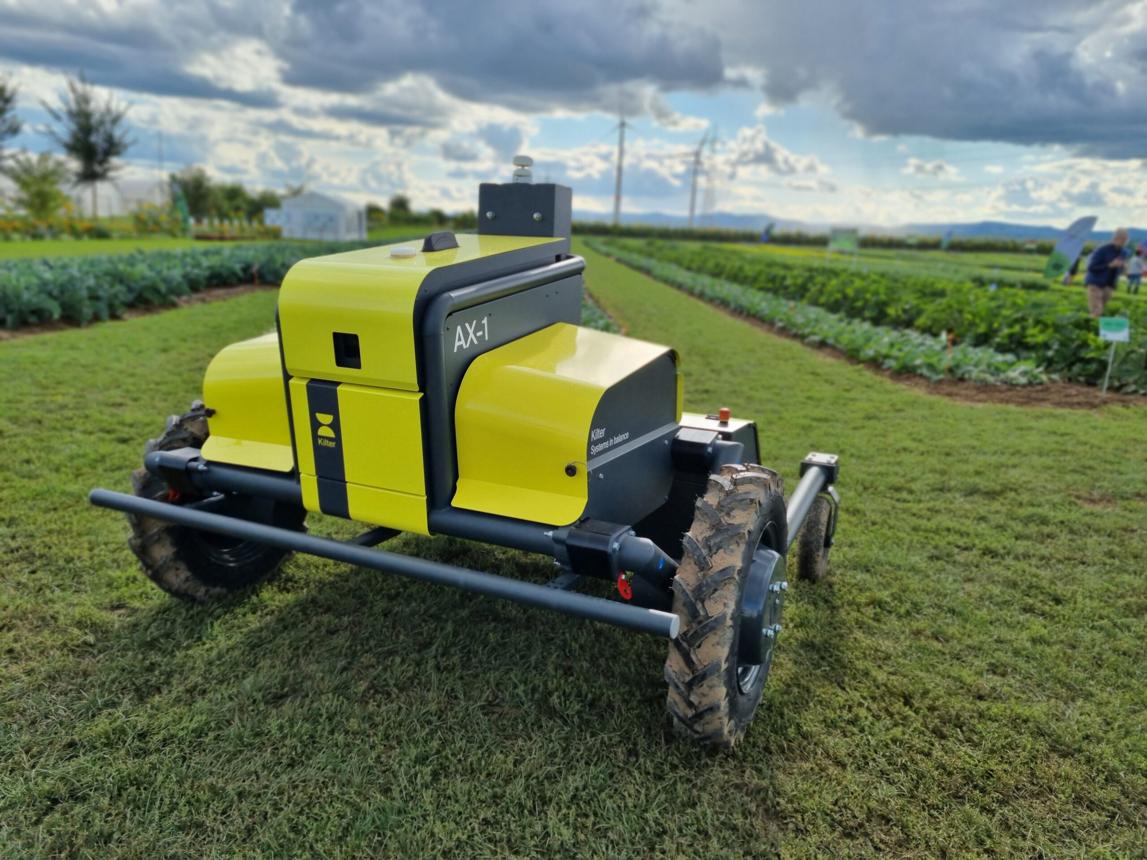
Researchers from NTNU and Kilter developed and simulated a multi-robot approach to precision weed treatment. Their results suggest that distributing fieldwork among several AX-1 robots could reduce completion times.
Source Artificial Life and Robotics / NTNU and Kilter researchers
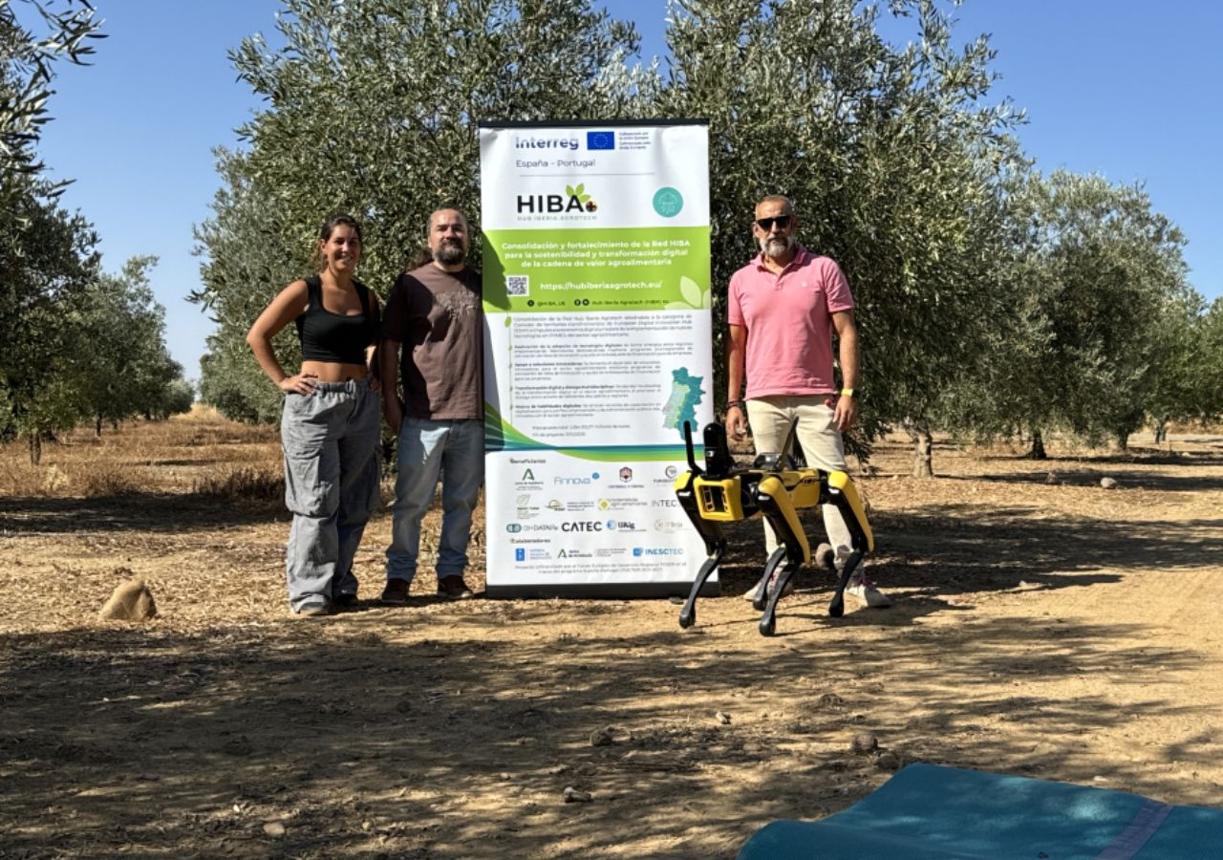
Spanish food-technology centre CTAEX demonstrated a four-legged autonomous platform intended for crop monitoring in vineyards and protected berry production.
Source CTAEX — Centro Tecnológico Nacional Agroalimentario
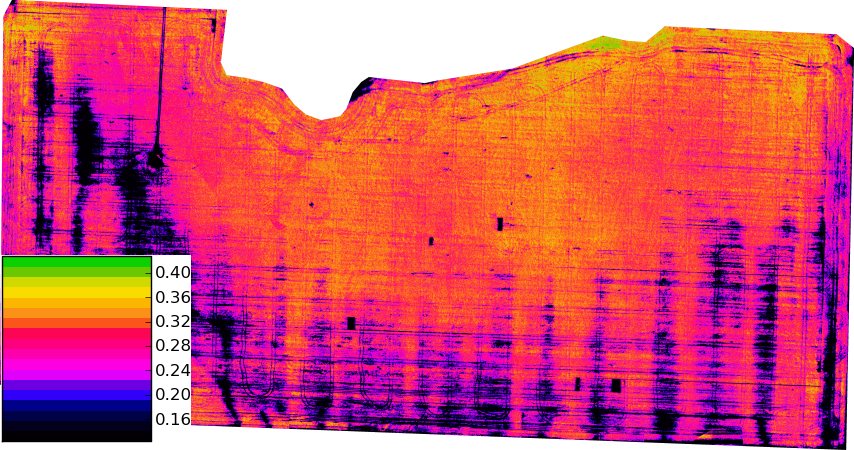
CropX launched a smartphone-based vineyard tool that interprets canopy photographs for water-stress assessment and combines the resulting estimates with other agronomic information in its existing farm-management application.
Source CropX
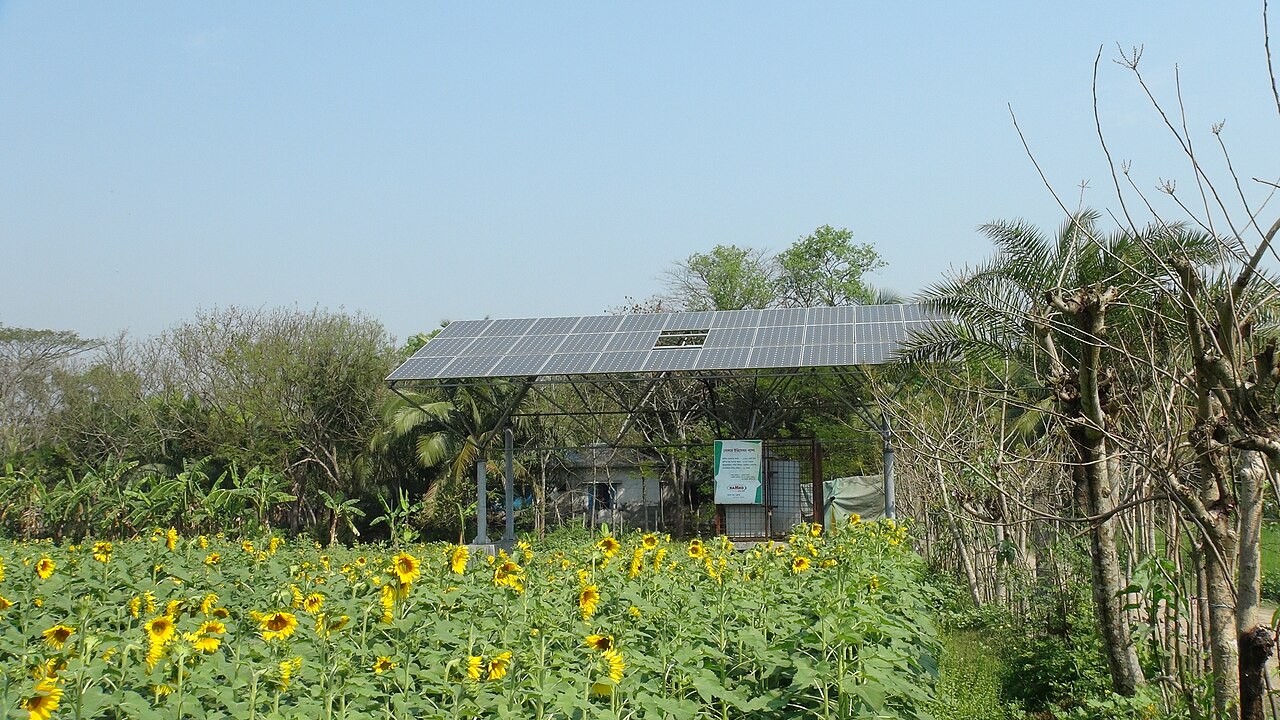
University of Washington researchers combined a global canal map with SWOT satellite observations to assess water levels across extensive Asian irrigation networks, testing a new approach to monitoring agricultural infrastructure.
Source University of Washington News
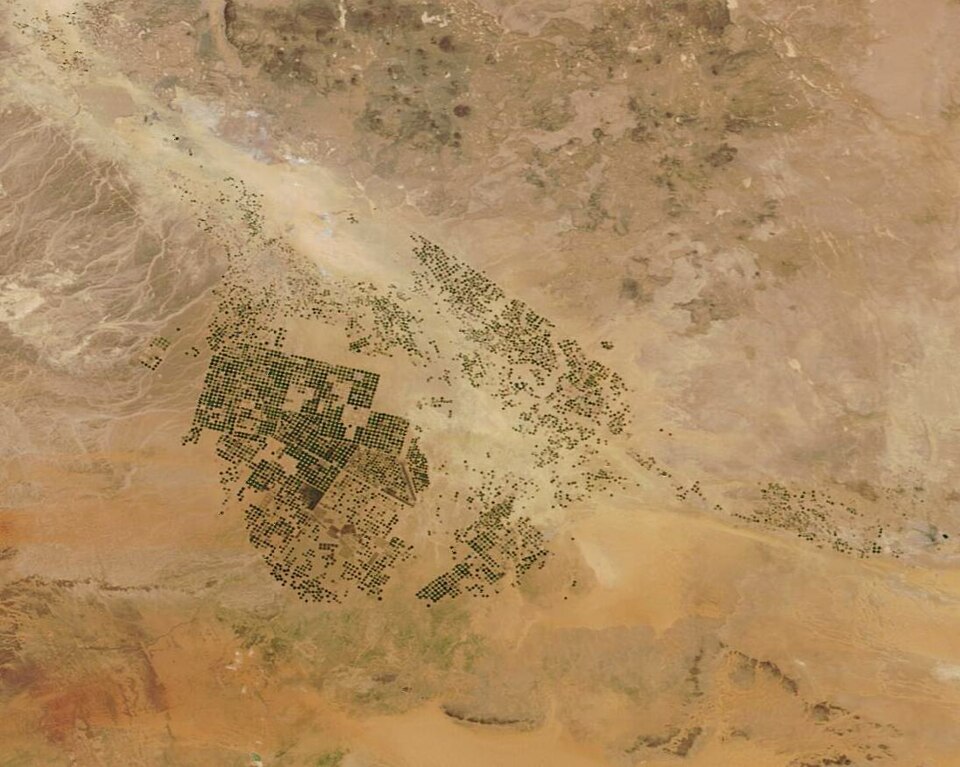
The Australian Bureau of Statistics introduced experimental irrigation-water estimates combining satellite observations and environmental models, with a methodological break from earlier survey-based figures that limits direct historical comparisons.
Source Australian Bureau of Statistics
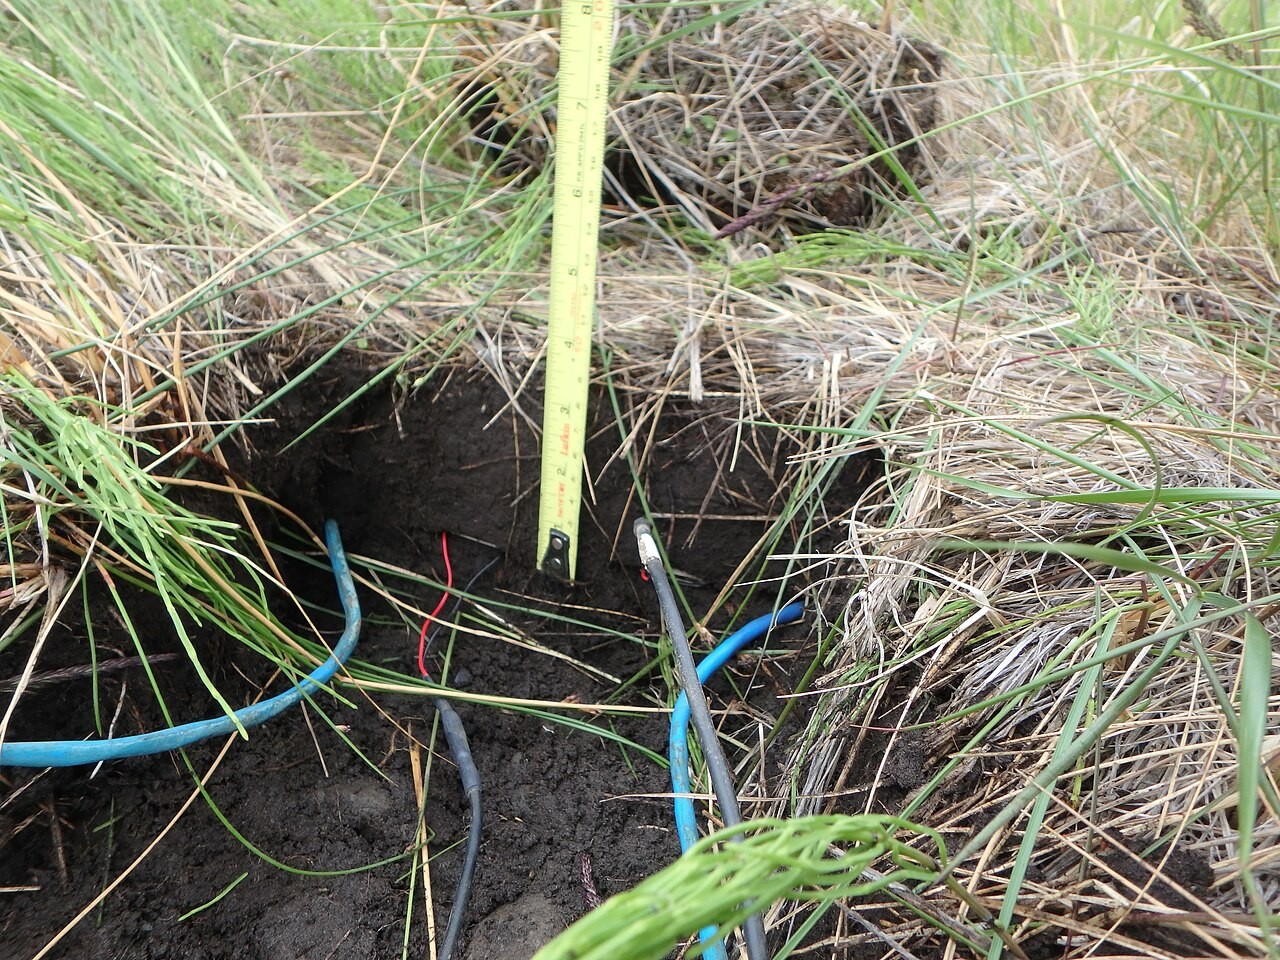
University of Colorado Boulder researchers tested inexpensive printed sensors that tracked soil acidity across varied soils and operated outdoors for months, advancing continuous monitoring beyond occasional soil sampling.
Source CU Boulder Venture Partners
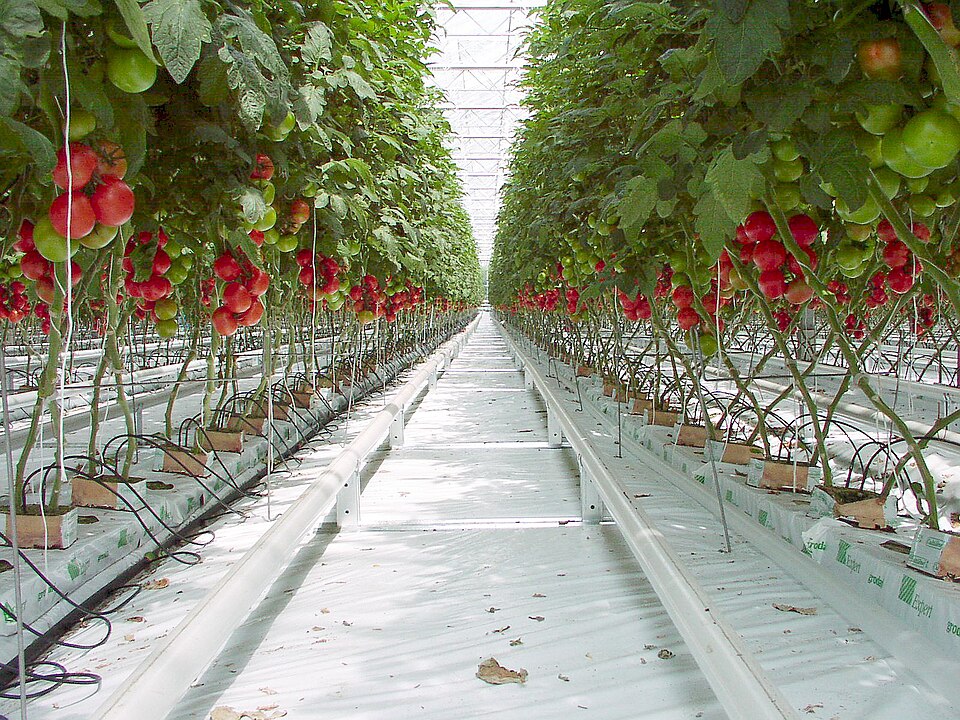
A greenhouse robotics preprint reports leaf-level spraying on cherry tomatoes, using camera-guided arm movements to reduce applied pesticide volume while measuring targeting error and overspray in twelve autonomous trials.
Source Singh et al. — arXiv preprint
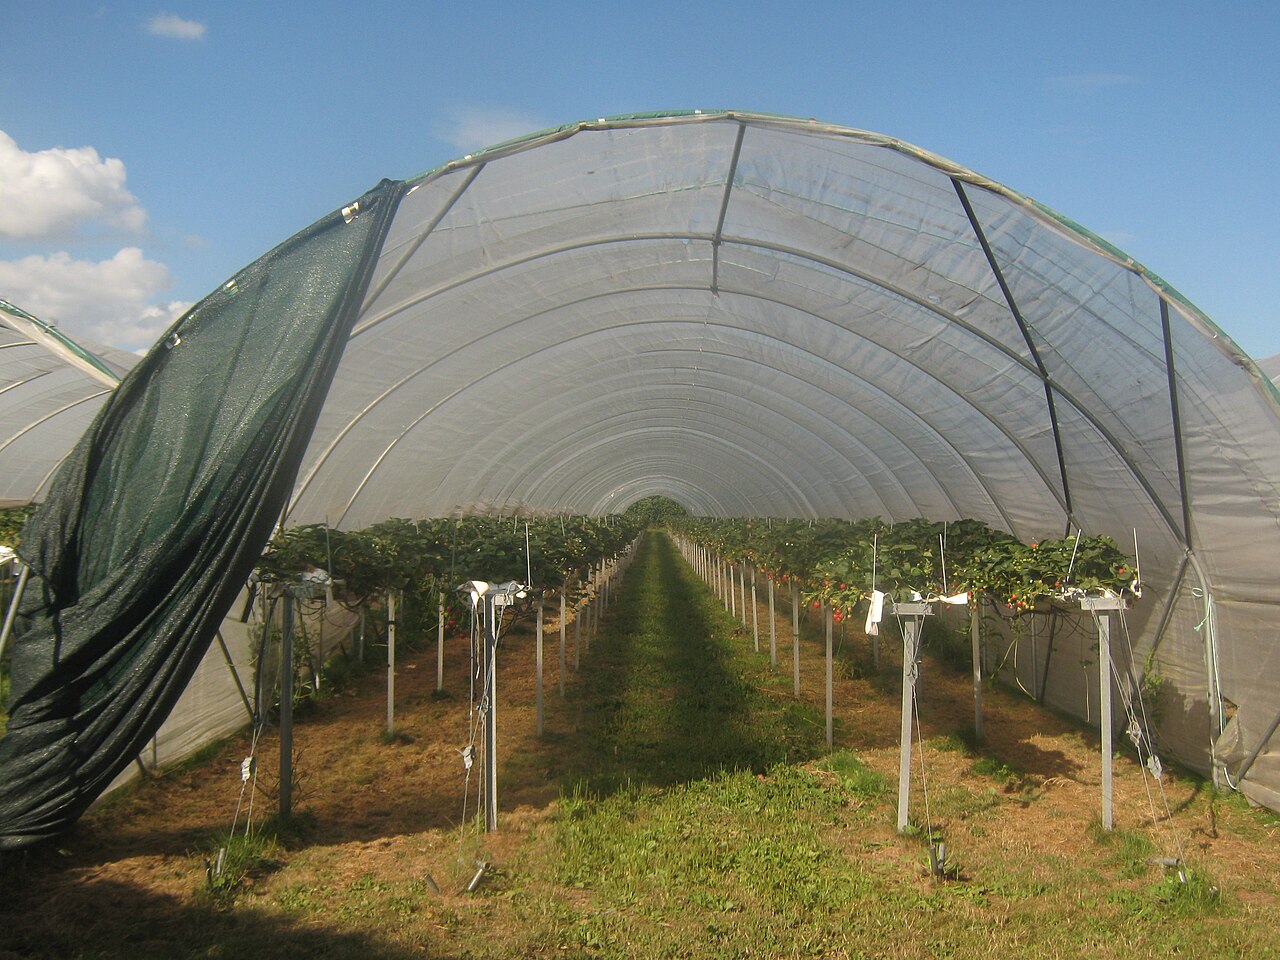
A research preprint combines tailored fruit vision with simulation-trained robot control, reporting 84.3% overall strawberry harvesting success in greenhouse evaluation and illustrating the remaining gap between reaching and completing a pick.
Source Bashir et al. — arXiv preprint
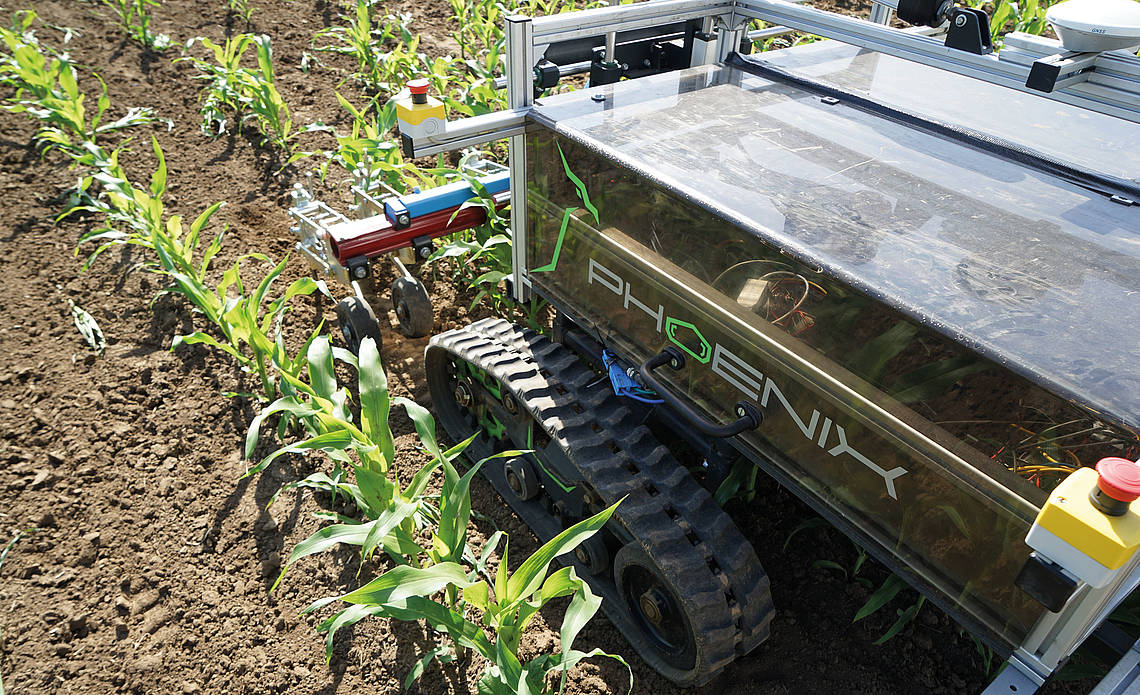
UCLA and North Dakota State researchers described AgriCruiser, an adjustable open-source robot chassis tested with precision spraying, offering a relatively accessible platform for field experiments and agricultural sensing.
Source Truong et al. — arXiv preprint
Agtonomy released its third software generation with expanded equipment support, vision-based navigation and connected setup, aiming to extend remote fleet management across specialty crops, turf and open-field operations.
Source Agtonomy