Researchers at Texas A&M and National Taiwan University presented a strawberry-harvesting system that pairs fruit segmentation with a controller trained in simulation. Their May 2026 preprint describes transferring the learned motion policy to a UR10e robot arm through ROS, creating a feedback loop between visual targets and physical movement.
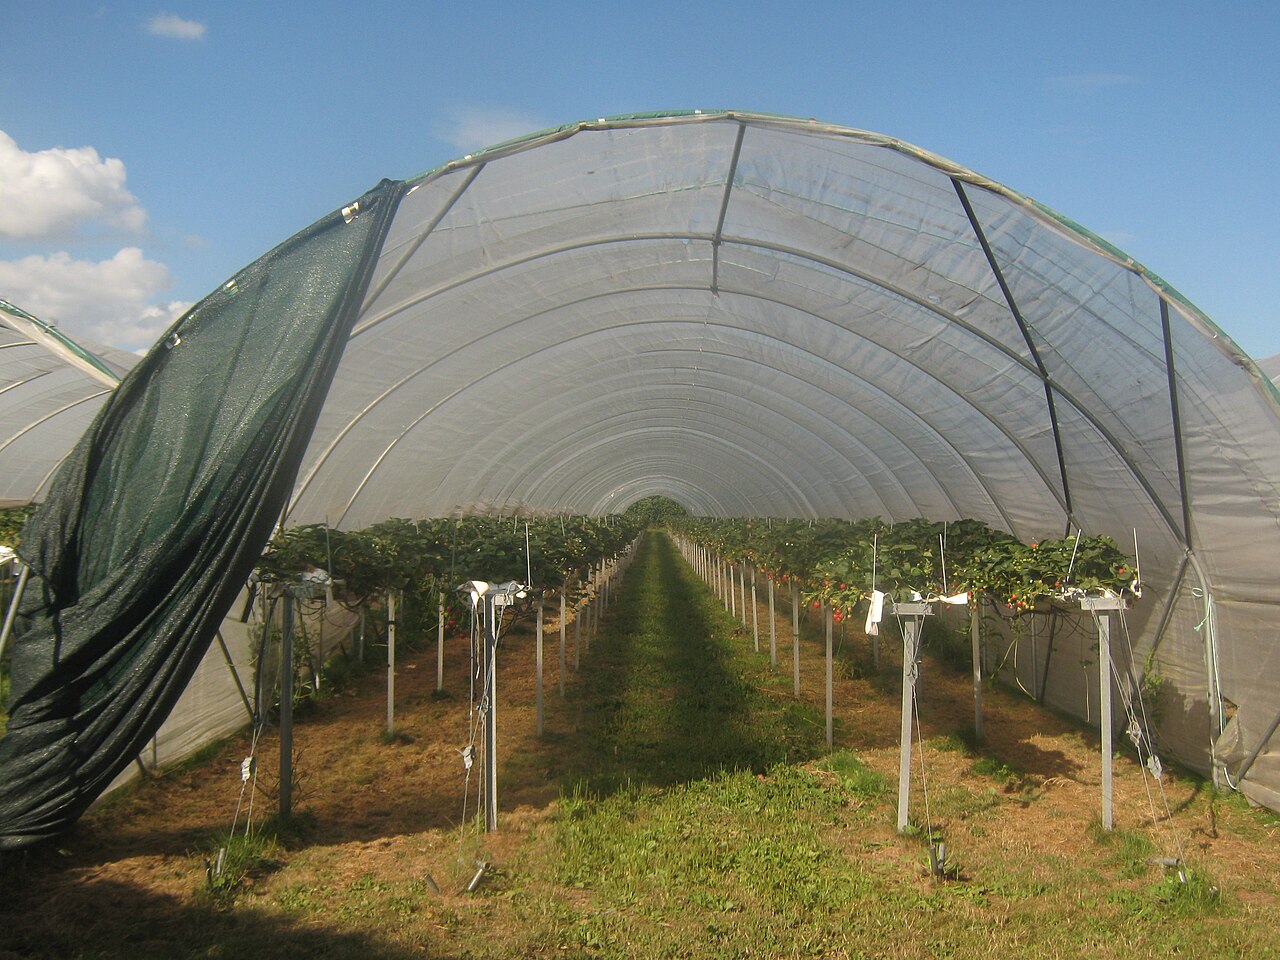
In greenhouse evaluation involving 281 strawberries, the authors report 96.6% reaching success, 91.3% success for grasping and pulling, and 84.3% overall harvesting success. The separate rates reveal losses beyond simply positioning the arm near a fruit. Controlled tests also compared motion with a conventional planning baseline. These are research results from the reported setup, not proof of commercial harvesting reliability. Broader assessment would need to include fruit damage, missed harvests, interventions and performance under different crop layouts.