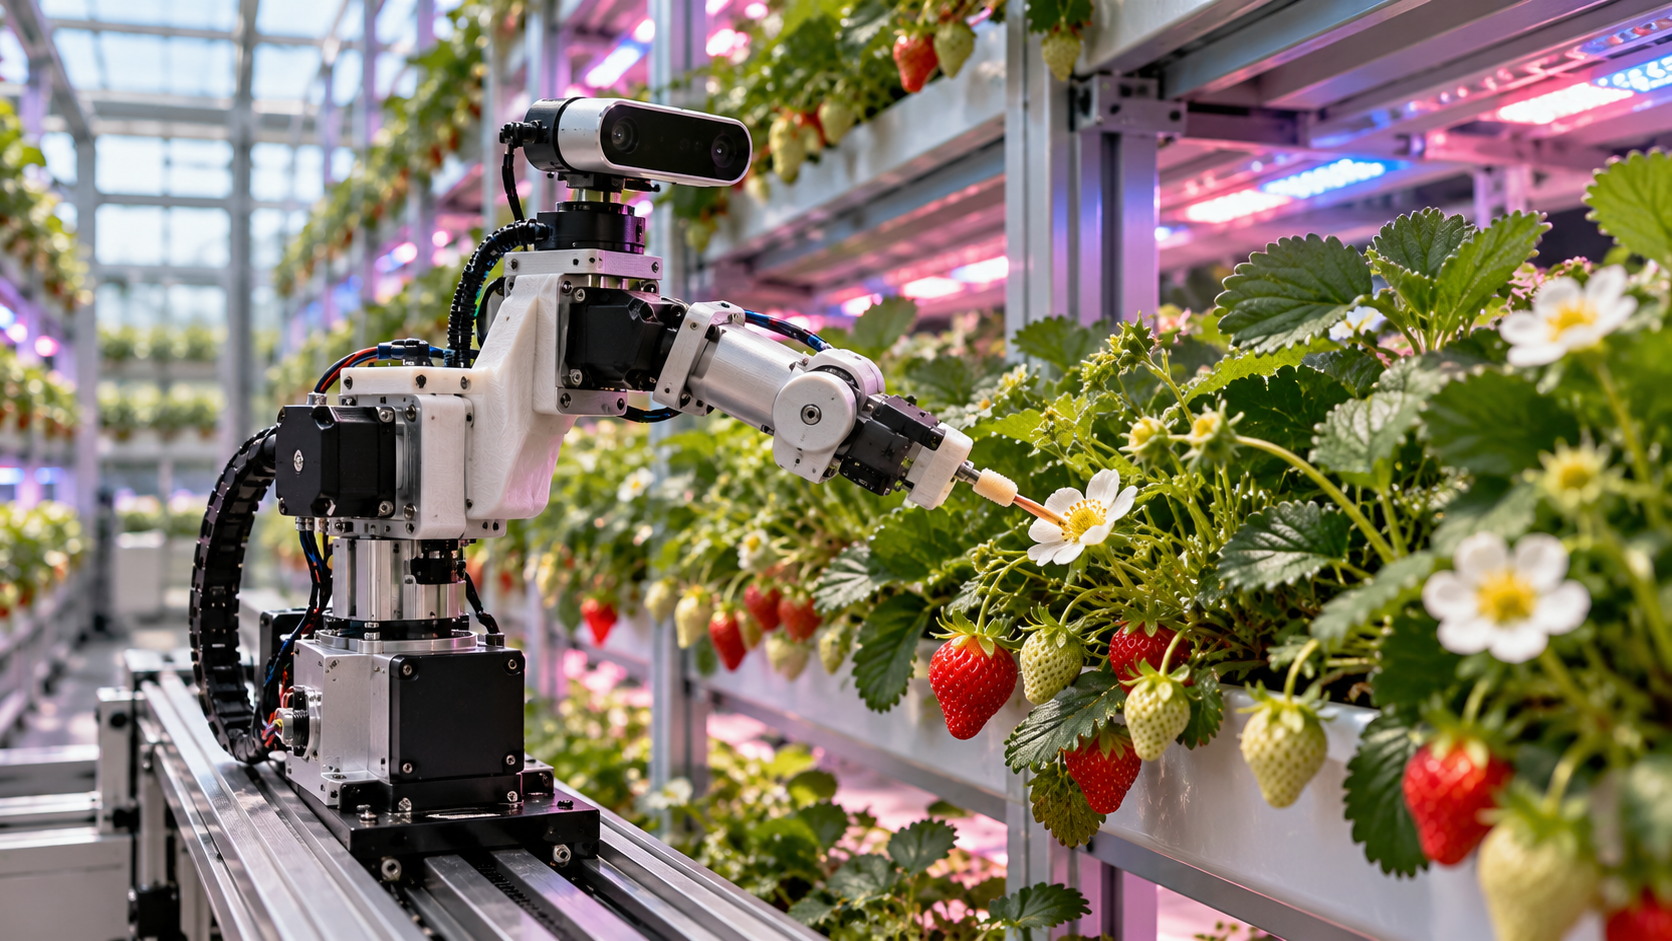
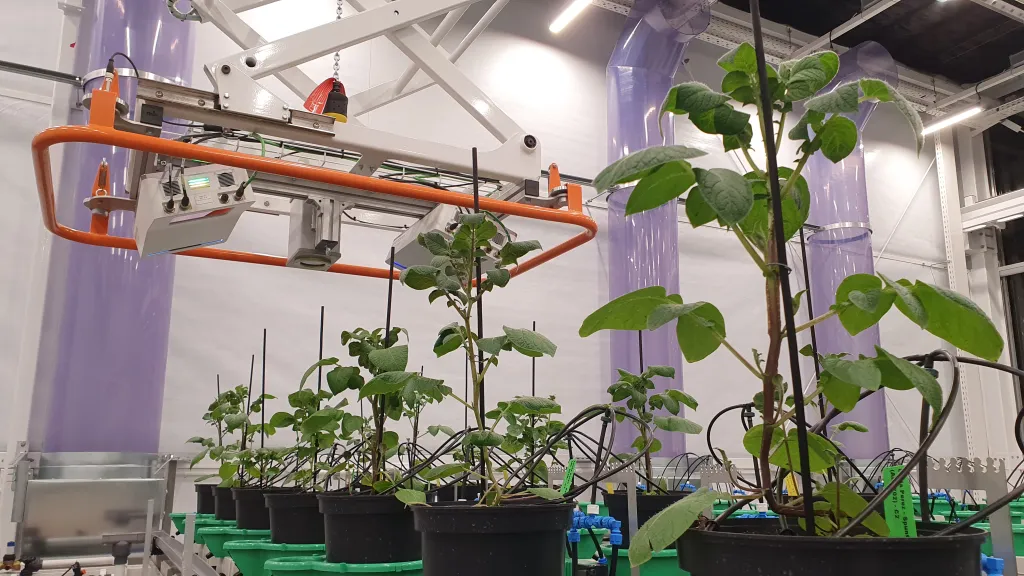
Wageningen University & Research highlighted a 2 September 2026 PhD defence on active robotic perception in agriculture. Jianchao Ci’s work addresses a persistent challenge in greenhouse automation: leaves, stems and changing plant arrangements often conceal the fruit or growth features that a robot needs to inspect.
Instead of taking a single static image, the approach lets a robot deliberately reposition its camera to obtain additional observations. The research studies online self-supervised learning so the robot can improve its selection of useful views through the data it gathers. Potential applications include harvesting, pruning and monitoring in crops where visibility changes throughout the day and growing cycle.
The university describes a research contribution, not a ready-to-purchase greenhouse product. Real-world robustness will depend on positioning accuracy, response time and the physical limits of reaching around foliage.