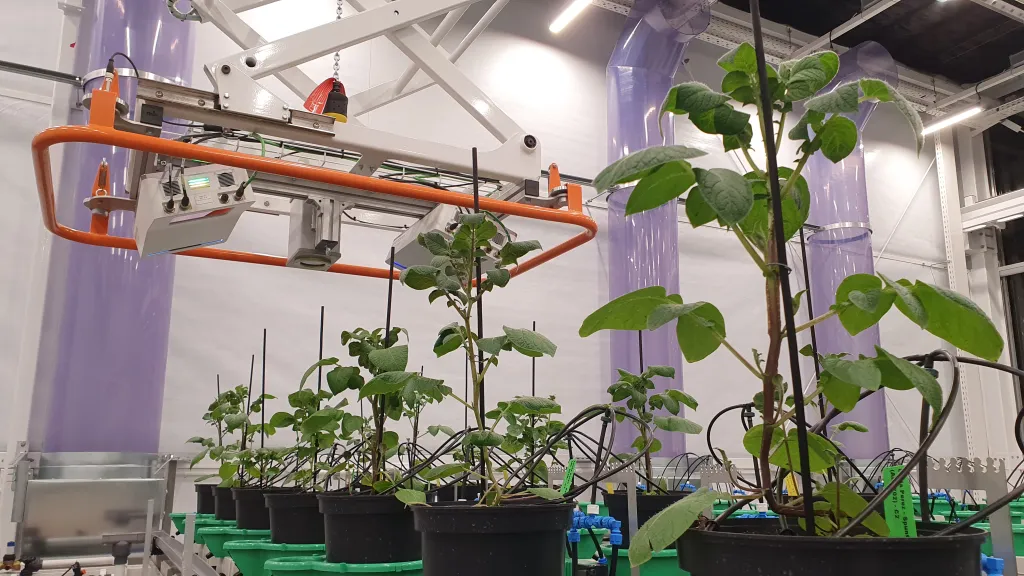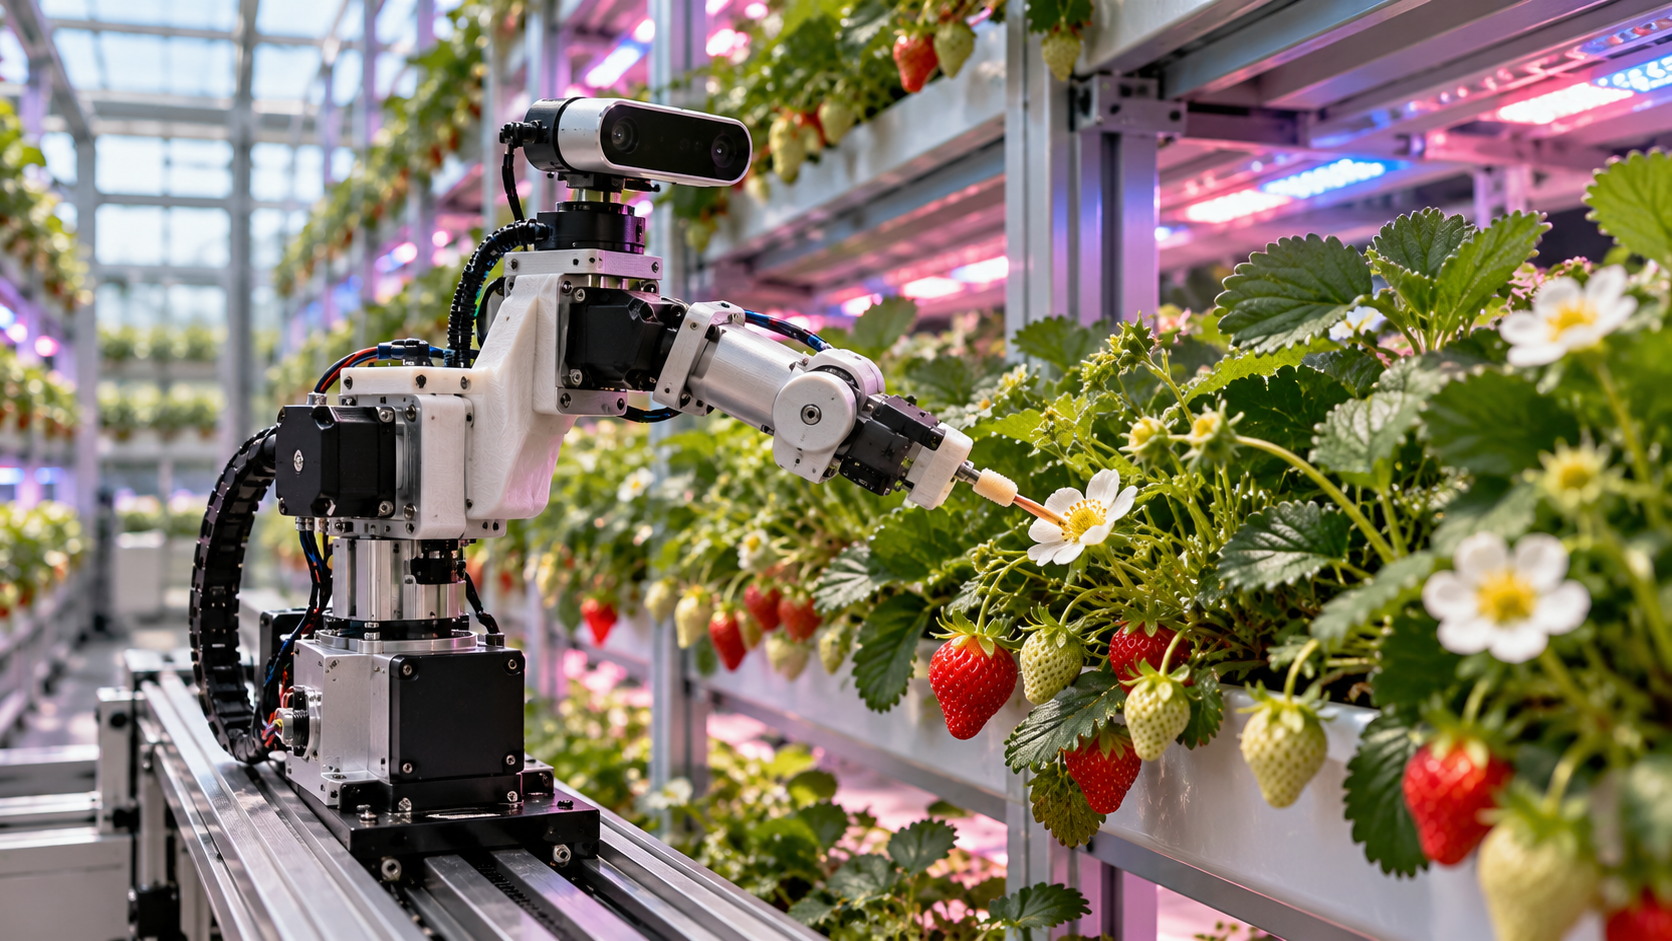
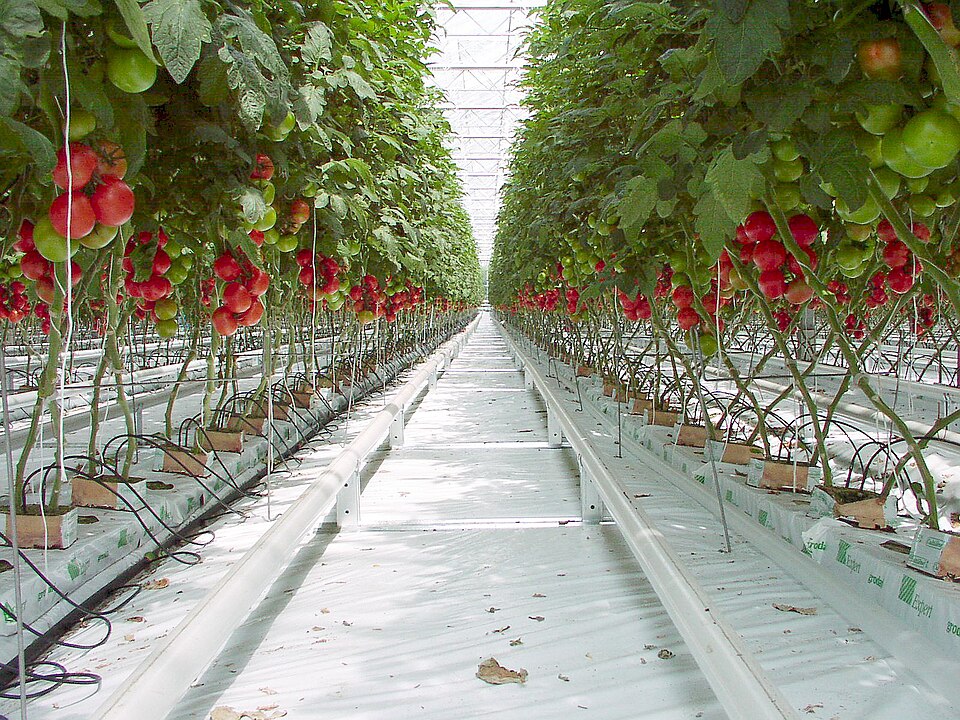
The University of Kentucky reported a new autonomous tomato-phenotyping effort on 17 July 2026. Principal investigator Biyun Xie and horticulture collaborator Qinglu Ying are combining robotics, computer vision and wireless power under NSF award 2437812.
The proposed system uses a mobile robotic arm to position cameras within the canopy, avoiding obstacles while gathering measurements of fruit and plant traits. Research objectives include deciding when additional images are needed and developing dynamic wireless charging for humid greenhouse conditions. The funding supports development and evaluation; continuous operation and broad commercial deployment are intended capabilities, not completed outcomes established by the announcement.