 Field roboticsFeatured
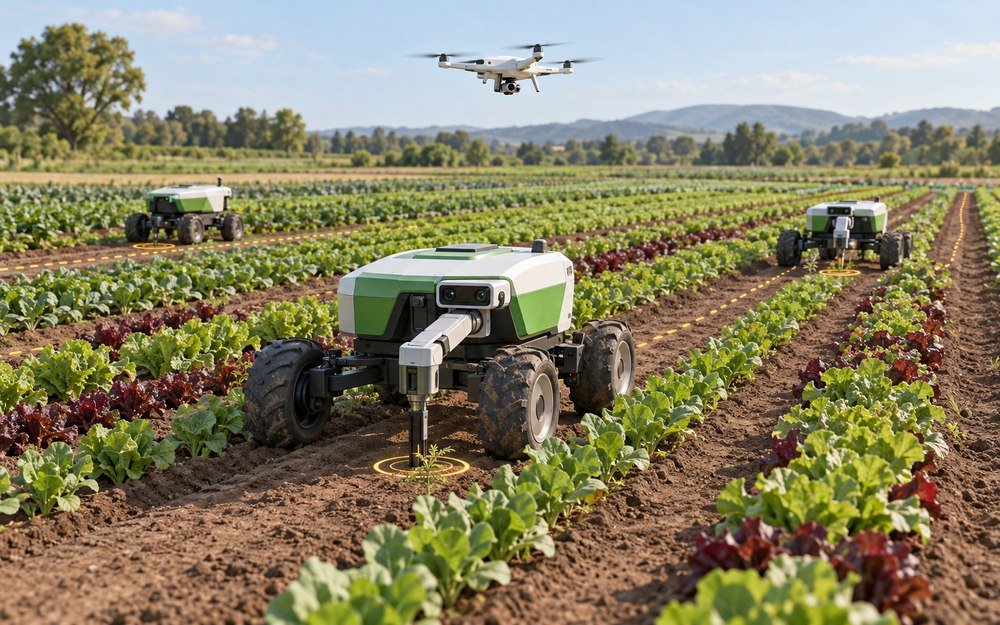
Illustrative preview
Scout & Act
Send a drone to scout crop rows, review its candidate targets, then dispatch a coordinated rover fleet for local verification and targeted action.
 DEMONSTRATION LAB
Explore interactive agricultural robotics, sensing and automation.
IN THE COLLECTIONScout & ActIllustrative preview ↗
Created by Maryam Behjati
From an engineering idea
to an interactive experience.
Launch a demo, watch it in action,
or explore its technical note.
32 demonstrations to explore
Interactive experiences · Video walkthroughs · Technical notesField roboticsFeaturedSend a drone to scout crop rows, review its candidate targets, then dispatch a coordinated rover fleet for local verification and targeted action.
 Field roboticsFeatured
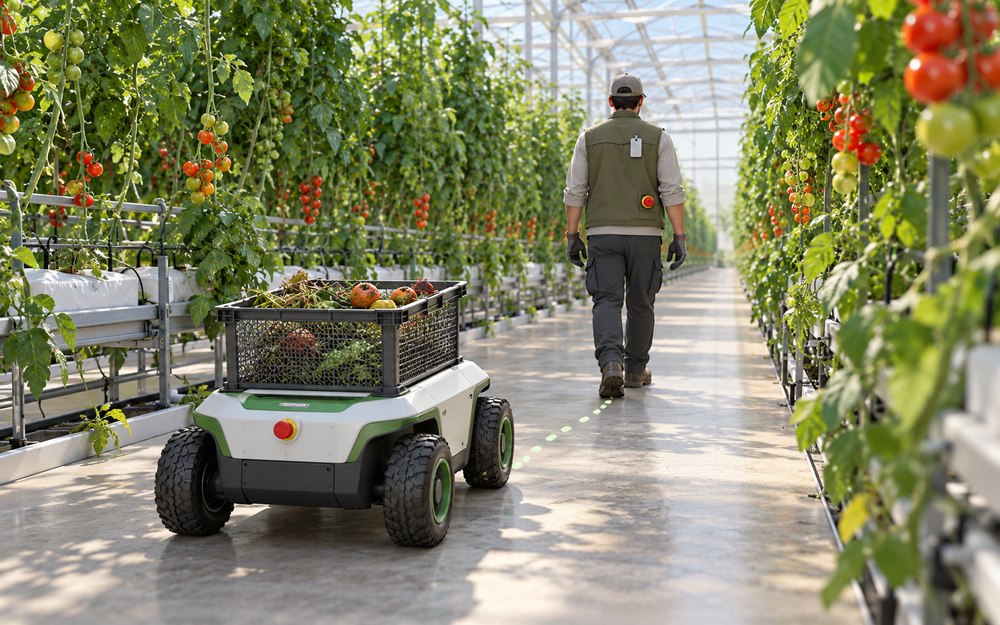
Explore a tagged worker and load-carrying robot in a greenhouse or pasture. Test following distance, an untagged visitor, signal loss, and both emergency stops.
 Sensing & automationFeatured
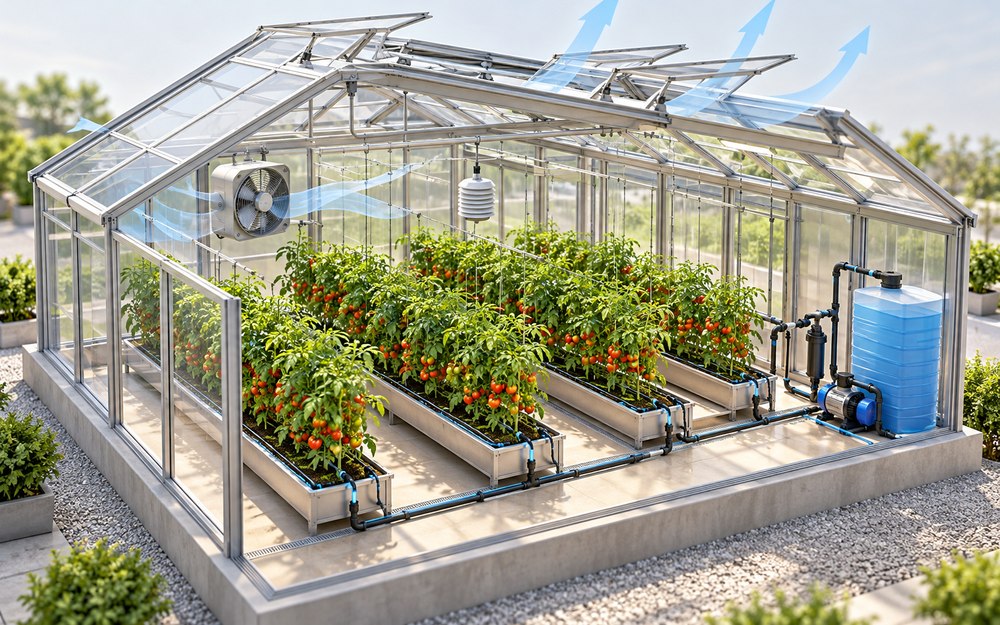
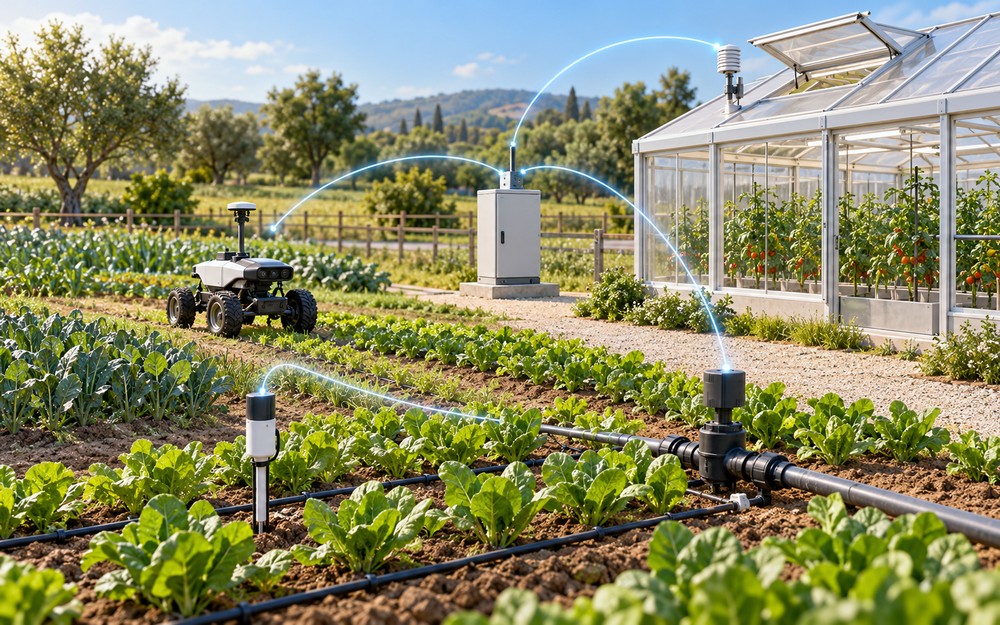
Explore an interactive greenhouse, adjust climate targets, challenge its control strategy, and inspect equipment, resource use, alarms, and imported sensor logs together.
 Harvest & manipulation
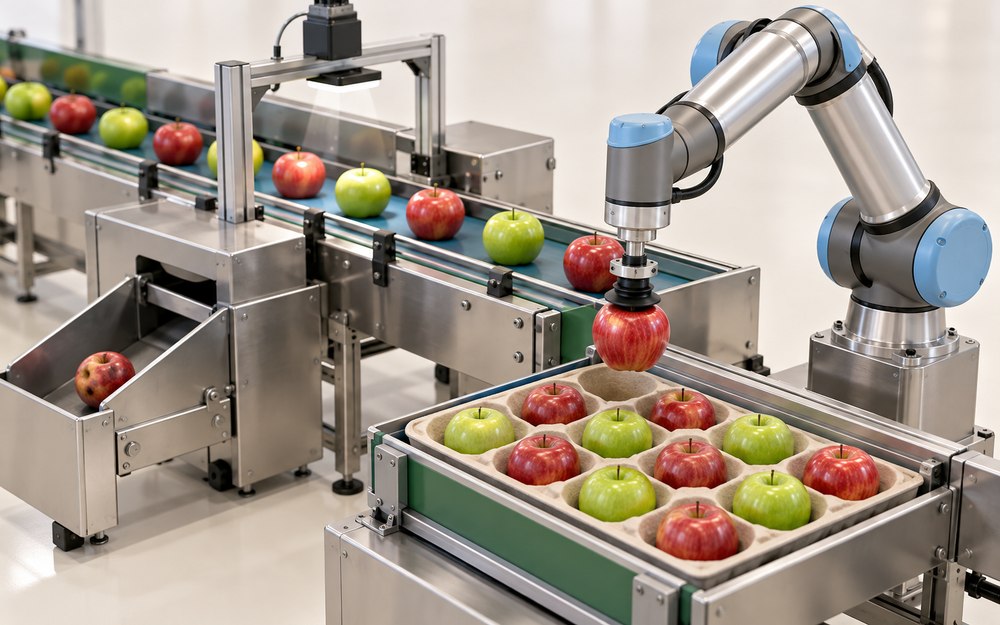
Follow apples from inspection to a packed tray. Change grading limits and conveyor speed to explore quality decisions, robot timing, and missed picks.
 Field robotics
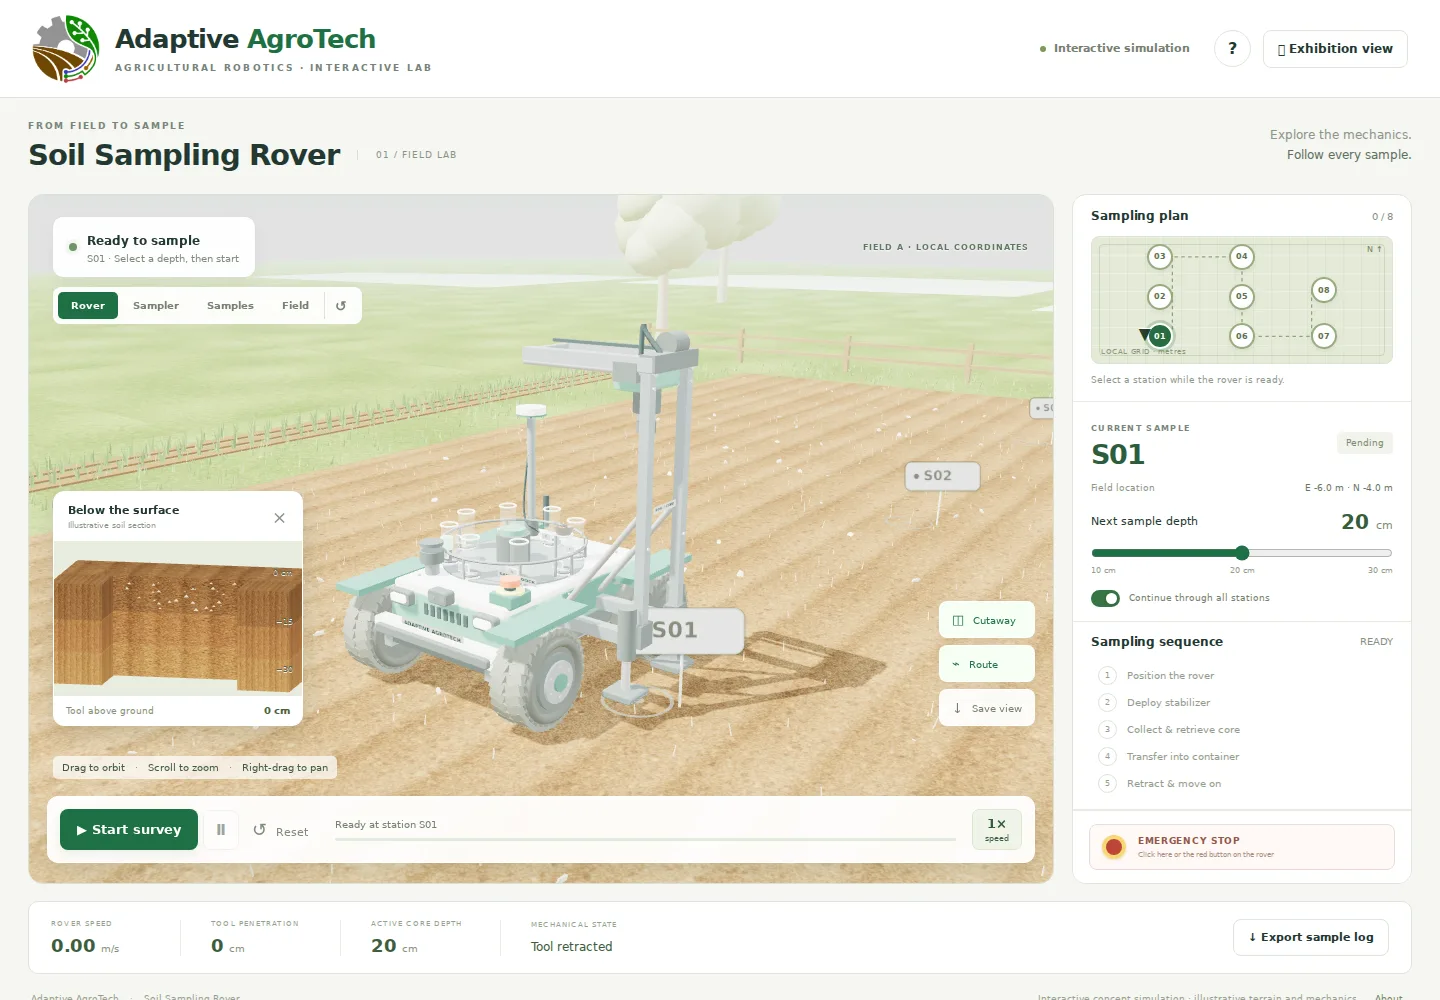
Follow a sampling mission from station selection and core collection to container transfer. Explore sampling depths, rover motion and sample records.
 Field robotics
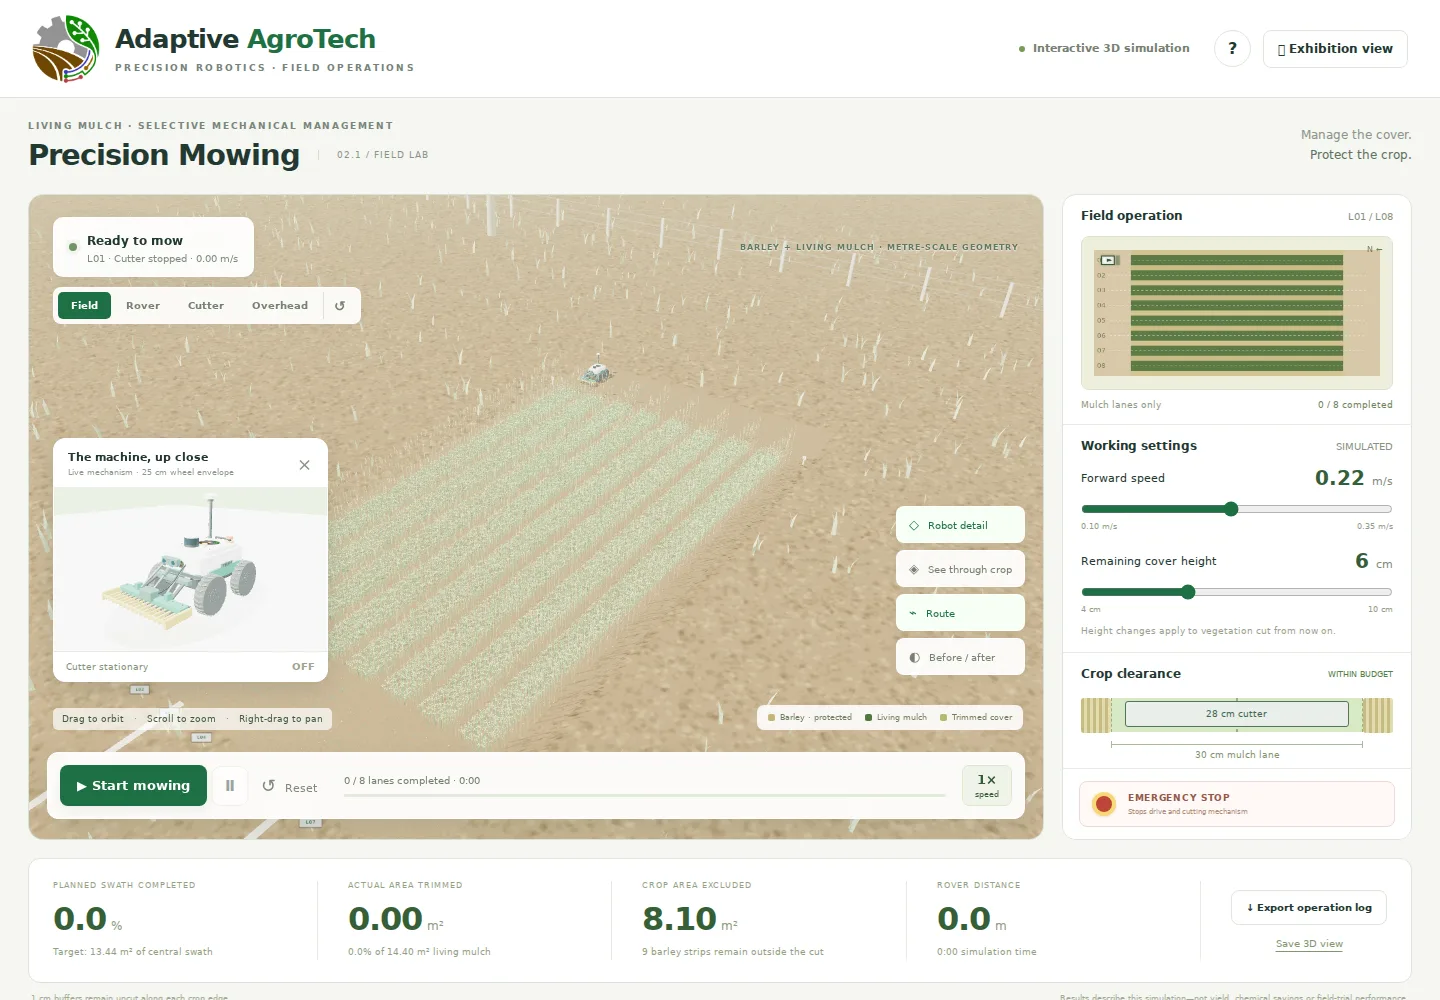
Manage living mulch between crop strips. Inspect the cutter, test obstacles and compare the field before and after selective mowing.
 Harvest & manipulation
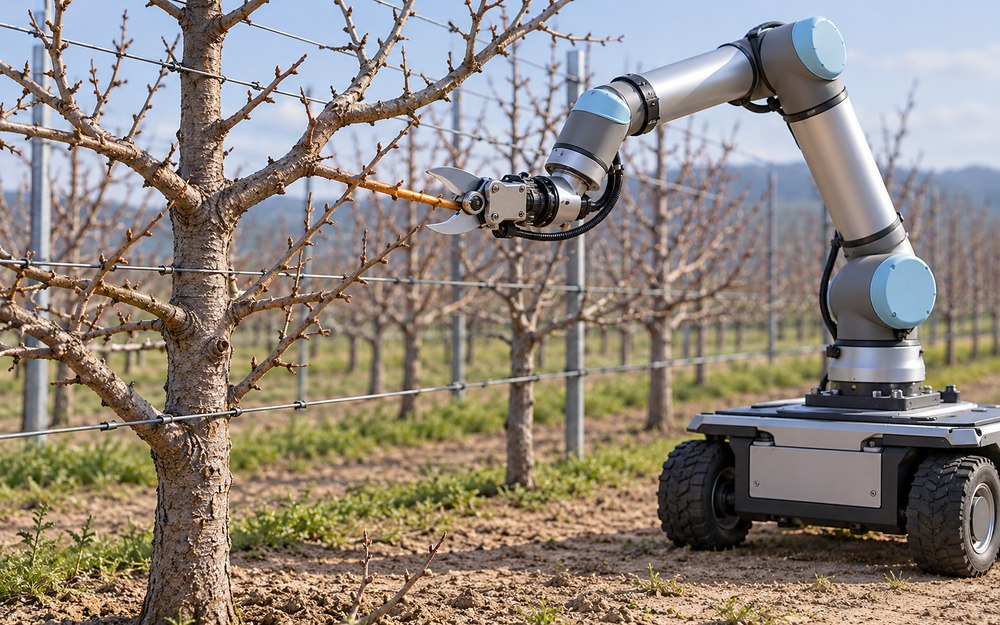
Inspect orchard branches, compare pruning strategies, preview a robot approach, and watch a UR10e execute selected cuts while retaining the main tree structure.
 Harvest & manipulation
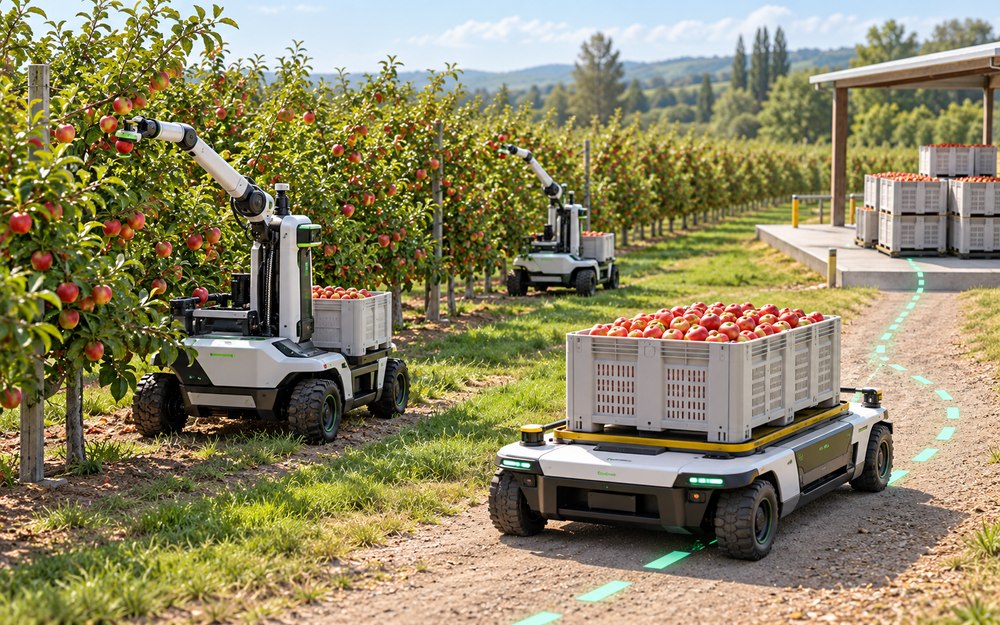
Coordinate harvesting and transport robots, test bottlenecks, and compare dispatch policies and fleet sizes.
 Field robotics
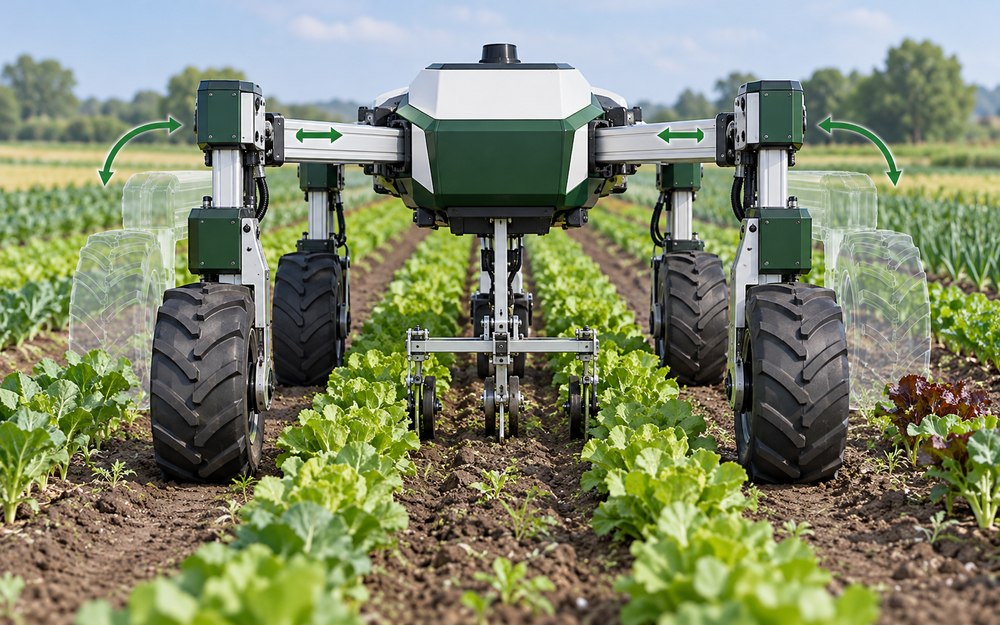
Change field spacing and terrain constraints to explore how an adaptable robot selects its geometry before a field pass.
 Field robotics
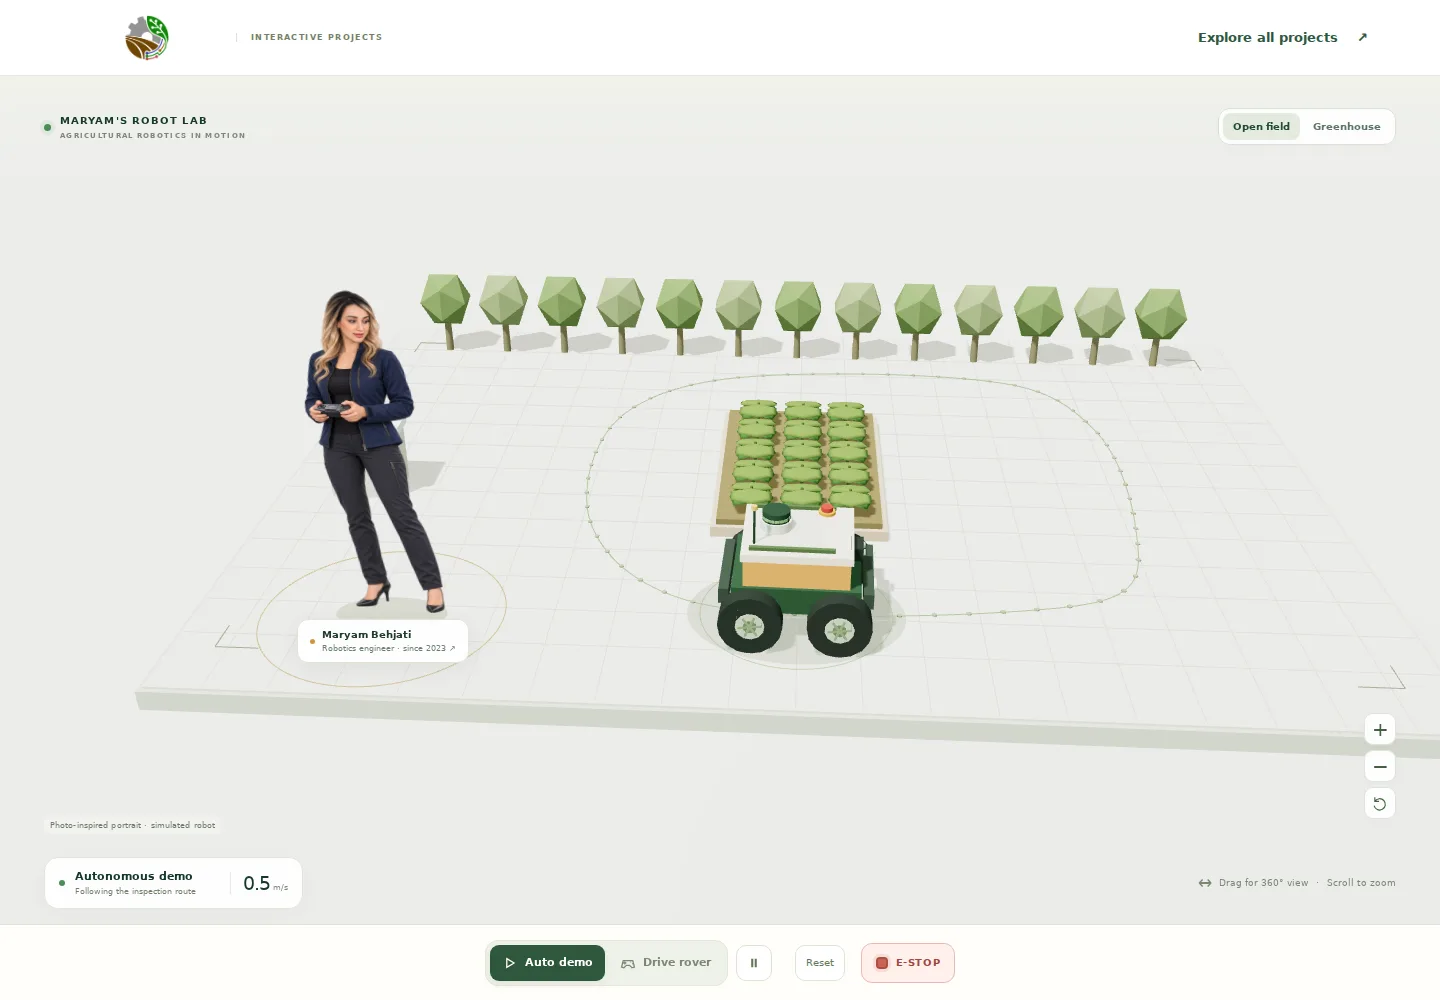
Drive a mobile robot in an open field or greenhouse. Rotate the scene, switch between autonomous and manual operation, and test the emergency stop.
 Design studio
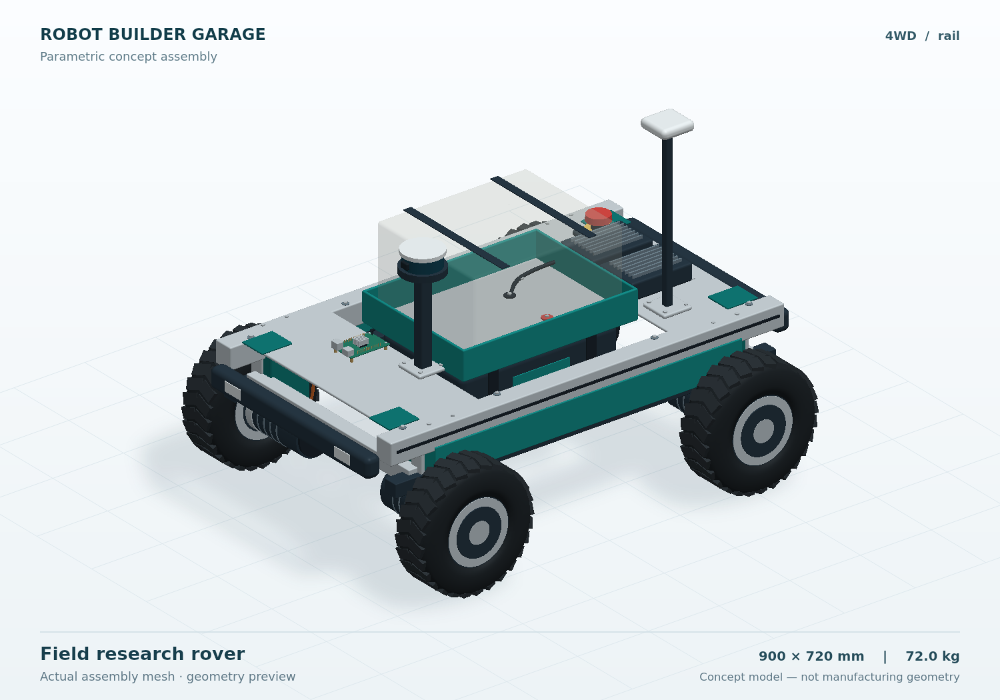
Configure a field robot’s chassis, drive, battery, sensors, and mission. Inspect the 3D design and engineering estimates, compare concepts, then run a kinematic drive test.
 Sensing & automation