Understand the machine.
Explore robot geometry, steering mechanisms and mechanical design through models that can be inspected and changed.
Making agricultural robotics
visible, tangible and interactive.
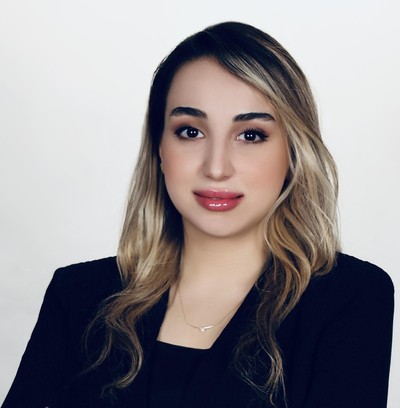
Maryam Behjati is a mechanical engineer with B.Sc. and M.Sc. degrees from the University of Tehran. Since 2023, she has worked as a Robotics Engineer at Adaptive AgroTech, focusing on the evaluation of agricultural mobile robots, 3D modelling and dynamic simulation.
Her work spans sensing, control algorithms, communication protocols and actuation. She is particularly interested in affordable, small-scale robotic platforms that can navigate unstructured orchards and provide farmers with information about plants and soil.
At Adaptive AgroTech, Maryam models and simulates different steering mechanisms and robot chassis. She evaluates their ease of control, reliability and manoeuvrability to develop recommendations for platforms working on uneven terrain, with modular and swappable sensors.
Her simulations also examine the effects of bushes and occlusions. This helps her investigate suitable positions for NDVI and multispectral cameras, connecting mechanical design with the quality of information a robot can collect.
Meet Maryam’s photo-inspired avatar in a virtual testbed. Drive the mobile robot, change the setting, and try the stop controls.
Explore robot geometry, steering mechanisms and mechanical design through models that can be inspected and changed.
Connect a control decision to an observable movement, path or response. Use simulation to investigate a concept before physical testing.
Bring the engineering back to agricultural work: crop care, harvesting, sensing and collaboration between people and robots.