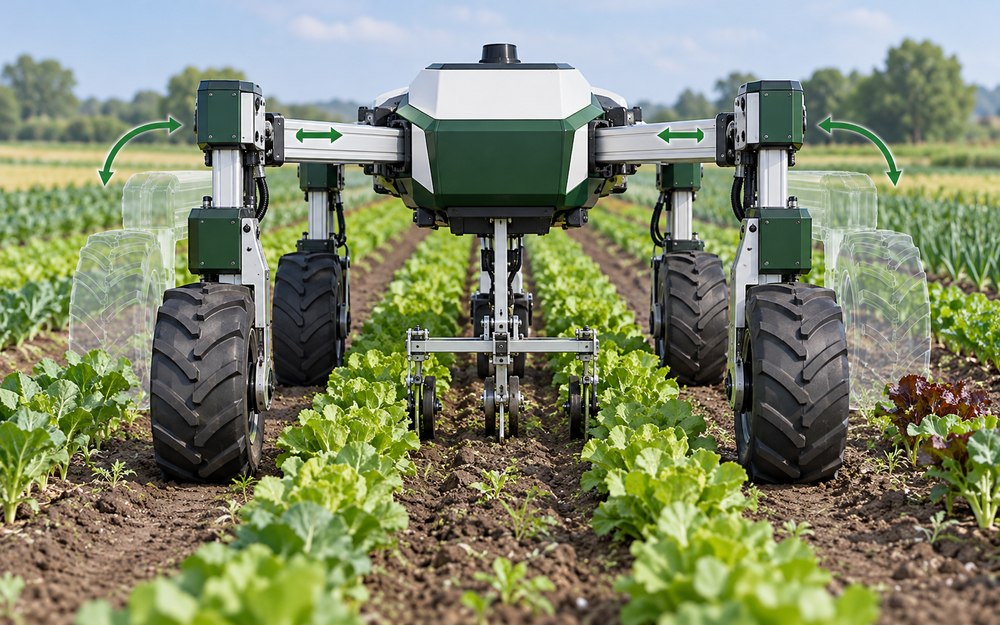
 Illustrative preview
Field robotics
MORPH · Self-configuring Robots
Change field spacing and terrain constraints to explore how an adaptable robot selects its geometry before a field pass.
The interactive demo opens in a new tab. Explore its controls and assumptions directly.
Video walkthrough
If the embedded player is unavailable, open the video directly.
Open video ↗