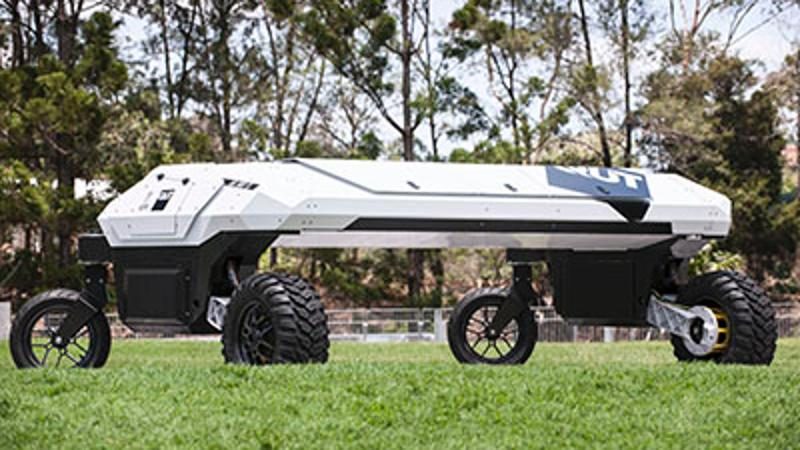
QUT’s 21 October 2016 report described the first public demonstration of AgBot II to farmers in Bundaberg the previous day. Professor Tristan Perez explained that the robot combined sensors, software and electronics to navigate, detect weed species and support mechanical or chemical treatment. Queensland Government funding supported the development.
The researchers reported 99% classification accuracy for images of three target weed groups: volunteer cotton, sow thistle and wild oats. That figure applies to the stated image-classification task and should not be read as a complete field weed-control success rate. The roughly 600-kilogram platform was also discussed as a way to reduce the effects of heavier machinery on soil. This historical demonstration illustrates an early design direction, rather than a claim about a currently supported commercial product.