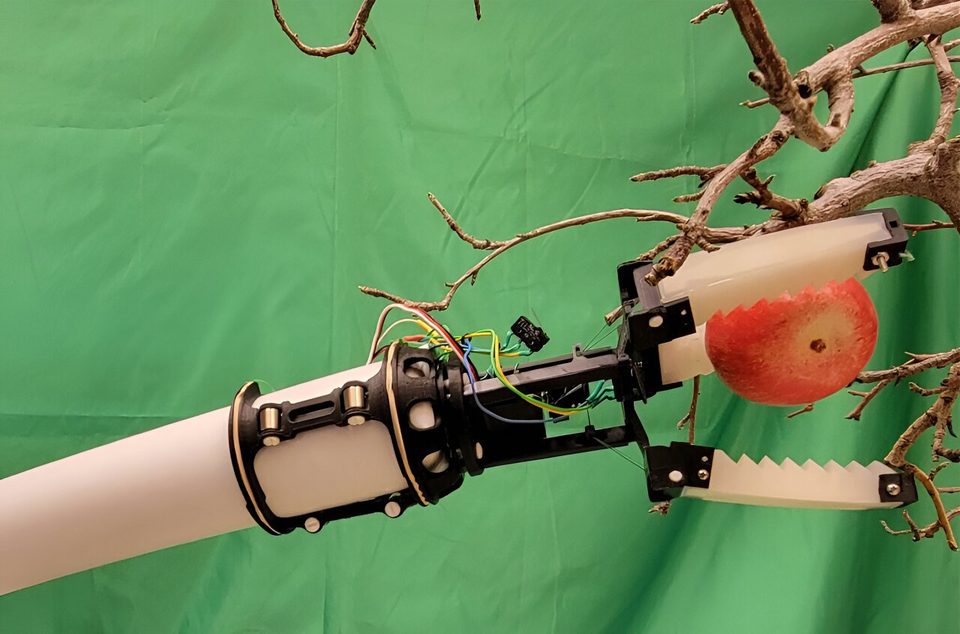
Washington State University researchers developed a gripper intended to remove apples without damaging the fruit. The June 2024 university report describes work by doctoral researcher Chris Ninatanta and colleagues, published in the proceedings of the IEEE International Conference on Soft Robotics.
Ninatanta drew on observations of his parents picking fruit to inform the mechanism. The team’s next steps included combining the lightweight gripper with a soft, air-filled robotic arm and adding an onboard camera for guidance. A twisting action was also planned to better reproduce human handling of the stem. These were component-development and integration plans, with further laboratory and farm tests ahead; the report did not establish a complete commercial harvesting system.