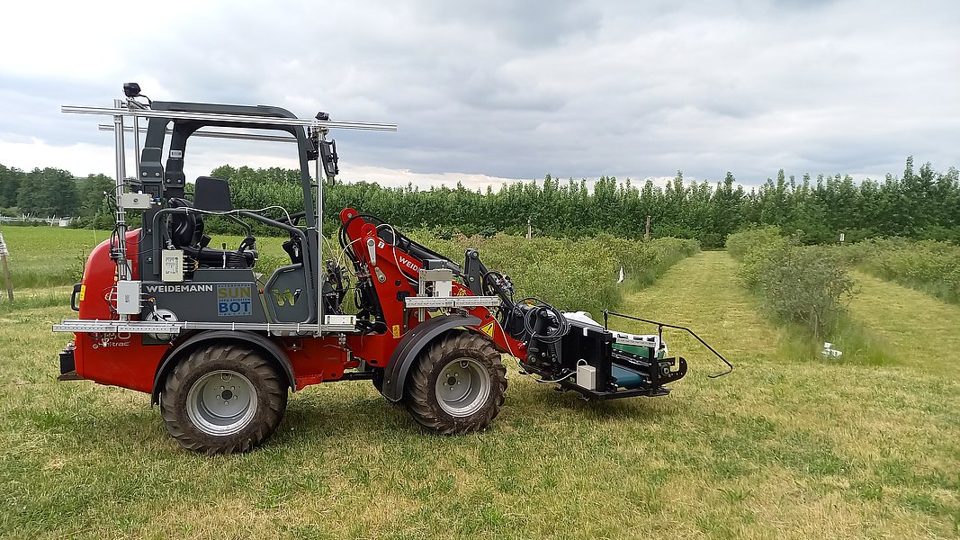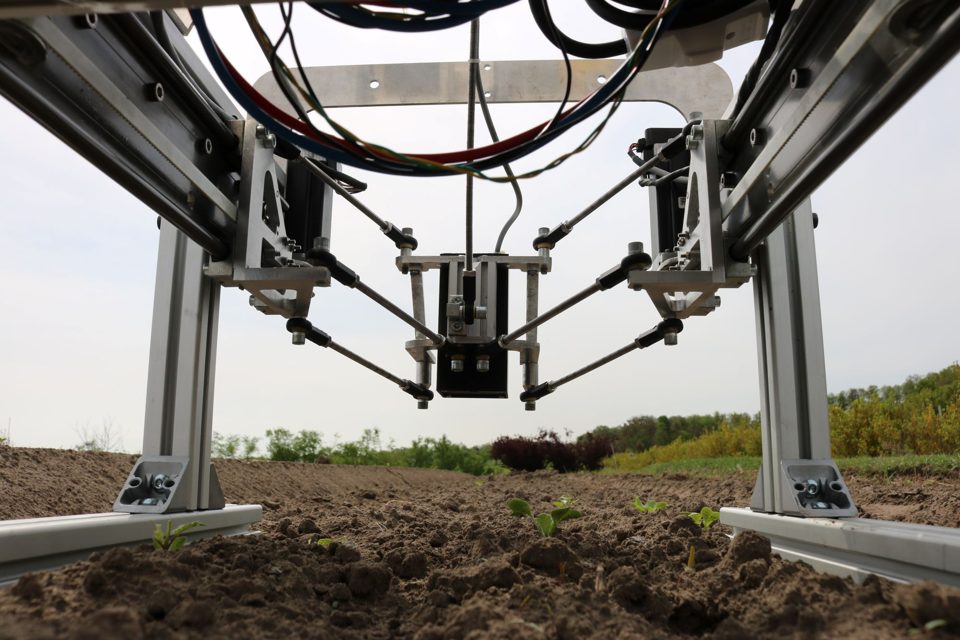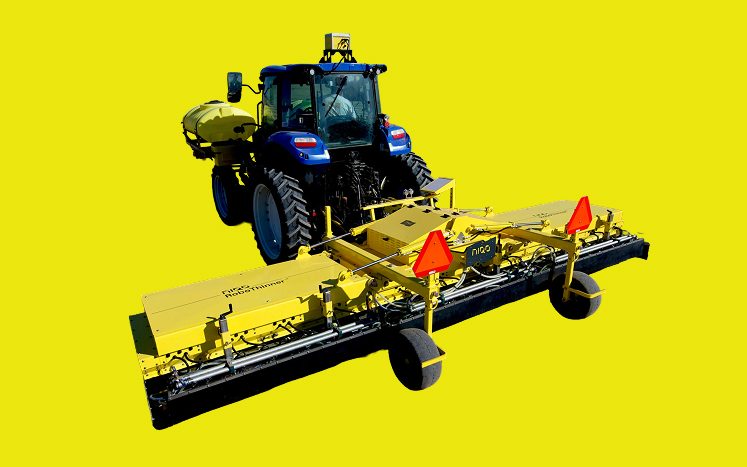
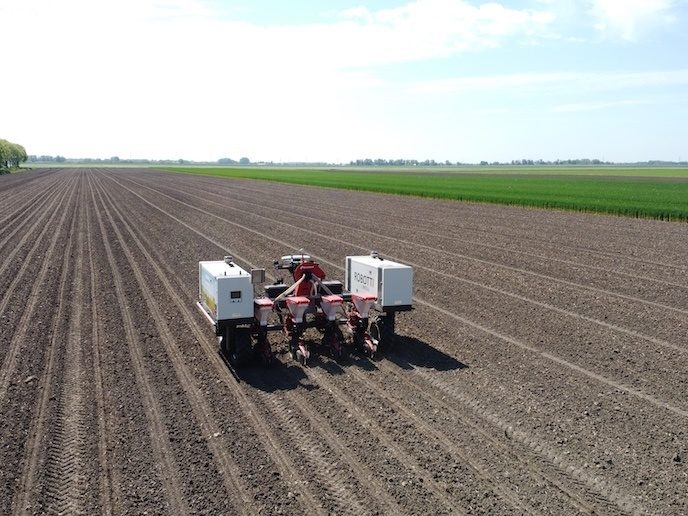
In a results brief last updated on 8 May 2025, CORDIS described how the Wageningen-led Robs4Crops project developed autonomous weeding and spraying around existing agricultural equipment and practices. Its architecture joined smart implements, mobile platforms and software that scheduled work and responded to unexpected situations.
An important element was feedback from the operation itself: the project reported that inadequate weeding could trigger an adjustment by the robot. LiDAR also supplemented satellite positioning where orchard or vineyard conditions weakened GNSS reception. Four large-scale pilots explored deployment and adoption, including grower and cooperative involvement. These were project-reported results from a programme that ended in December 2024; the account should not be read as a guarantee that every configuration was commercially available or proven under all farm conditions.