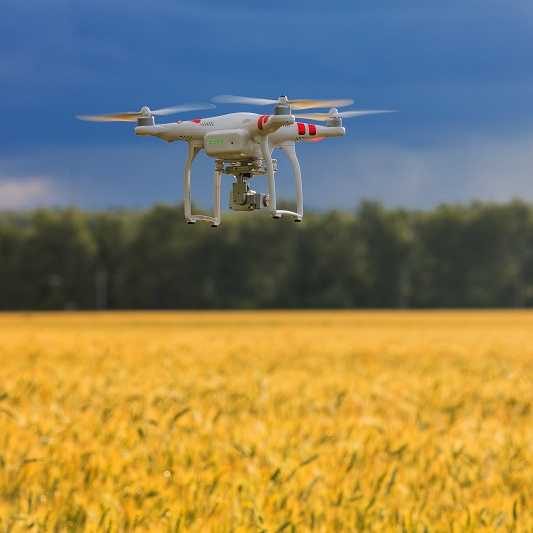
In a results brief last updated on 22 May 2018, CORDIS described the Flourish project’s cooperative aerial and ground robotics system for precision farming. The ETH Zurich-coordinated work combined a small multicopter with a multipurpose ground vehicle to connect broad field observation and targeted intervention.
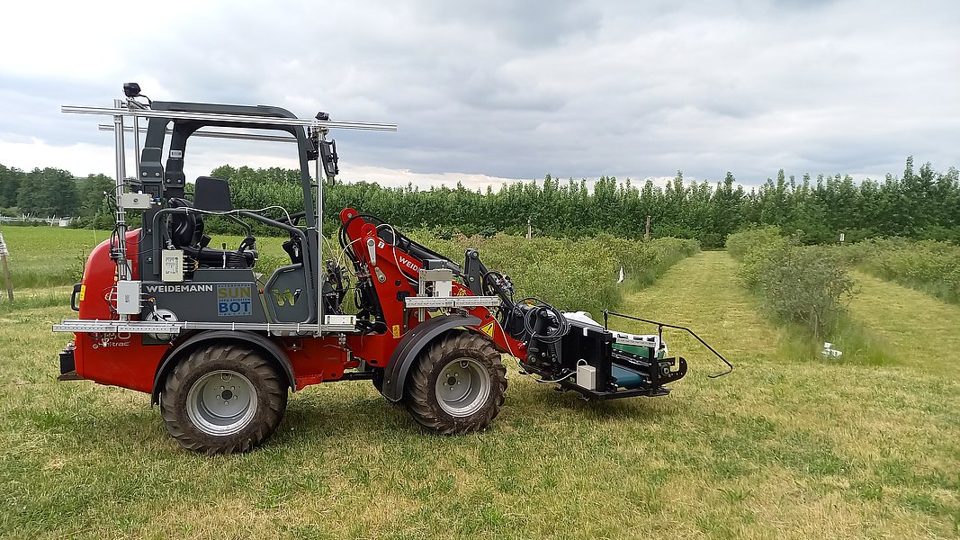
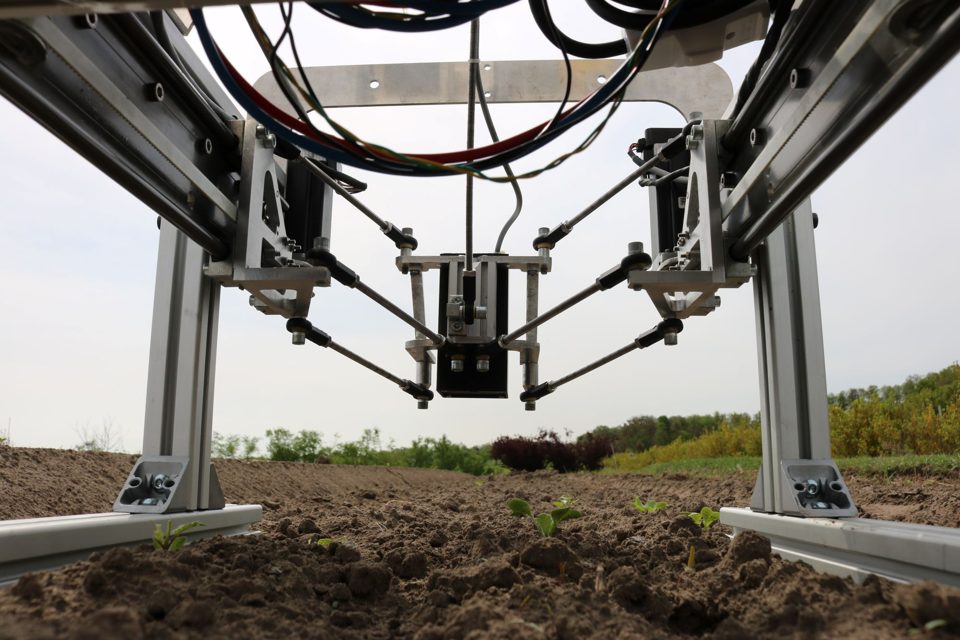
The drone collected crop information and identified areas needing attention. The Bonirob ground prototype then used that information to navigate to selected locations, where it could support localized spraying or mechanical weed removal. Image analysis helped distinguish crops from unwanted plants. At the time of the report, the partners were still refining robustness, setup procedures and alignment with users’ requirements. This historical development illustrates an early integrated sensing-to-action architecture; it should not be interpreted as a current commercial offer or a universal solution for every crop layout.