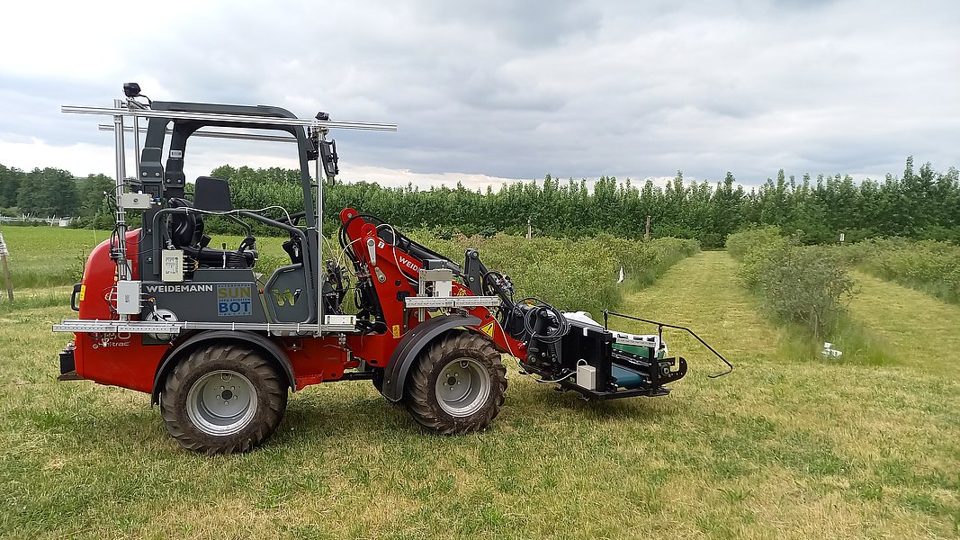
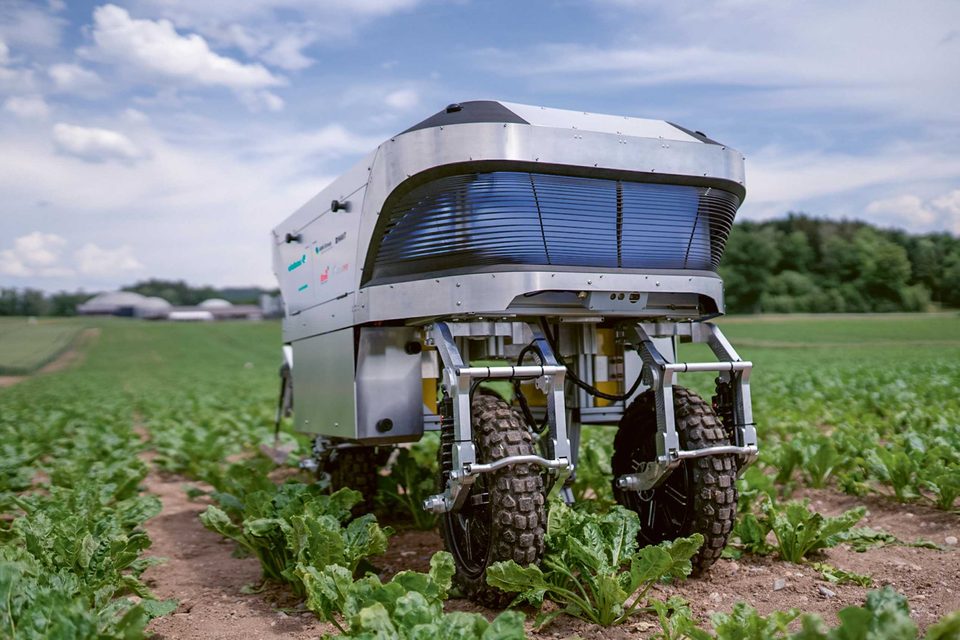
ETH Zurich’s Robotic Systems Lab reported recognition for a paper on global path planning in orchards and vineyards at the 2024 International Workshop on Robot Motion and Control in Poznań. Timo Schönegg presented work co-authored with Turcan Tuna, Fan Yang, Gabriel Waibel, Matias Mattamala and Marco Hutter.
The research emerged from Lonomy, which investigates autonomy for vehicles in agricultural environments with complex layouts. ETH links the effort to the earlier Rowesys weeding-robot project. The July 2024 announcement documents a research contribution and conference award, rather than a commercial release or proof that orchard navigation is solved. Its agricultural relevance is the challenge of turning spatial information into routes that a real vehicle can actually follow.