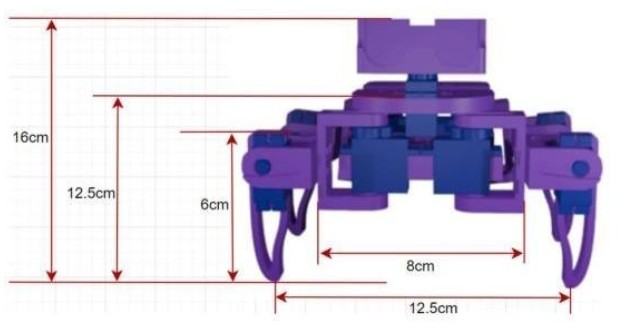
A study from Universidad Distrital Francisco José de Caldas in Colombia describes a small quadruped built to investigate movement on difficult ground. The structure was produced using 3D printing and accommodates eight servomotors, while a Raspberry Pi Pico W runs the control software in MicroPython.
An HTML interface allows an operator to control the robot from a computer or mobile phone. The authors report promising off-road manoeuvrability and position the design as a step towards agricultural legged robots. This is a remotely controlled research prototype, not an autonomous crop-management machine. Its value lies in making the mechanical and control problem accessible for experimentation before adding more demanding sensing, navigation and agricultural tasks.