 Sensing & automation
EXPLORE. INTERACT. UNDERSTAND.
The demonstration collection
Launch a demo, watch it in action,
or explore its technical note.
33 demonstrations to explore
Clear filters ×Sensing & automation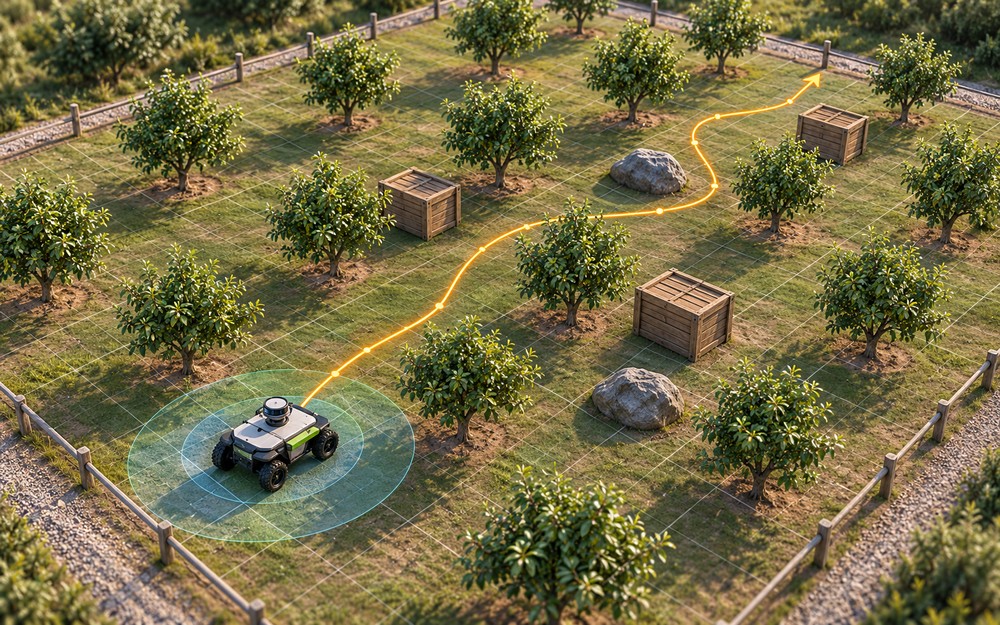 Navigation & control
Illustrative preview
Autonomous Navigation Lab
Add obstacles, move the goal and explore how an A* route changes with the robot footprint and clearance margin.
 Field robotics
Illustrative preview
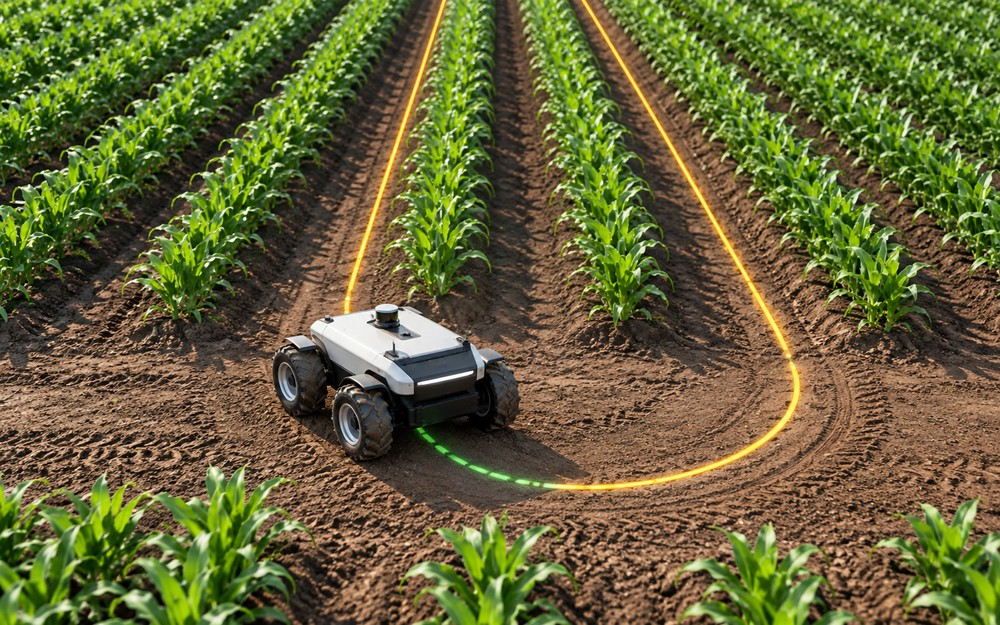
FieldPilot · Row Mission Lab
Plan row missions, check headland fit, and watch differential-drive wheel commands create a tracked trajectory.
 Field robotics
Illustrative preview
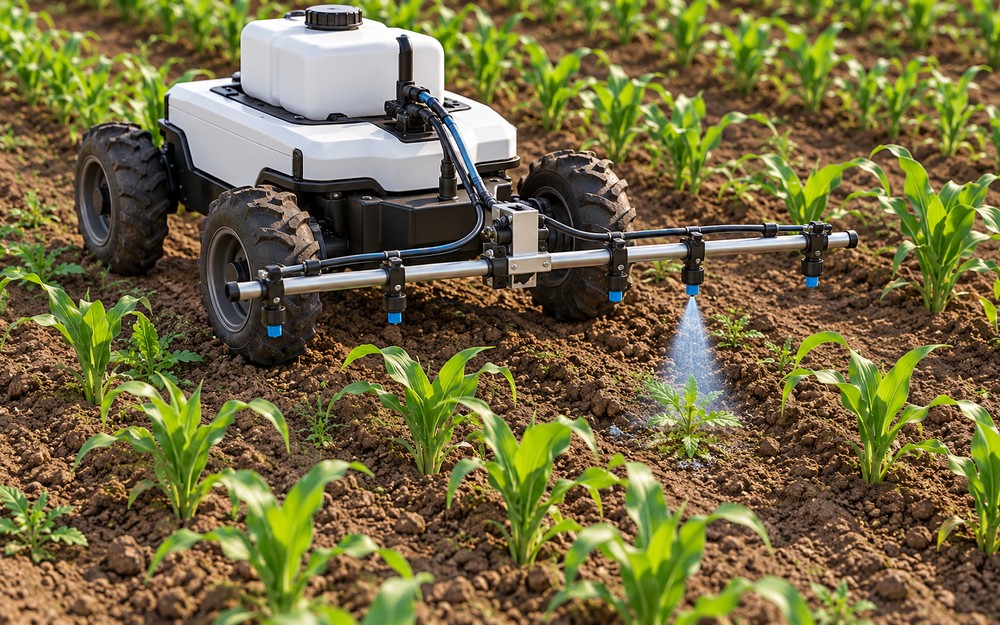
Precision Weeding Lab
Run a five-valve spot-spraying mission and compare modelled liquid use with continuous band spraying.
 Harvest & manipulation
Illustrative preview
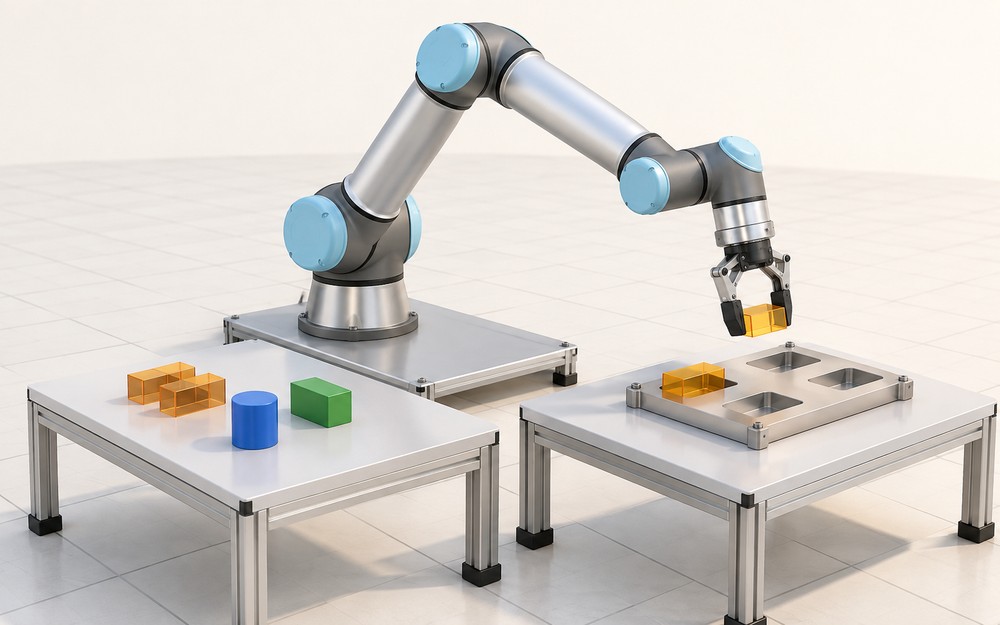
Manipulator Studio · UR10e
Plan a pick-and-place task with a six-axis UR10e model and inspect the joints, tool pose and transfer path.
 Harvest & manipulation
Illustrative preview
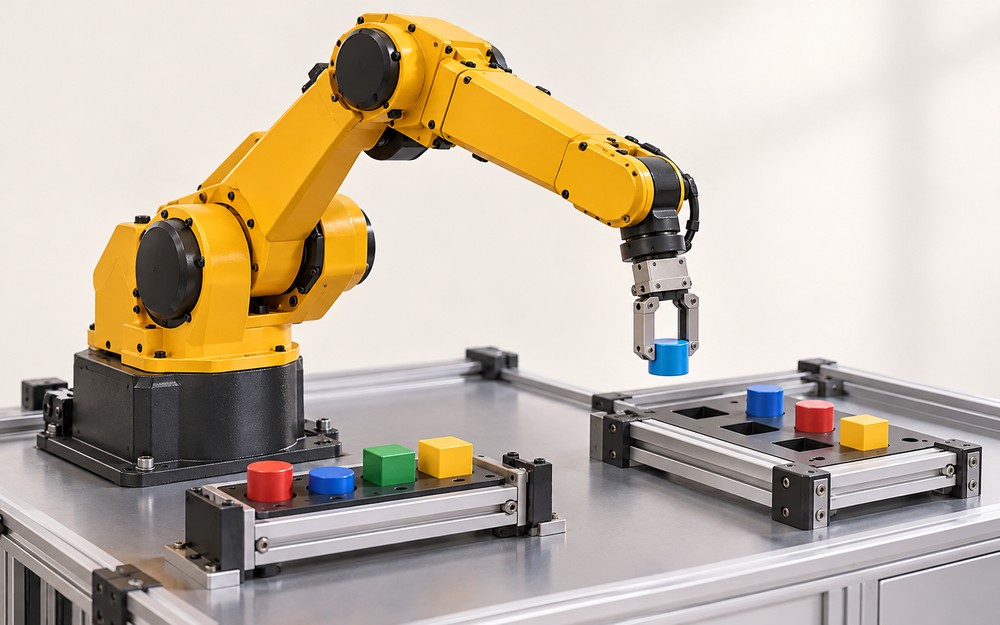
Manipulator Studio · FANUC
Explore compact industrial pick-and-place with a FANUC LR Mate 200iD model and six-axis pose control.
 Design studio
Illustrative preview
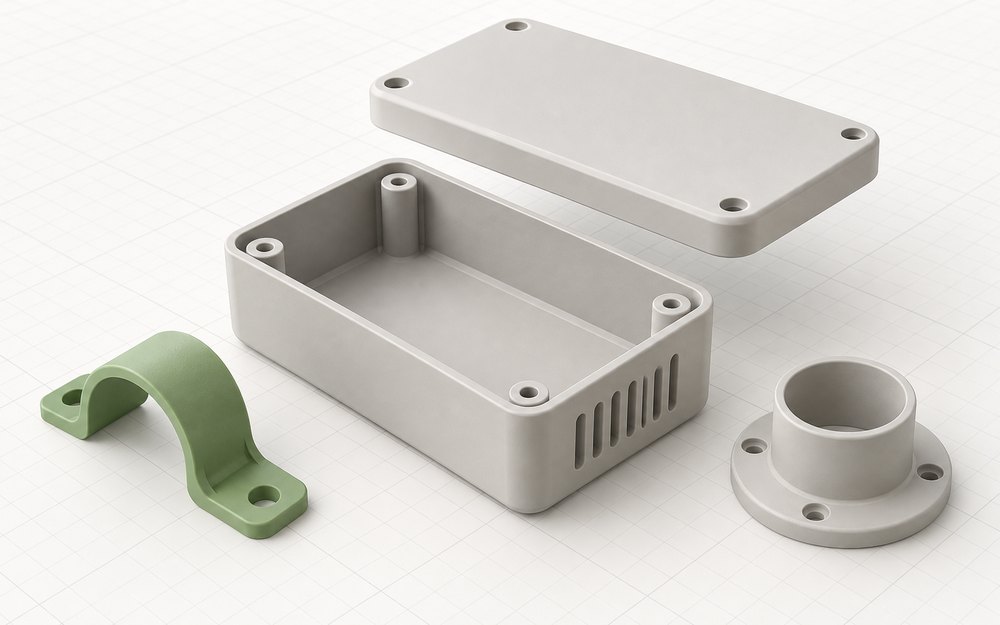
Part Studio Pro
Customize sensor enclosures and mechanical parts with parametric shapes, outline editing, mounting bosses, vents, holes, and slots. Inspect the model and export STL or OBJ.
 Navigation & control
Demo screenshot
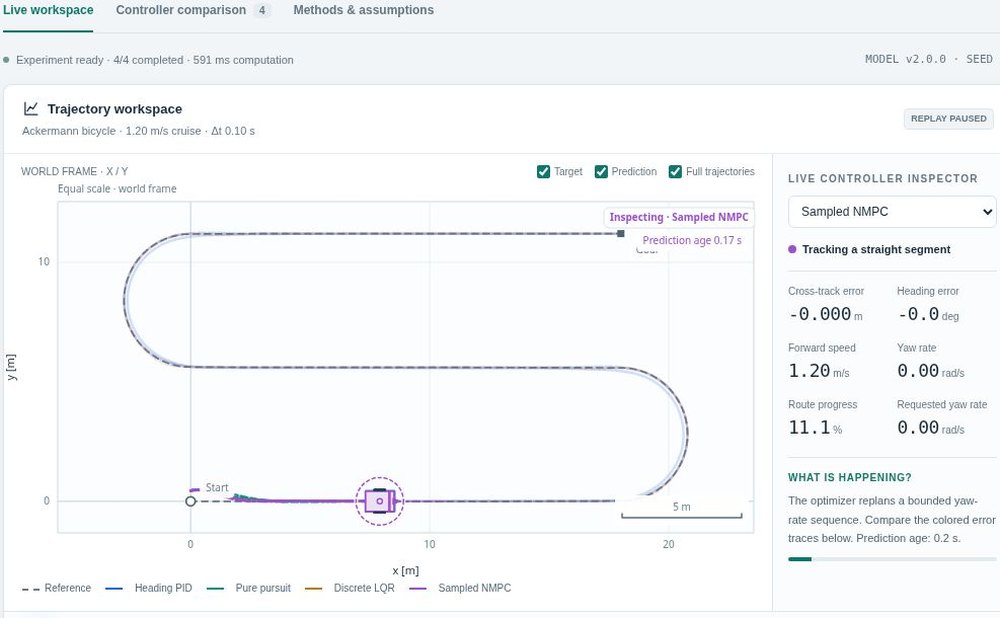
RobotDSS · Control Lab
Compare heading PID, pure pursuit, discrete LQR and sampled NMPC on the same configurable robot and reference route.
 Sensing & automation
Demo screenshot
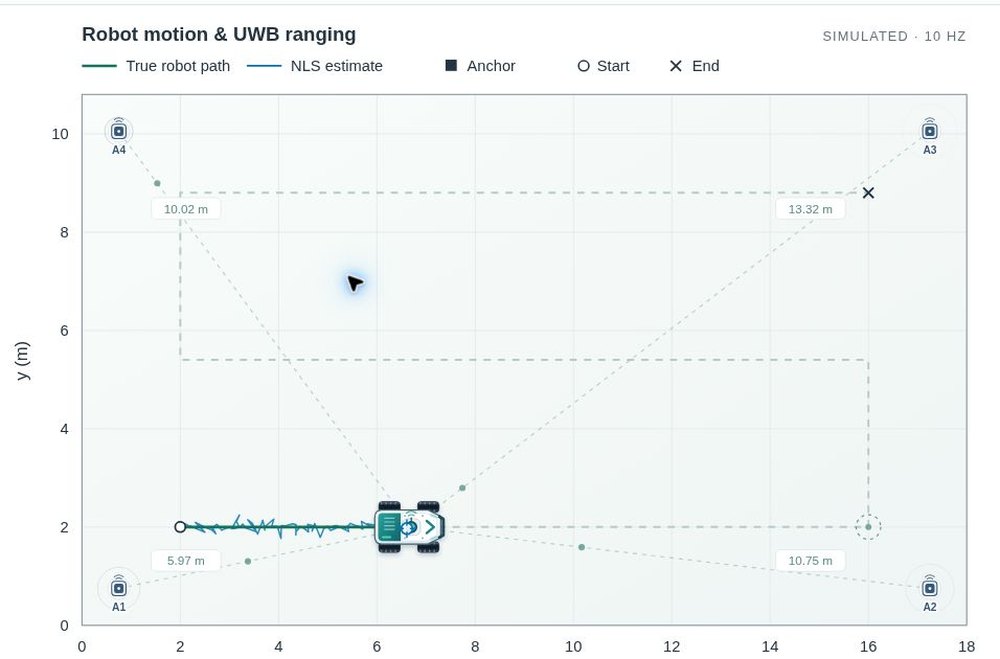
UWB Robot Localization
Follow a moving robot while noisy UWB ranges produce a position estimate and measurable localization error.
 Decision tools
Demo screenshot
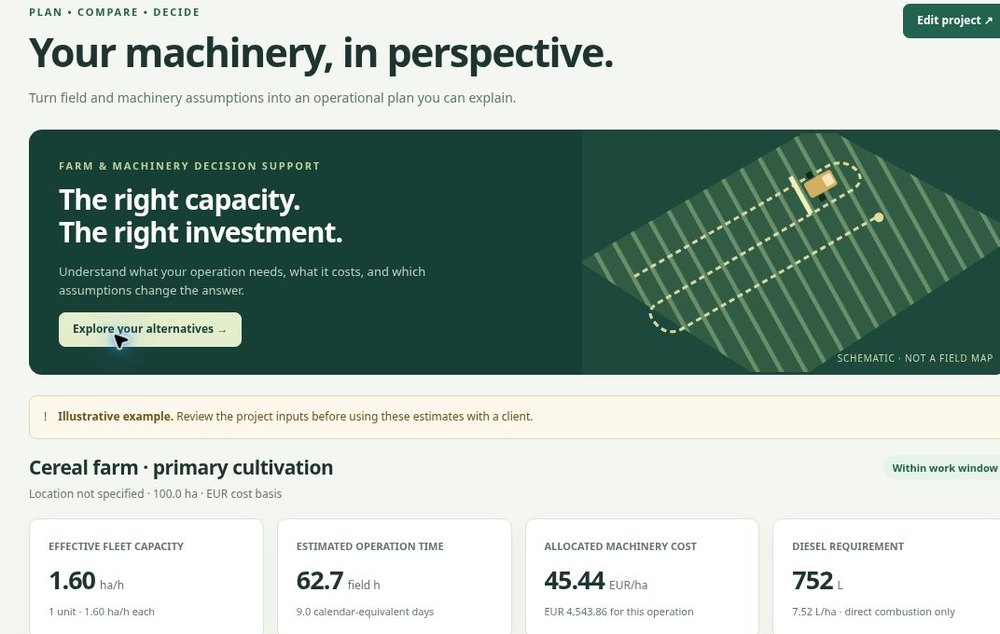
AgMachinery
Compare machinery capacity, power, costs, and work windows. Use 15 practical calculators, compare scenarios, and assemble a consultation report with visible assumptions.
 Harvest & manipulation
Demo screenshot
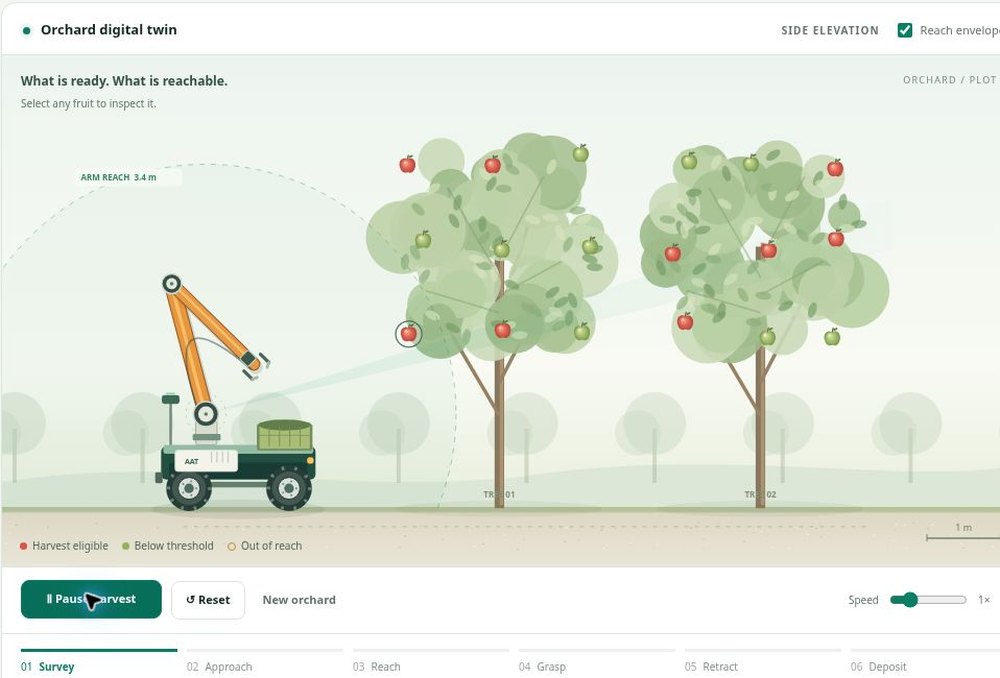
Orchard Harvest Lab
Explore how ripeness, arm reach and mobile-base position shape a selective harvest.
 Navigation & control
Demo screenshot
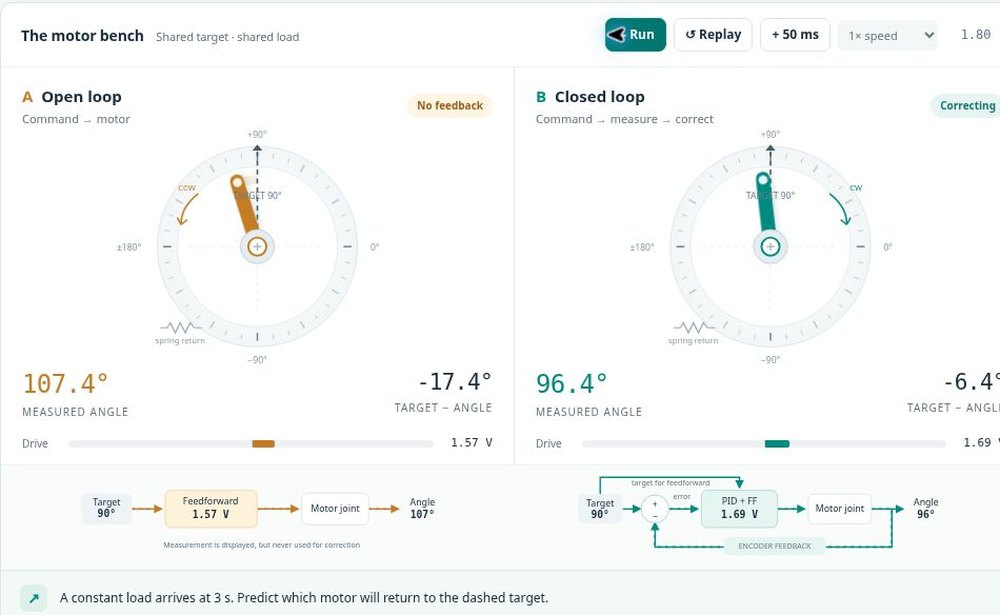
Motor Control Lab
Compare open-loop and PID motor-joint responses, then change loads and gains to see why feedback matters.